Related Experiment Video
Updated: Aug 29, 2025


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
An Automatic Foot and Shank IMU Synchronization Algorithm: Proof-of-concept

Abstract:
When using wearable sensors for measurement and analysis of human performance, it is often necessary to integrate and synchronise data from separate sensor systems. This paper describes a synchronization technique between IMUs attached to the shanks and insoles attached at the feet and aims to solve the need to compute the ankle joint angle, which relies on synchronized sensor data. This will additionally enable concurrent analysis using gait kinematic and kinetic features. A proof-of-concept of the algorithm, which relies on cross-correlation of gyroscope sensor data from the shank and foot, to align the sensor systems is demonstrated. The algorithm output is validated against those signals synchronized using manually annotated heel-strike and toe-off ground-truth signal landmarks, identified in both the shank and feet signals using previously published definitions. Results demonstrate that the developed algorithm is capable of synchronizing both sensor systems, based on IMU data from both healthy participants and participants suffering from knee osteoarthritis, with a mean lag time bias of 25.56ms when compared to the ground truth. A proof-of-concept of technique to synchronise IMUs attached to the shanks and insoles attached at the feet is demonstrated and offers an alternative approach to sensor system synchronisation.
More Related Videos
 08:27
Three-Dimensional Finger Motion Tracking during Needling: A Solution for the Kinematic Analysis of Acupuncture Manipulation
Published on: October 28, 2021
 10:02
FIM Imaging and FIMtrack: Two New Tools Allowing High-throughput and Cost Effective Locomotion Analysis
Published on: December 24, 2014
Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
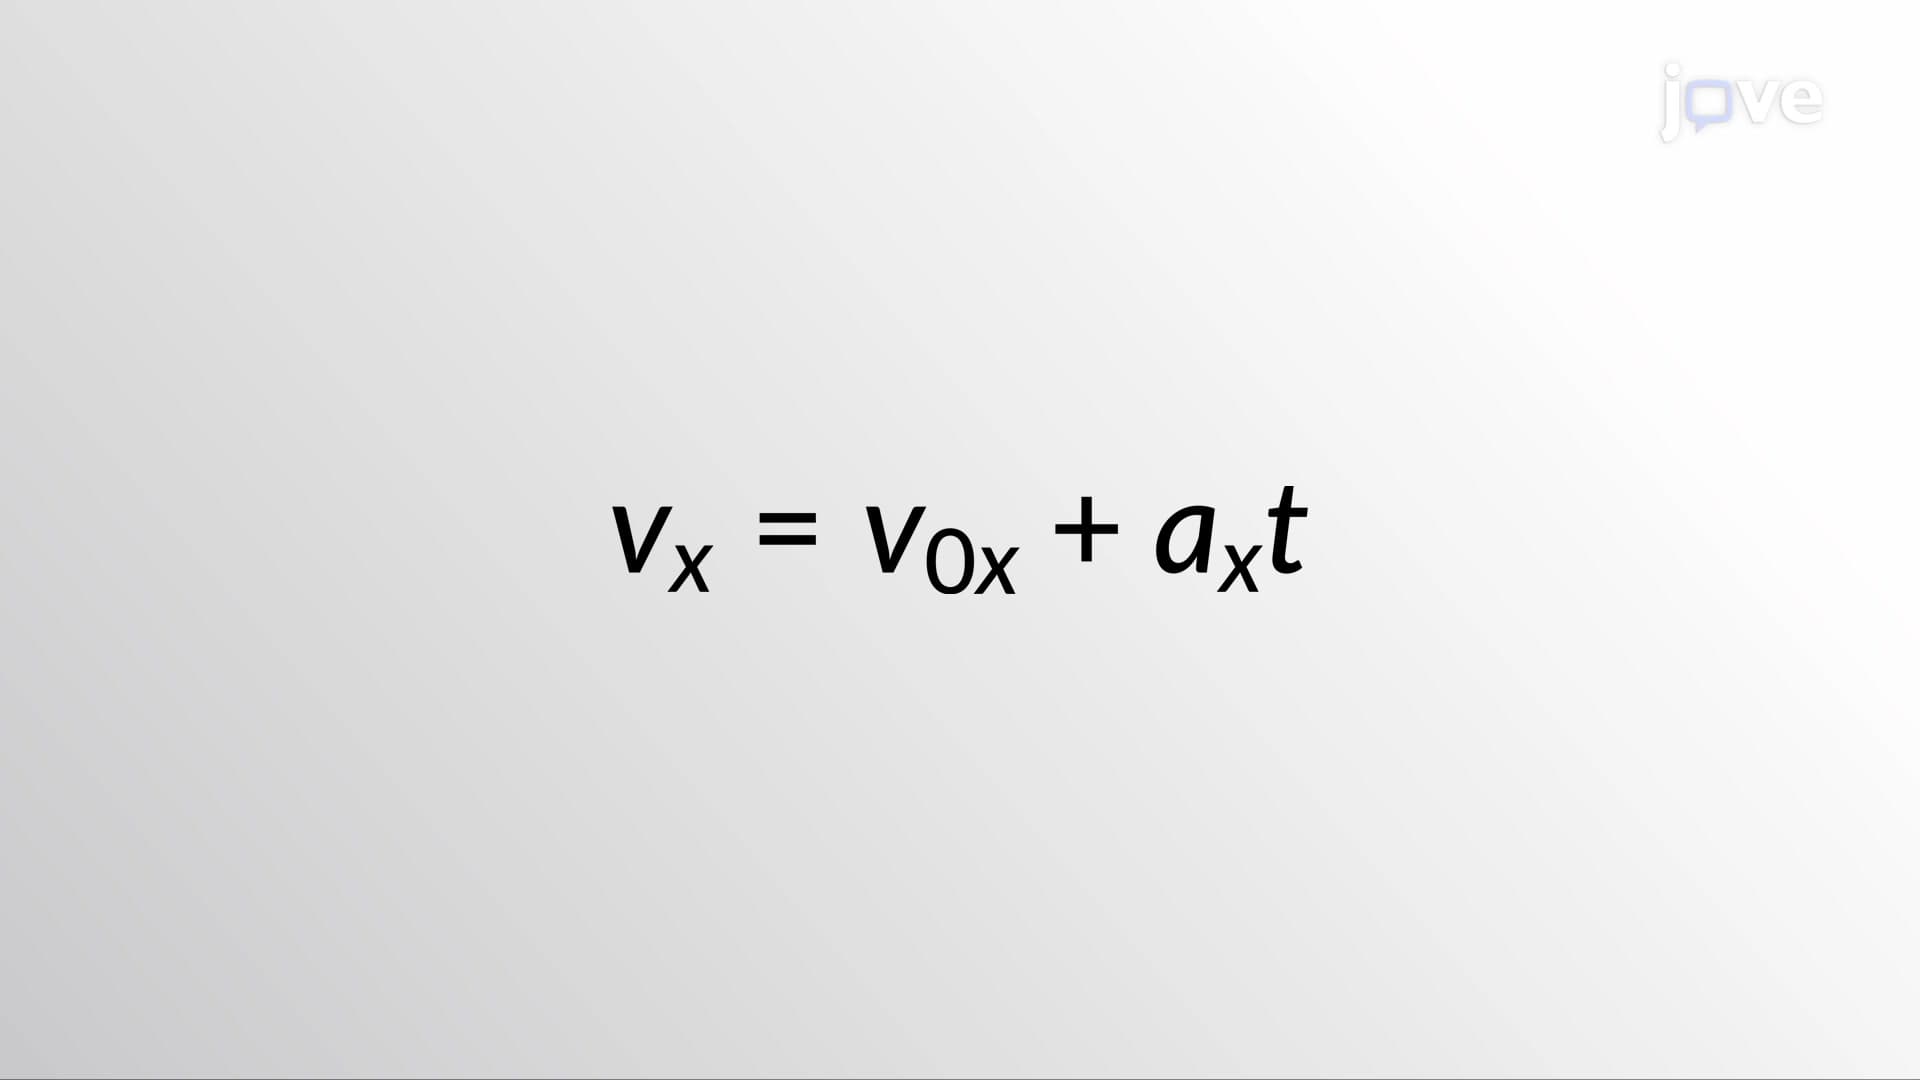 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Kinematic Equations: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...