Related Experiment Video
Updated: Aug 29, 2025
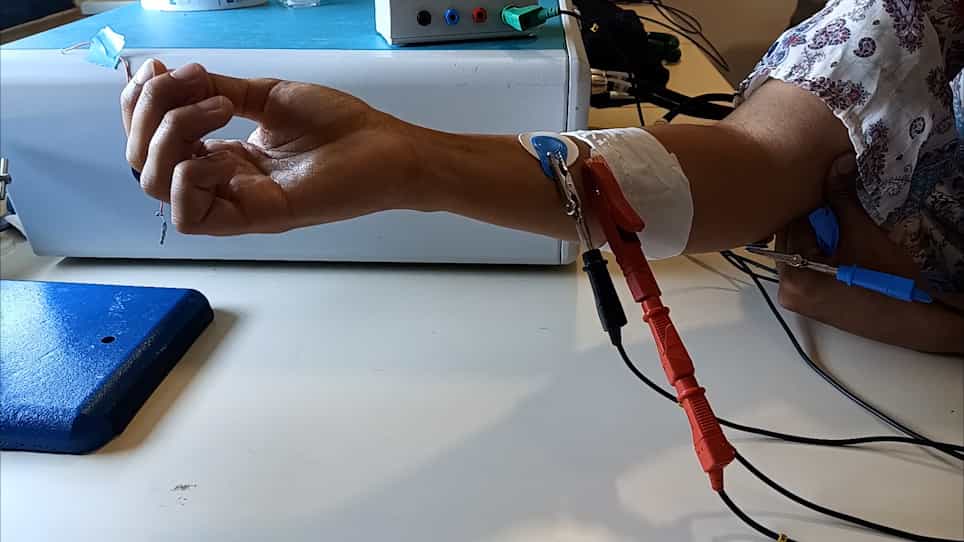

Conformable Wearable Electrodes: From Fabrication to Electrophysiological Assessment
Published on: July 22, 2022
Tele-Impedance Control Approach Using Wearable Sensors

Abstract:
Tele-operational tasks often suffer from instability issues and limited reliability during unpredictable interactions. We propose a real-time control law reproducing the impedance and kinematic behaviour of a subject's arm (shoulder and elbow) on a remote avatar in a 2-DoF task. The human arm impedance and kinematics are estimated respectively from EMG and M-IMU data and then mapped into the avatar arm through an impedance control. Contrary to literature methods, our portable tele-impedance controller relies only on wearable sensors and enables an easy use in unstructured environments. The good performance (R2> 0.7) of the muscle model used to map on the robot the human stiffness of five healthy subjects indicates the possibility of applying the proposed algorithm for a tele-impedance control.