Related Experiment Video
Updated: Aug 29, 2025
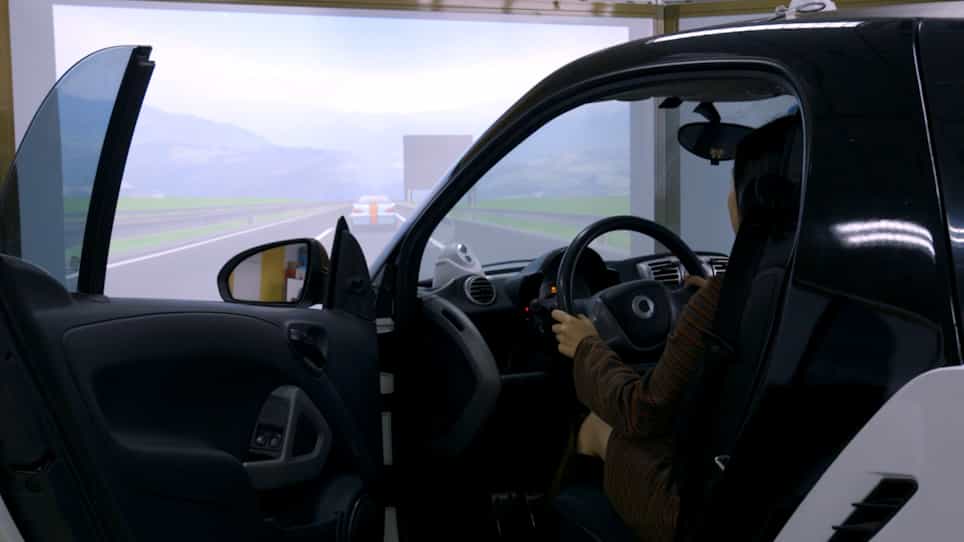
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Distributed cognition for collaboration between human drivers and self-driving cars
Alice Plebe1, Gastone Pietro Rosati Papini1, Antonello Cherubini1
1Department of Industrial Engineering, University of Trento, Trento, Italy.

Abstract:
This paper focuses on the collaboration between human drivers and intelligent vehicles. We propose a collaboration mechanism grounded on the concept of distributed cognition. With distributed cognition, intelligence does not lie just in the single entity but also in the interaction with the other cognitive components in a system. We apply this idea to vehicle intelligence, proposing a system distributed into two cognitive entities-the human and the autonomous agent-that together contribute to drive the vehicle. This account of vehicle intelligence differs from the mainstream research effort on highly autonomous cars. The proposed mechanism follows one of the paradigm derived from distributed cognition, the rider-horse metaphor: just like the rider communicates their intention to the horse through the reins, the human influences the agent using the pedals and the steering wheel. We use a driving simulator to demonstrate the collaboration in action, showing how the human can communicate and interact with the agent in various ways with safe outcomes.

Related Concept Videos
 01:19
High-Level and Low-Level Awareness
 01:20
Introduction to Cognitive Psychology
This field emerged in the mid-20th century, following a period dominated by behaviorism, which...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:42
Schemas
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:05
Collisions in Multiple Dimensions: Introduction