Related Experiment Video
Updated: Aug 28, 2025


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Adiabatic Invariant of Center-of-Mass Motion during Walking as a Dynamical Stability Constraint on Stride Interval
Fabien Buisseret1,2,3, Victor Dehouck4,5, Nicolas Boulanger4
1CeREF-Technique, Chaussée de Binche 159, 7000 Mons, Belgium.

Abstract:
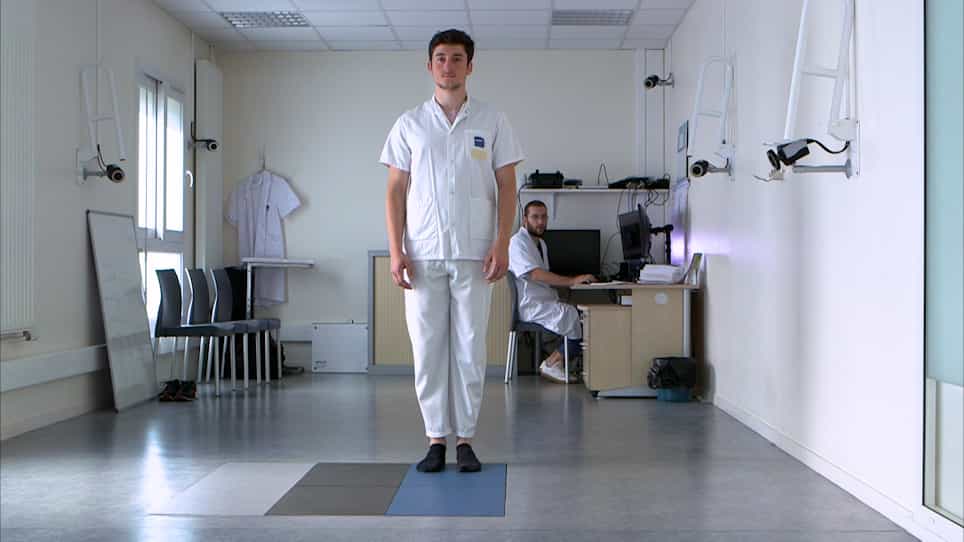
Human walking exhibits properties of global stability, and local dynamic variability, predictability, and complexity. Global stability is typically assessed by quantifying the whole-body center-of-mass motion while local dynamic variability, predictability, and complexity are assessed using the stride interval. Recent arguments from general mechanics suggest that the global stability of gait can be assessed with adiabatic invariants, i.e., quantities that remain approximately constant, even under slow external changes. Twenty-five young healthy participants walked for 10 min at a comfortable pace, with and without a metronome indicating preferred step frequency. Stride interval variability was assessed by computing the coefficient of variation, predictability using the Hurst exponent, and complexity via the fractal dimension and sample entropy. Global stability of gait was assessed using the adiabatic invariant computed from averaged kinetic energy value related to whole-body center-of-mass vertical displacement. We show that the metronome alters the stride interval variability and predictability, from autocorrelated dynamics to almost random dynamics. However, despite these large local variability and predictability changes, the adiabatic invariant is preserved in both conditions, showing the global stability of gait. Thus, the adiabatic invariant theory reveals dynamical global stability constraints that are "hidden" behind apparent local walking variability and predictability.
More Related Videos

Related Concept Videos
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:14
Equation of Motion: Center of Mass
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...