Related Experiment Video
Updated: Aug 27, 2025

Tactile Semiautomatic Passive-Finger Angle Stimulator TSPAS
Published on: July 30, 2020
An improved tangent search algorithm
Probhat Pachung1, Jagdish Chand Bansal1
1South Asian University, New Delhi, India.

Abstract:
The Tangent Search Algorithm (TSA) is a newly developed population-based meta-heuristic algorithm to solve complex optimization problems. It is based on the tangent function, which steers the given solution towards more promising regions of the search space. Though TSA has performed well for many optimization problems, the experimental analyses show that it suffers from the low exploration ability and slow convergence rate. This article proposes an improved TSA algorithm (iTSA). Using two concepts, 'Fitness Weighted Search Strategy' (FWSS) and 'Opposition Based learning' (OBL), iTSA is better in terms of exploration while maintaining the high convergence rate of TSA.•Fitness weighted search strategy (FWSS) is used to increase the exploration ability of TSA.•Opposition based learning (OBL) is used to increase the convergence speed of TSA.•Together, OBL and FWSS into iTSA outperformed the classical TSA and other considered state-of-the-art algorithms. The performance of the proposed iTSA is validated on two sets of test functions: CEC14 benchmark functions and a set of 21 well-known classical benchmark functions. The obtained results are compared with those obtained from the basic TSA and other considered state-of-the-art algorithms.
Related Concept Videos
 01:12
Adjusting a Traverse
 01:17
Beams with Unsymmetric Loadings
The first moment-area theorem determines the slope at any point on the beam. This theorem indicates that the change in slope between two points on a beam...
 01:25
Design Example: Traverse Angle Computations
 01:19
Introduction to Horizontal Curves
 01:10
Equations of Motion: Normal and Tangetial Components
Newton's second law of motion is employed to articulate the...
 01:27
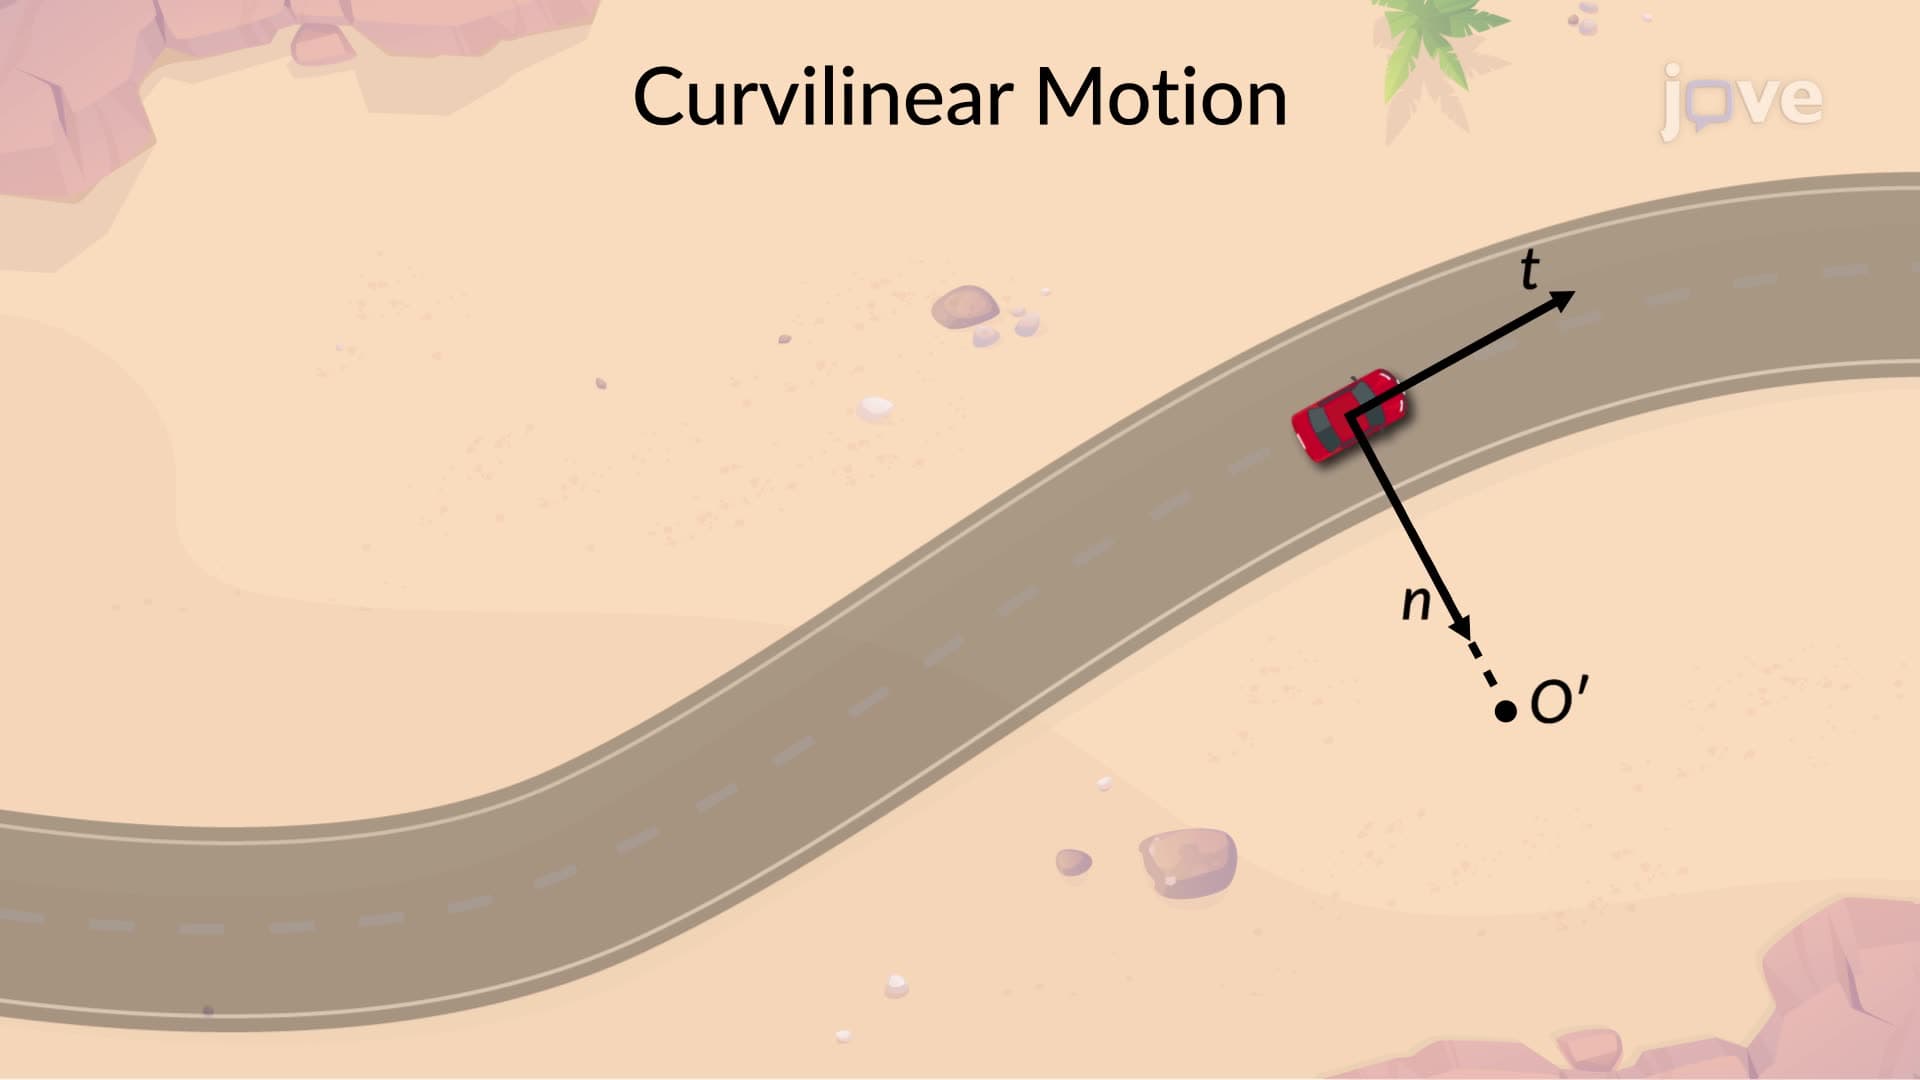
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...