Related Experiment Video
Updated: Aug 27, 2025
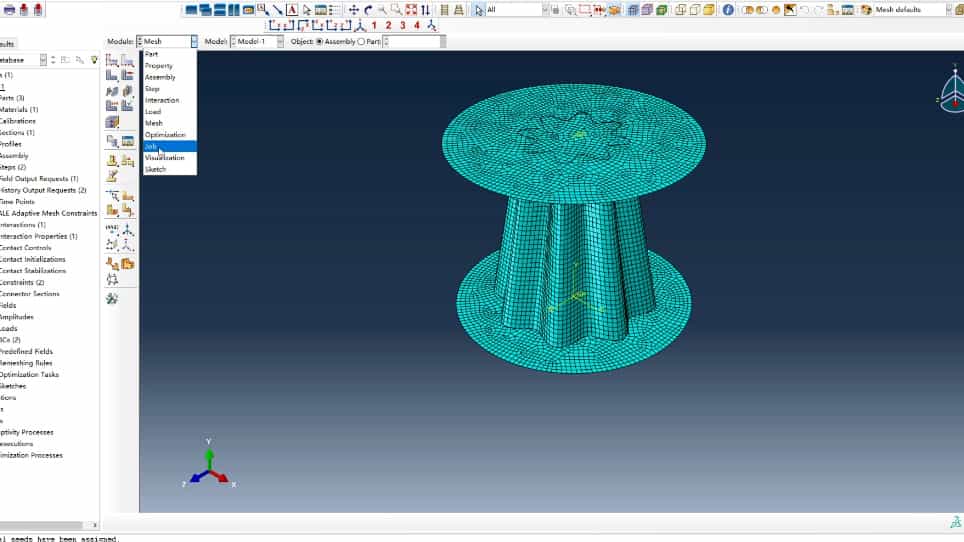
Finite Element Modeling for the Simulation of the Quasi-Static Compression of Corrugated Tapered Tubes
Published on: January 6, 2023
Effective cloth folding trajectories in simulation with only two parameters
Victor-Louis De Gusseme1, Francis Wyffels1
1IDLab-AIRO, Department of Electronics and Information Systems, Ghent University - imec, Ghent, Belgium.

Abstract:
Robotic cloth folding remains challenging for robots due to its highly deformable nature. In order to deal with these deformations, several strategies with varying amounts of adaptability have been proposed. We study robotic cloth folding by simulating and evaluating a trajectory search space with only two parameters: one parameter for the trajectory's height and one parameter to tilt it. We extensively analyzed folding a long-sleeved shirt in a high-fidelity simulator. To demonstrate that the trajectory is sufficiently adaptable and robust, we test several cloth shapes, cloth materials, an entire folding sequence and different folding velocities. We can deal with every folding scenario by tuning the two parameters correctly. The trajectories' simplicity and their robustness in simulation make them ideal candidates for future transfer to real-world robotic setups.
Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:20
Two-Dimensional Force System
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
 01:09
Bending of Material: Problem Solving
 01:25
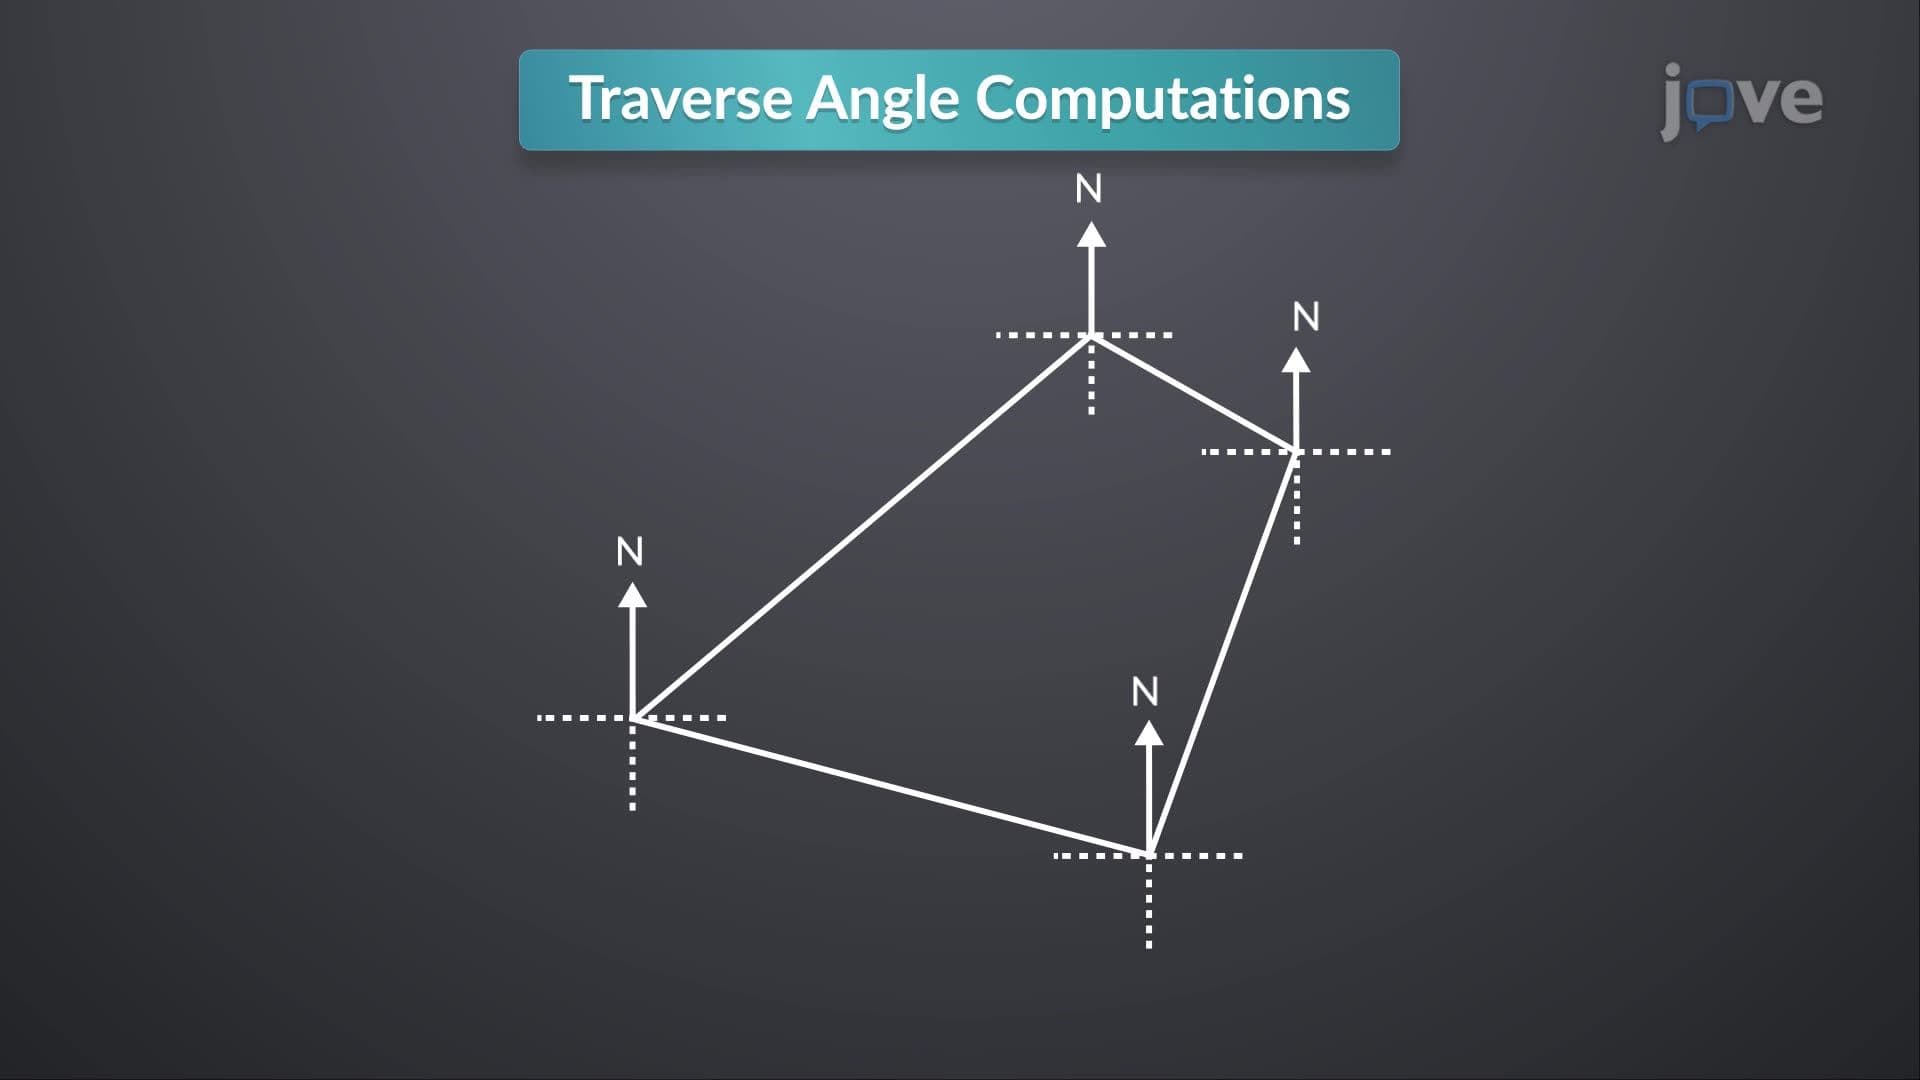
Design Example: Traverse Angle Computations
 01:11
Relative Velocity in Two Dimensions