Related Experiment Video
Updated: Aug 27, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Modelling and dynamic analysis of slippage level for large-scale skid-steered unmanned ground vehicle
Kang Zhou1, Shuaishuai Lei2, Xiongzi Du2
1School of Mechatronical Engineering, Beijing Institute of Technology, Beijing, China. zhoukang326@126.com.

Abstract:
To analyze the turning characteristics of a large-scale skid-steered unmanned ground vehicle (UGV), a mathematical model based on geometric characteristics and kinematics was developed in this work. The turning characteristics, as well as some important geometric and moving features, were seriously considered in the model. A self-designed UGV was employed to conduct targeted experiments. Initial experiment showed that the width of UGV was much larger than that of actual value, because slippage phenomenon made the errors of actual velocity and trajectory length between two sides of the UGV were lower than those obtained from direct wheel velocities measurements and calculations. Further experiments which obtained moving velocity of the UAV by means of a highly accurate Inertial Navigation System (INS) were conducted. Combining this velocity, the slippage levels of the four wheels can be quantitatively measured. In addition, using standard velocities derived from the accurate moving velocity, a true turning radius can be accurately calculated in real time when the slippage characteristics were seriously considered, hence, the mathematical model can be sufficiently validated. The work can realize modelling and dynamic analysis and estimation of the slippage characteristics of this type of UGV.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
 01:14
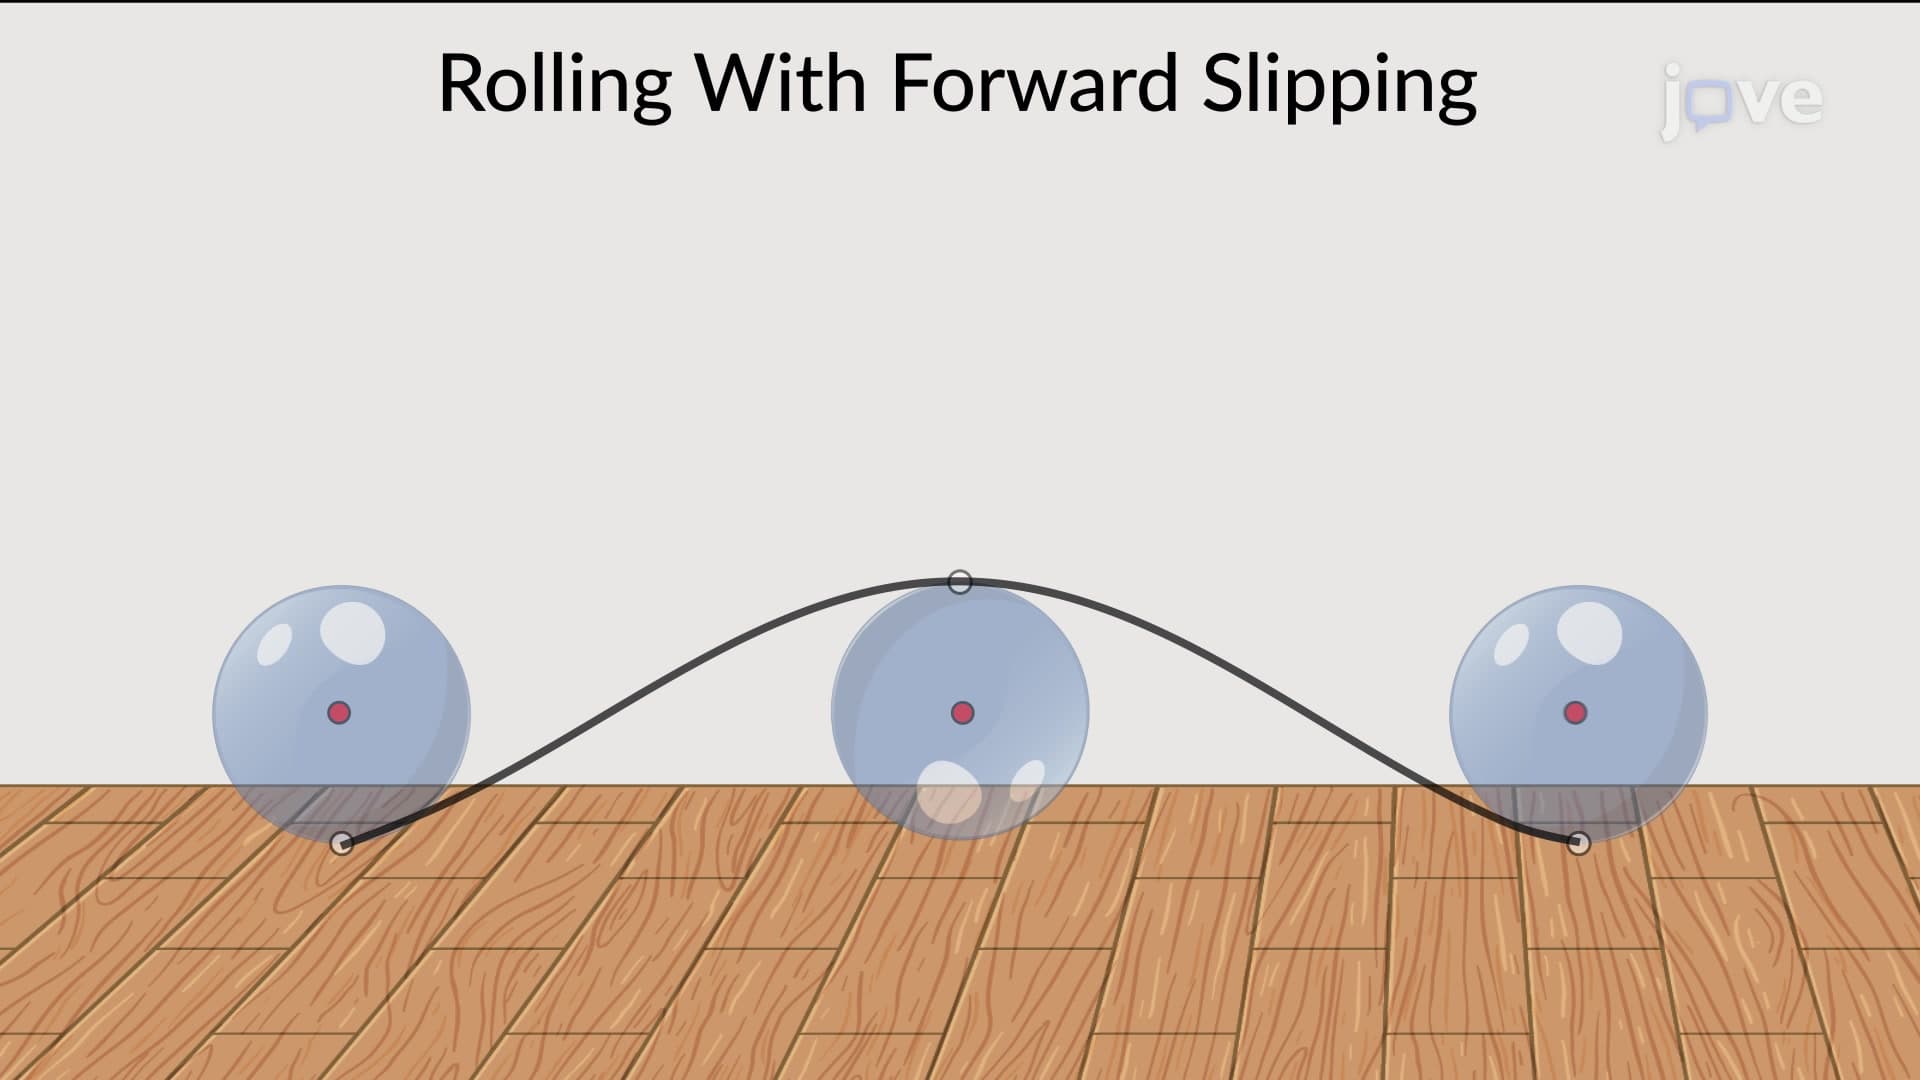
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:09
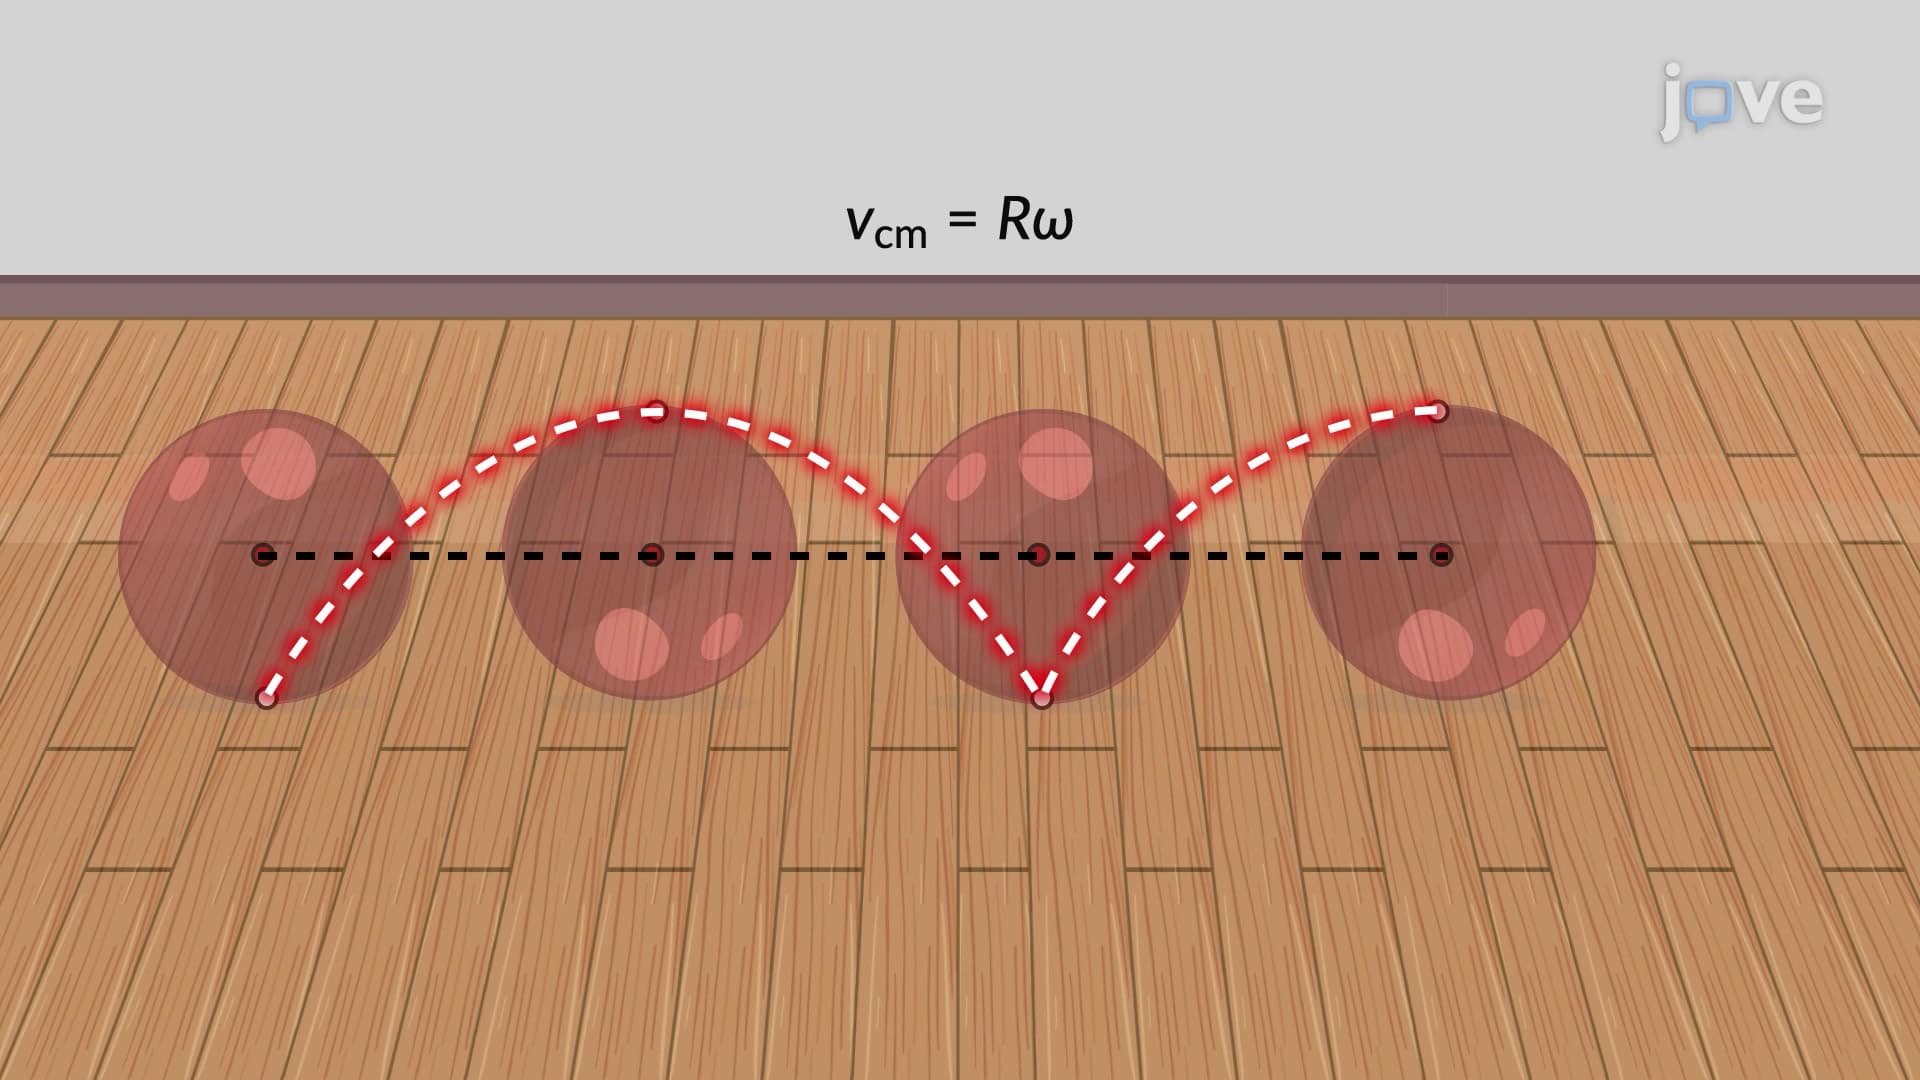
Rolling Without Slipping
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:19
Root-Locus Method
This system can be represented by a block...