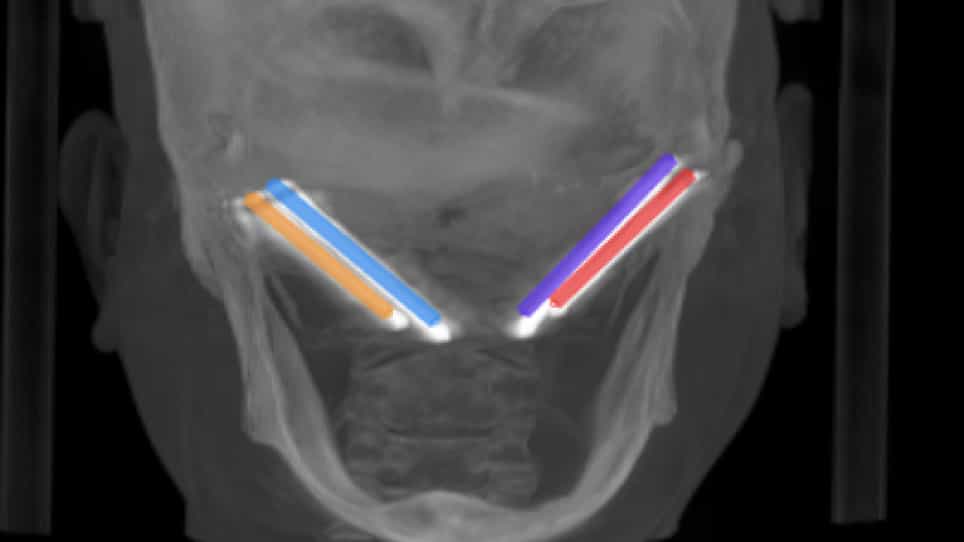
Related Experiment Video
Updated: Aug 27, 2025

Orthopedic Robot-Assisted Femoral Neck System in the Treatment of Femoral Neck Fracture
Published on: March 3, 2023
Feasibility of a Robot-Assisted Surgical Navigation System for Mandibular Distraction Osteogenesis in Hemifacial
Byeong Seop Kim1, Ziwei Zhang1, Mengzhe Sun1
1Department of Plastic and Reconstructive Surgery, Shanghai Ninth People's Hospital, Shanghai Jiao Tong University School of Medicine, Shanghai, China.

Abstract:
This study aimed to investigate the feasibility and accuracy of osteotomy and distractor placement using a robotic navigation system in a model surgical experiment of mandibular distraction osteogenesis for hemifacial microsomia. Imaging data from 5 patients with Pruzansky-Kaban type II (IIa: 4; IIb: 1) mandibular deformities were used to print 3D models for simulated mandibular distraction osteogenesis. In the experimental group, a robot-assisted surgical navigation system was used to perform the surgery under robotic guidance following registration, according to the preoperative design. Conventional surgery was performed in the control group, in which the operation was based on intraoperative estimations of the preoperative design by experienced surgeons. The accuracies of the osteotomy and distractor placement were assessed based on distance and angular error. Osteotomy accuracy was higher in the experimental group than in the control group, and the distance error ( t =9.311, P <0.001) and angular error ( t =5.385, P =0.001) were significantly reduced. The accuracy of distractor placement was also significantly higher in the experimental group, while the distance error ( t =3.048, P =0.016) and angular error ( t =3.524, P =0.024) were significantly reduced. The present results highlight the feasibility of robot-assisted distraction osteogenesis combined with electromagnetic navigation for improved surgical precision in clinical settings.