Related Experiment Video
Updated: Aug 27, 2025

Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
A novel design of a passive variable stiffness soft robotic gripper
Yu Shan1,2, Yanzhi Zhao1, Changlei Pei1
1Key Laboratory of Parallel Robot and Mechatronic System, Yanshan University, Qinhuangdao, Hebei Province, People's Republic of China.

Abstract:
Inspired by the twisting and hanging phenomenon of vines, this paper proposes and designs a passive variable stiffness soft robotic gripper to grasp an object in a simple and robust manner using the principle of jamming. This method has the characteristics of high reliability and good stability, which can achieve soft grasping and rigid load-bearing of the object. Firstly, according to two key issues, the design model of the gripper is proposed, the principle of the proposed gripper is analyzed, and the relationship between the stiffness of the gripper and the stiffness of the object is revealed. Secondly, the model of the robotic gripper is created using a conventional motor drive method, and the grasping process and deformation causes of the gripper are analyzed by using the principle of instability effect and large deformation principle. Finally, the experimental prototype is developed and the feasibility of the design principle and the grasping deformation process of the gripper are verified by gripping experiments.


Related Concept Videos
 01:05
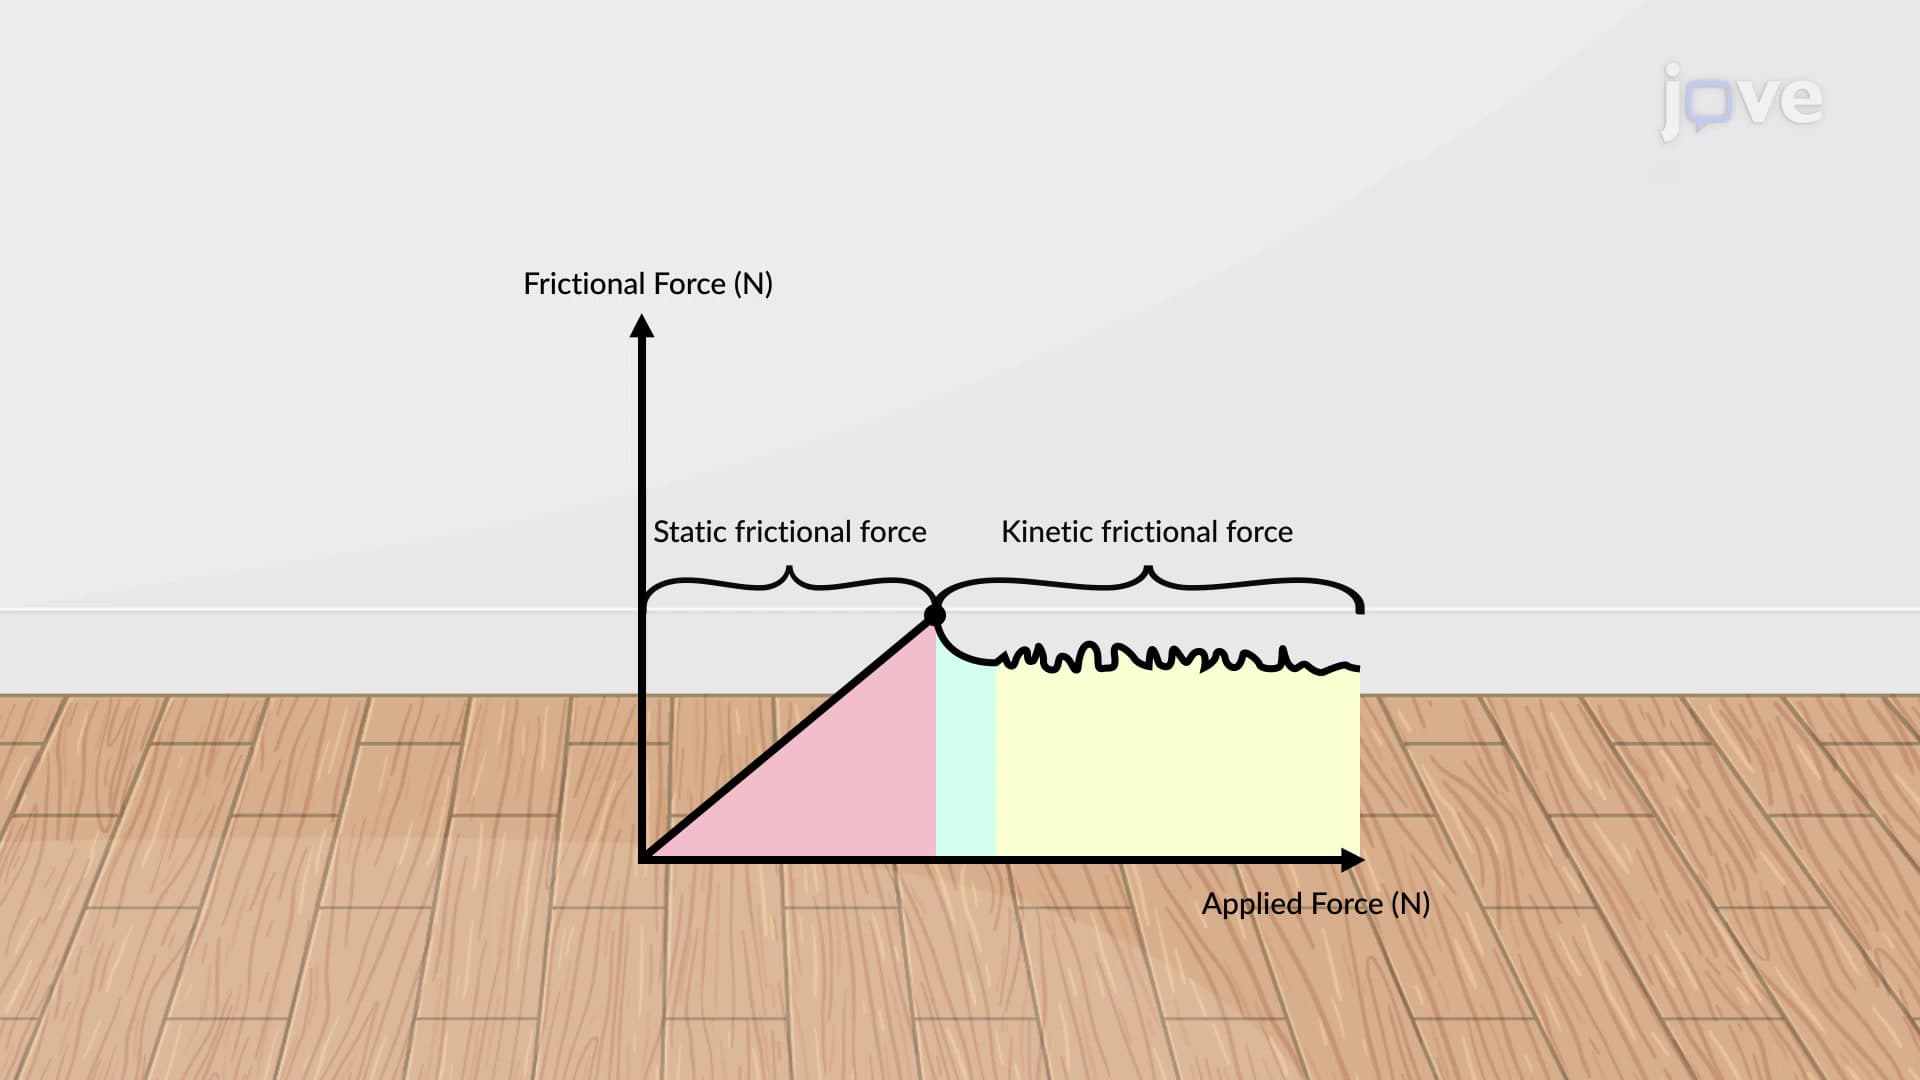
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:22
Mechanical Systems
 01:11
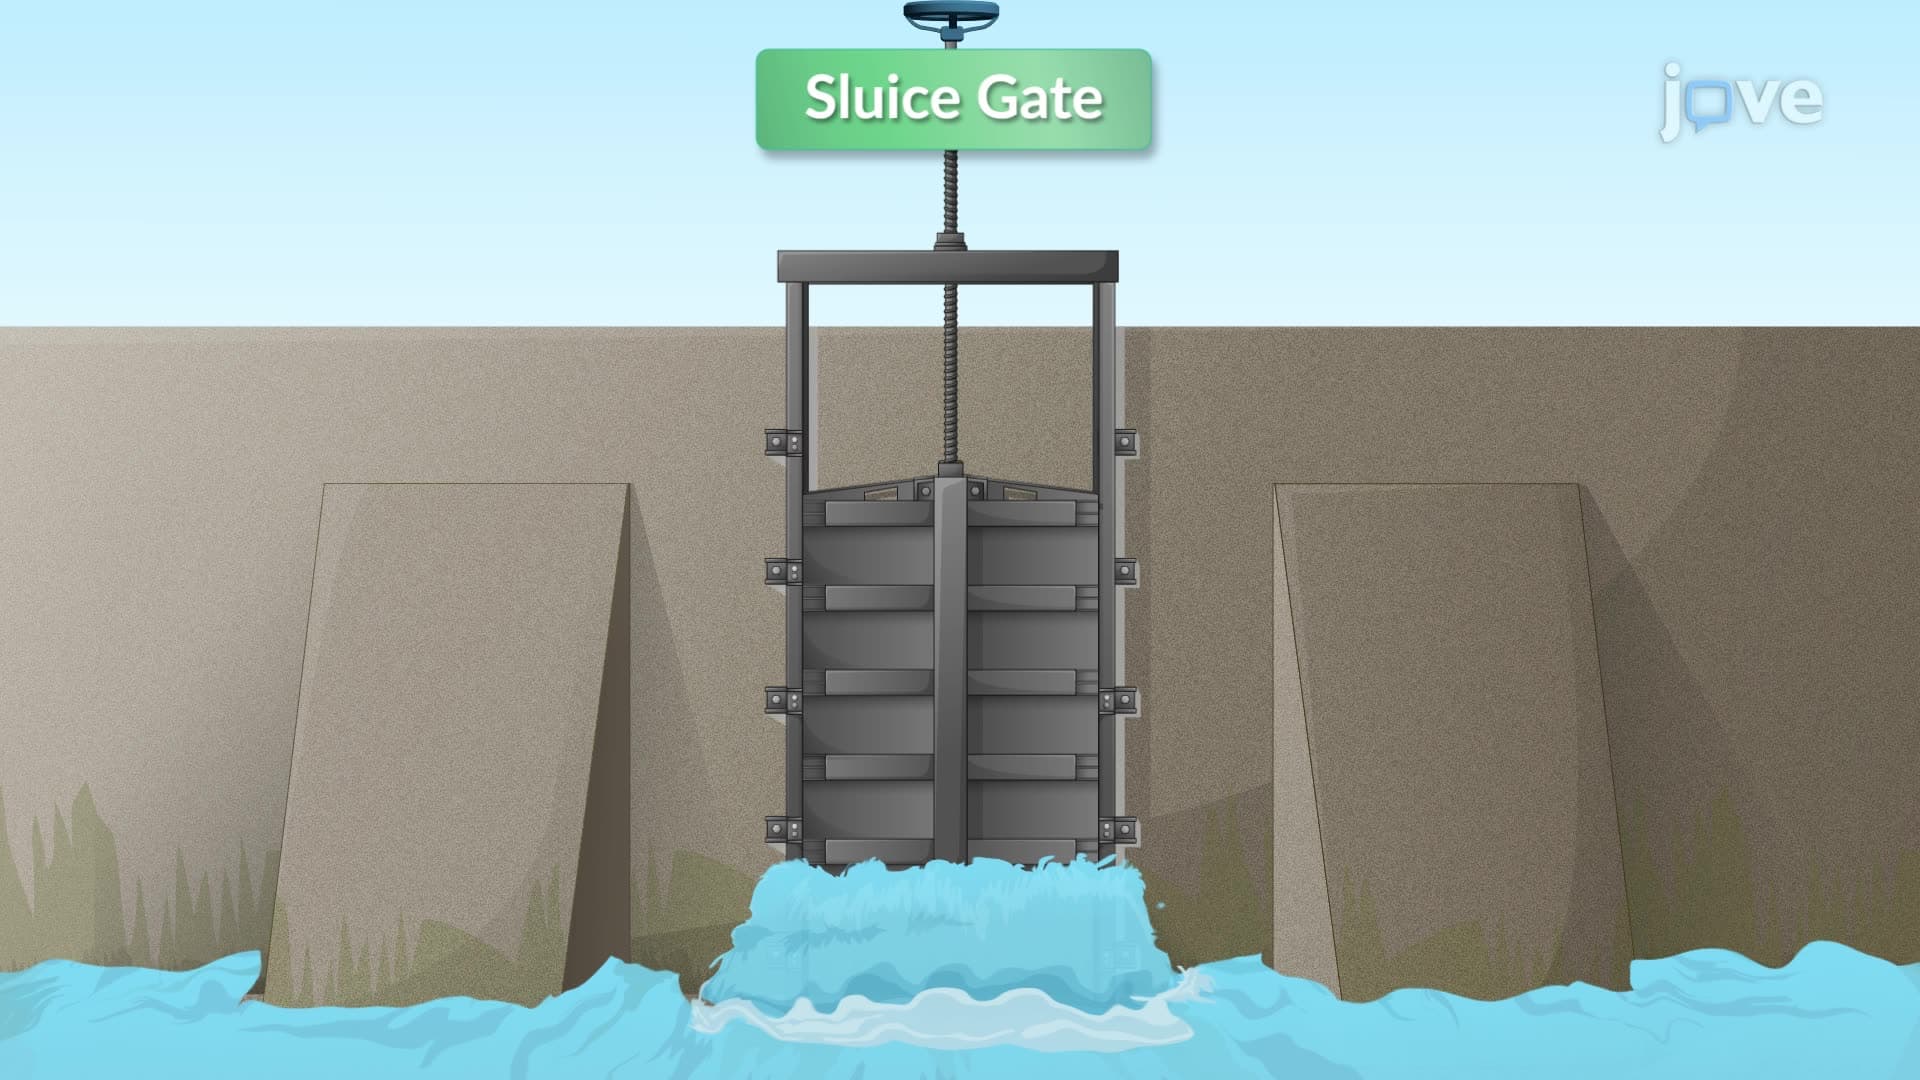
Design Example: Forces in Sluice Gate
Key variables in...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Machines: Problem Solving II