Related Experiment Video
Updated: Aug 27, 2025


Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Analysis of change of direction performance with dominant and non-dominant leg using linear and nonlinear approaches
Javad Sarvestan1,2,3,4, Elham Shirzad4, Ahmed Reza Arshi5
1Department of Natural Sciences in Kinanthropology, Faculty of Physical Culture, Palacky University Olomouc, Olomouc, Czech Republic.

Abstract:
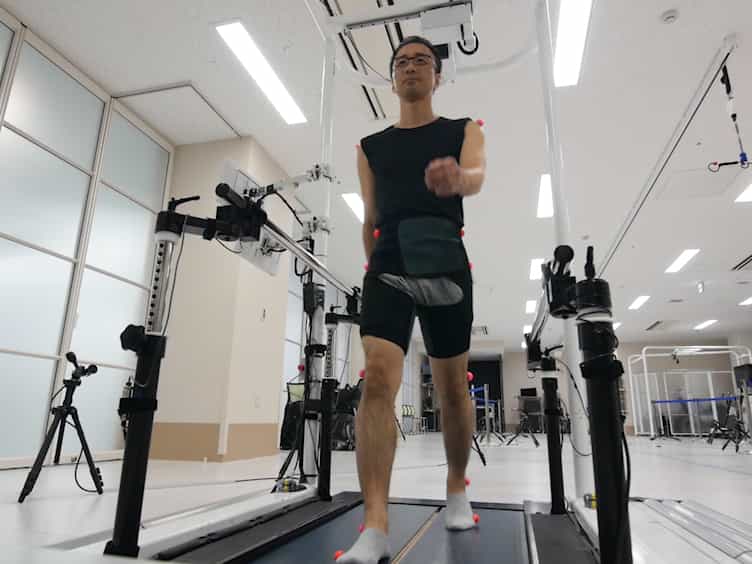
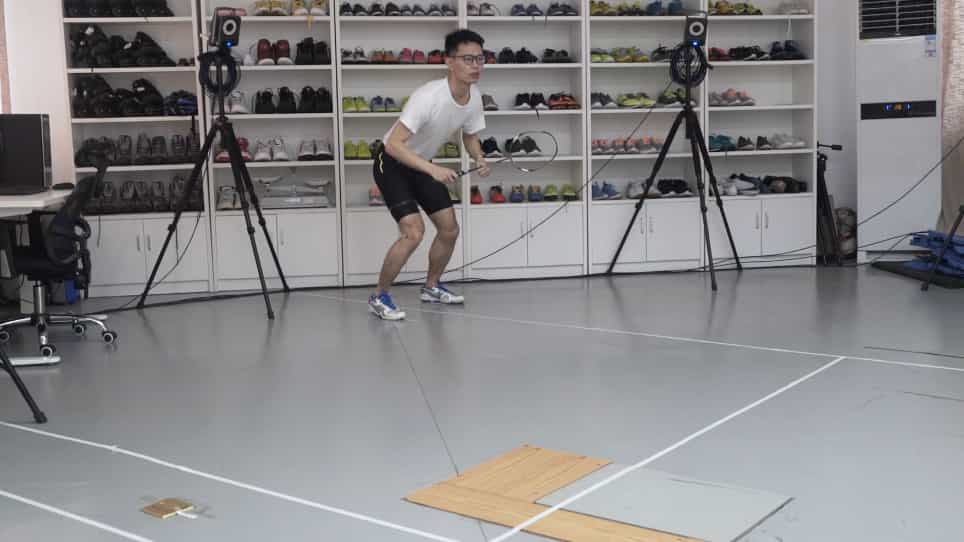
This study was aimed to analyse the lower limb kinematics during the change of direction (COD) performance with the dominant (DL) and non-dominant (NDL) leg using linear (traditional kinematics) and nonlinear (Self Organising Map-based cluster analysis) approaches. Three 5-0-5 COD performances with the DL and three with the NDL were performed by 23 (aged 21.6 ± 2.3 years) collegiate athletes. No significant difference was observed between the COD duration, and approach speed of DL and NDL. Significantly greater ankle abductions, knee and hip external rotations were identified in COD with DL, compared to NDL (p < .001, d > 0.8). Self Organising Maps portrayed a completely different coordination pattern profile during change of direction performance with the DL and NDL. The cluster analysis illustrated similar inter-individual coordination patterning when participants turned with their DL or NDL. No visible relationship was observed in the cluster analysis of the lower limb joint angles and angular velocities. Outcomes of this study portrayed that coordination patterning (combination of joint angles and the rate of change of angles) could portray the movement patterning differences in different tasks, while a sole investigation on the joint angles or angular velocities may not reveal the underlying mechanisms of movement patterning.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:10
Relative Motion Analysis - Acceleration