Related Experiment Video
Updated: Aug 27, 2025


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Towards Unsupervised Rehabilitation: Development of a Portable Compliant Device for Sensorimotor Hand Rehabilitation

Abstract:
Sensorimotor impairments of the hand after stroke can drastically reduce the ability to perform activities of daily living. Recently, there has been an increased interest in minimally supervised and unsupervised rehabilitation to increase therapy dosage and to complement conventional therapy. Several devices have been developed that are simple to use and portable. Yet, they do not incorporate diversified somatosensory feedback, which has been suggested to promote sensorimotor recovery. Here we present the prototype of a portable one-degree-of-freedom hand trainer based on a novel compliant shell mechanism. Our solution is safe, intuitive, and can be used for various hand sizes. Importantly, it also provides rich sensory feedback through haptic rendering. We complement our device with a rehabilitation game, where we leverage interactive tangible game elements with diverse haptic characteristics to provide somatosensory training and foster recovery.
More Related Videos
 07:34
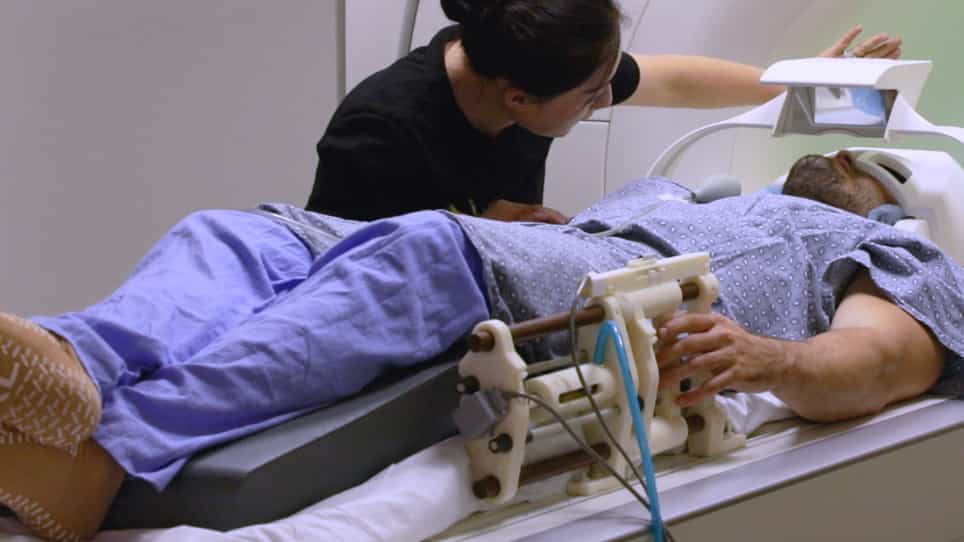
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023