Related Experiment Video
Updated: Aug 26, 2025

The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
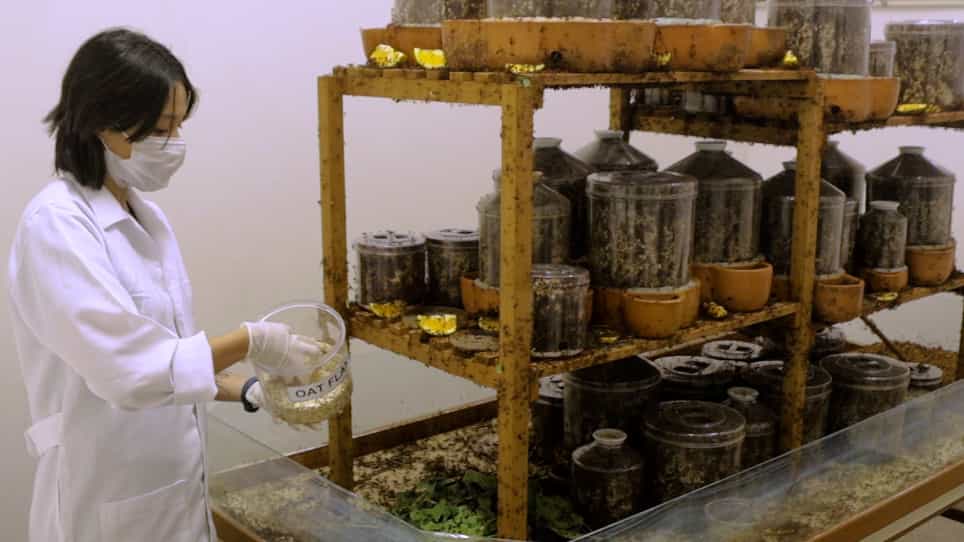
Dynamics of cooperative excavation in ant and robot collectives
S Ganga Prasath1, Souvik Mandal2,3, Fabio Giardina1
1School of Engineering and Applied Sciences, Harvard University, Cambridge, United States.

Abstract:
The solution of complex problems by the collective action of simple agents in both biologically evolved and synthetically engineered systems involves cooperative action. Understanding the resulting emergent solutions requires integrating across the organismal behavior of many individuals. Here, we investigate an ecologically relevant collective task in black carpenter ants Camponotus pennsylvanicus: excavation of a soft, erodible confining corral. These ants show a transition from individual exploratory excavation at random locations to spatially localized collective exploitative excavation and escape from the corral. Agent-based simulations and a minimal continuum theory that coarse-grains over individual actions and considers their integrated influence on the environment leads to the emergence of an effective phase space of behaviors, characterized in terms of excavation strength and cooperation intensity. To test the theory over the range of both observed and predicted behaviors, we use custom-built robots (RAnts) that respond to stimuli to characterize the phase space of emergence (and failure) of cooperative excavation. Tuning the amount of cooperation between RAnts, allows us to vary the efficiency of excavation and synthetically generate the entire range of macroscopic phases predicted by our theory. Overall, our approach shows how the cooperative completion of tasks can arise from simple rules that involve the interaction of agents with a dynamically changing environment that serves as both an enabler and a modulator of behavior.
Related Concept Videos
 04:49
Robbers Cave
 01:15
Quarrying of Stone
One common method involves using a diamond belt saw to cut large blocks from the quarry face. These blocks can be about 50 feet long and 12 feet high. After the initial vertical cut, drilling is performed at the base of the...
 01:08
Brick Cutting Techniques
Cut bricks are categorized by size. Bricks cut to half their original length are called half-bats, while those cut to three-fourths their length are known as three-fourth bats.
Special types of...
 01:13
Principle of Virtual Work: Problem Solving
To apply the principle of virtual work,...
 01:15
Elastic Collisions: Case Study
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...