Related Experiment Video
Updated: Aug 25, 2025
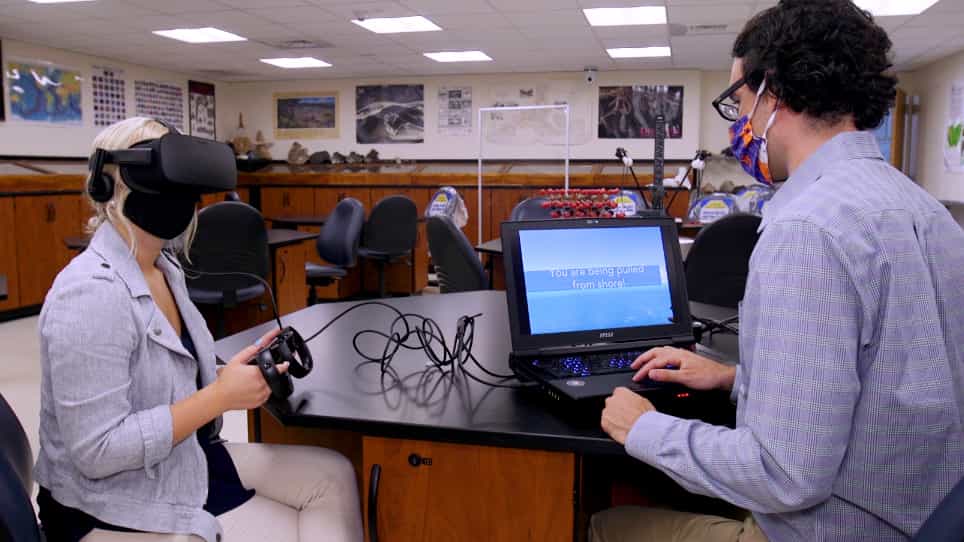

Developing a Virtual Reality Video Game to Simulate Rip Currents
Published on: July 16, 2020
Verification of the System for Ship Position Keeping Equipped with a Set of Anchors in Unity3d
Jakub Wnorowski1, Andrzej Łebkowski1
1Department of Ship Automation, Gdynia Maritime University, Poland Morska St. 83, 81-225 Gdynia, Poland.

Abstract:
Modern computers with specialised software are able to simulate oceans with waves and sea currents, and the action of wind, gravity, ships and other vehicles. The high-level programming languages that are used in this type of software can read information from navigation devices connected to the computer (e.g., via serial ports), and proceed to use the raw data in control algorithms. More and more desktop software and simulators can use data from additional electronic devices such as pressure sensors, temperature sensors, etc. Thus, it is possible to conduct real-time communication with a PLC (programmable logic controller) and use it in simulators. In this article, a user interface designed in Unity3d is presented. The user interface was able to read data from navigation devices, which were used in a ship positioning control algorithm. Verification of the algorithm occurred during research on a real ship, which used an anchor-based positioning system. Using data obtained on the real ship, a mathematical model of anchor winches was developed. Next, the mathematical model was implemented in the simulator developed in Unity3d. The simulator contained the same environmental conditions as during the research on the real ship. The mathematical model of anchor winches and implementation developed in the simulator will allow for future research on anchor-based positioning systems (e.g., in different environmental conditions). The research resulted in a shift of the ship's position by 26.3 m under 280 degrees. The difference in arrival time to the target point between the real ship and the virtual ship was 19%, and the difference in position deviation was 330%.
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:26
Errors in Global Positioning System
 01:03
Anchoring Junctions
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device