Related Experiment Video
Updated: Aug 25, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Trajectory Optimization in Terms of Energy and Performance of an Industrial Robot in the Manufacturing Industry
Carlos Garriz1,2, Rosario Domingo1
1Department of Construction and Manufacturing Engineering, Universidad Nacional de Educación a Distancia (UNED), 28040 Madrid, Spain.

Abstract:
Currently, the high demand for new products in the automotive sector requires large investments in factories. The automotive industry is characterized by high automatization, largely achieved by manipulator robots capable of multitasking. This work presents a method for the optimization of trajectories in robots with six degrees of freedom and a spherical wrist. The optimization of trajectories is based on the maximization of manipulability and the minimization of electrical energy. For this purpose, it is necessary to take into account the kinematics and dynamics of the manipulator in order to integrate an algorithm for calculation. The algorithm is based on the Kalman method. This algorithm was implemented in a simulation of the trajectories of a serial industrial robot, in which the robot has a sealer gun located on its sixth axis and the quality of the sealer application depends directly on the orientation of the gun. During the optimization of the trajectory, the application of the sealer must be guaranteed. This method was also applied to three different trajectories in the automotive sector. The obtained results for manipulability and electrical energy consumption prove the efficiency of the algorithm. Therefore, this method searches for the optimal solution within the limits of the manipulator and maintains the orientation of the final effector. This can be used for a known trajectory.


Related Concept Videos
 01:14
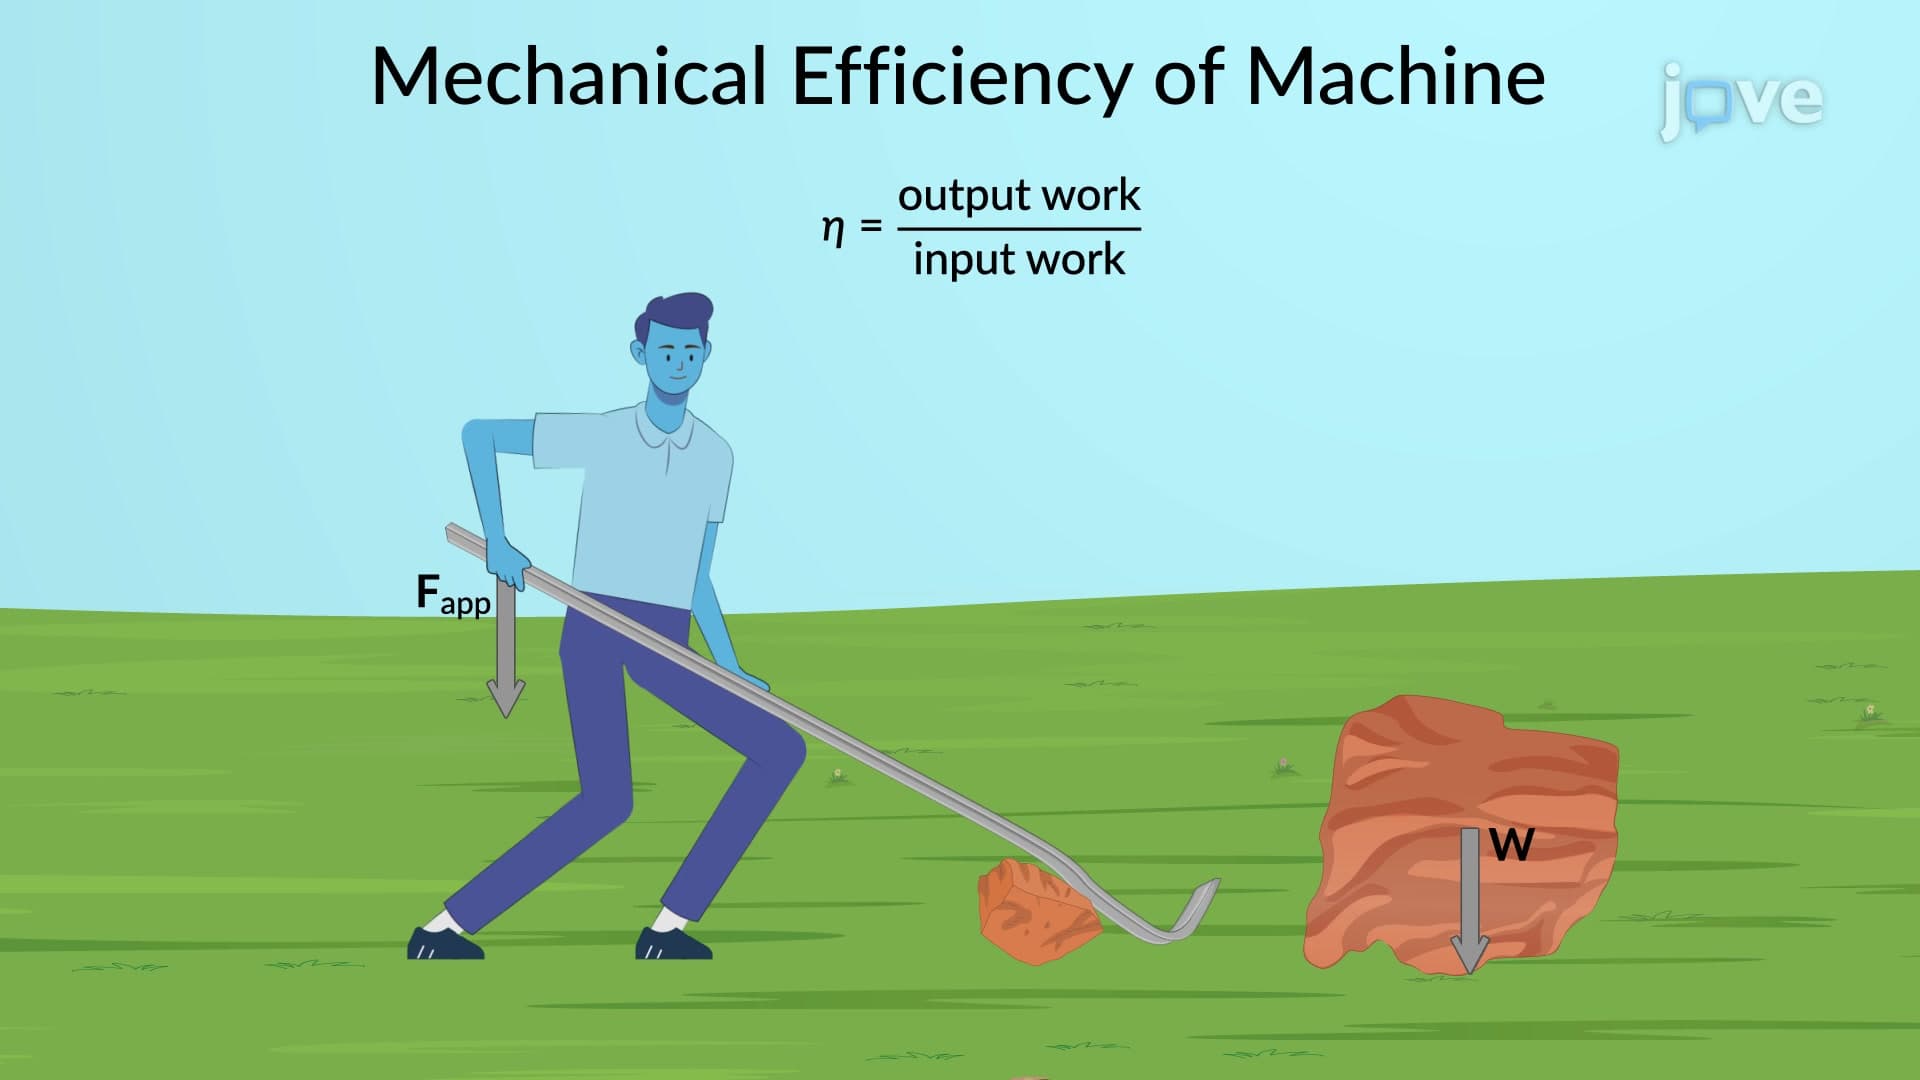
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:10
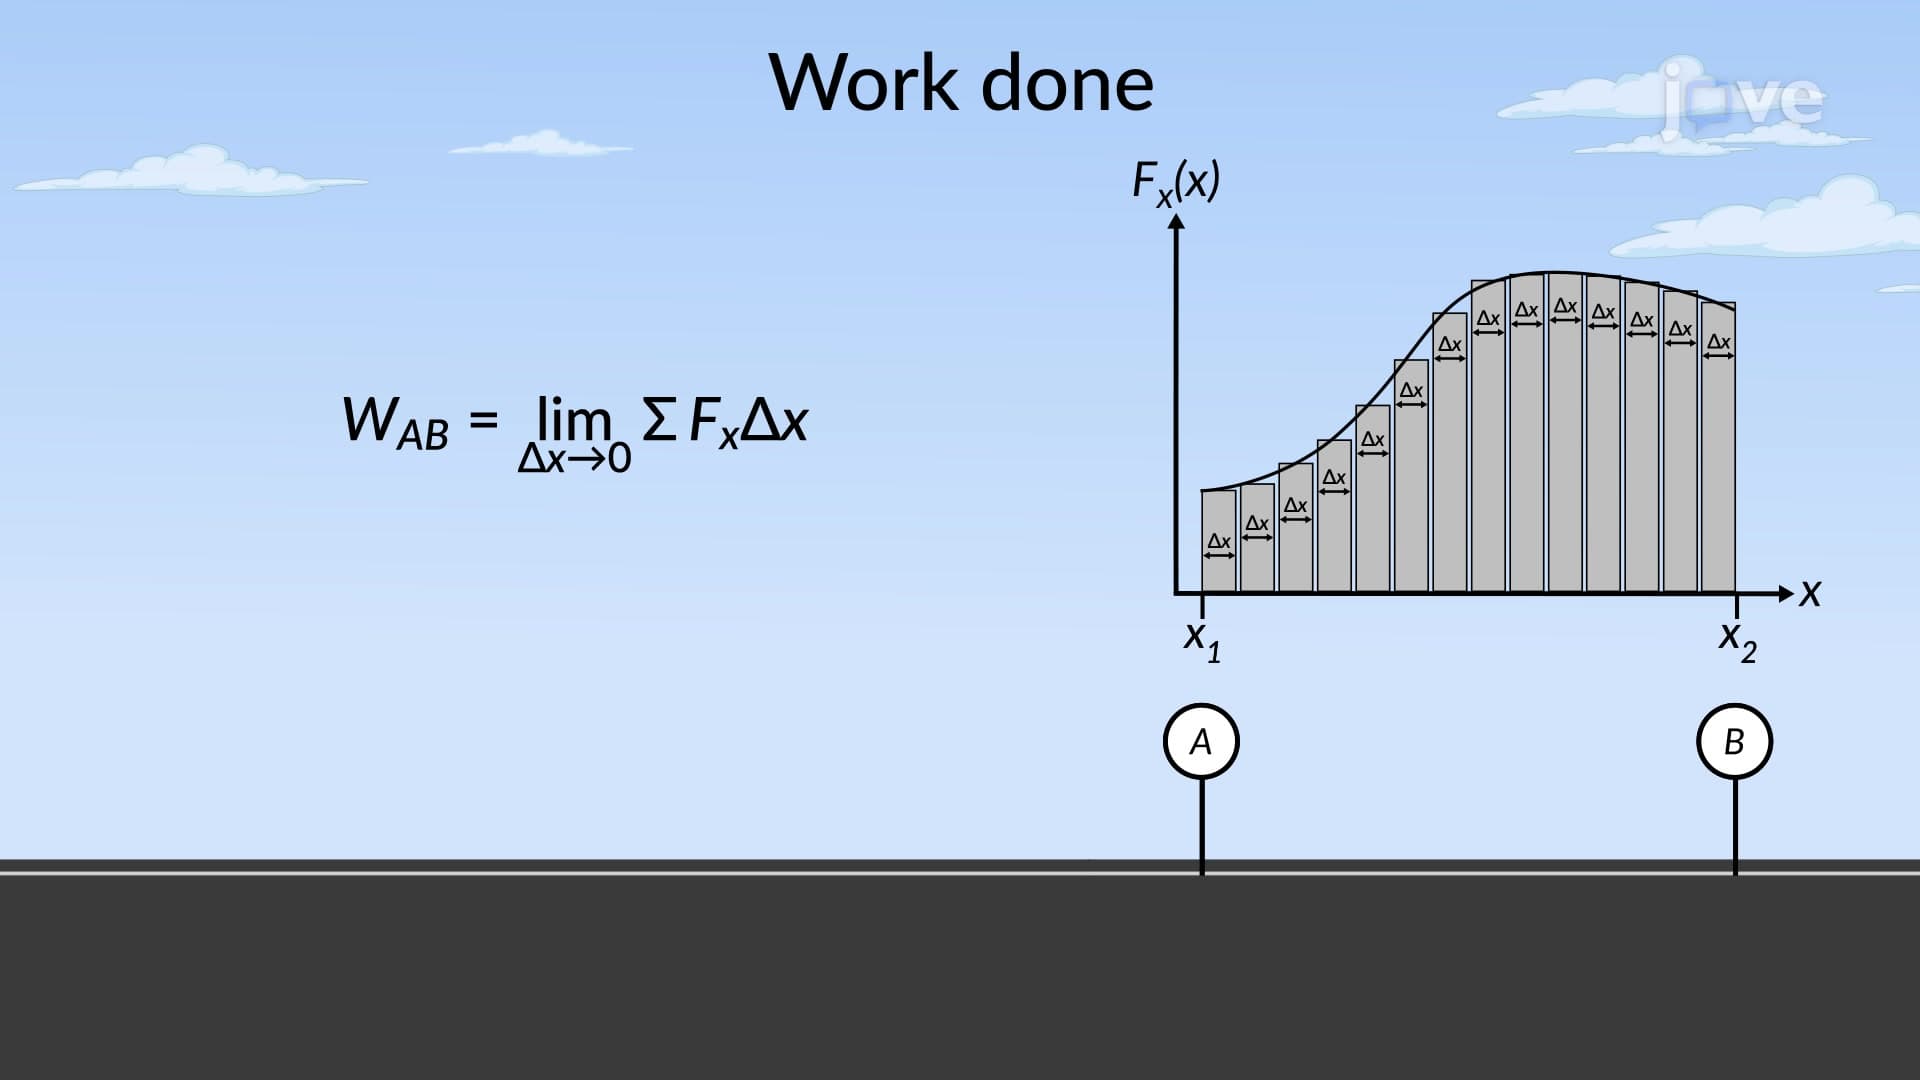
Work and Energy for Variable Forces
 01:10
Control Systems
At the heart...
 01:22
Mechanical Systems
 01:15
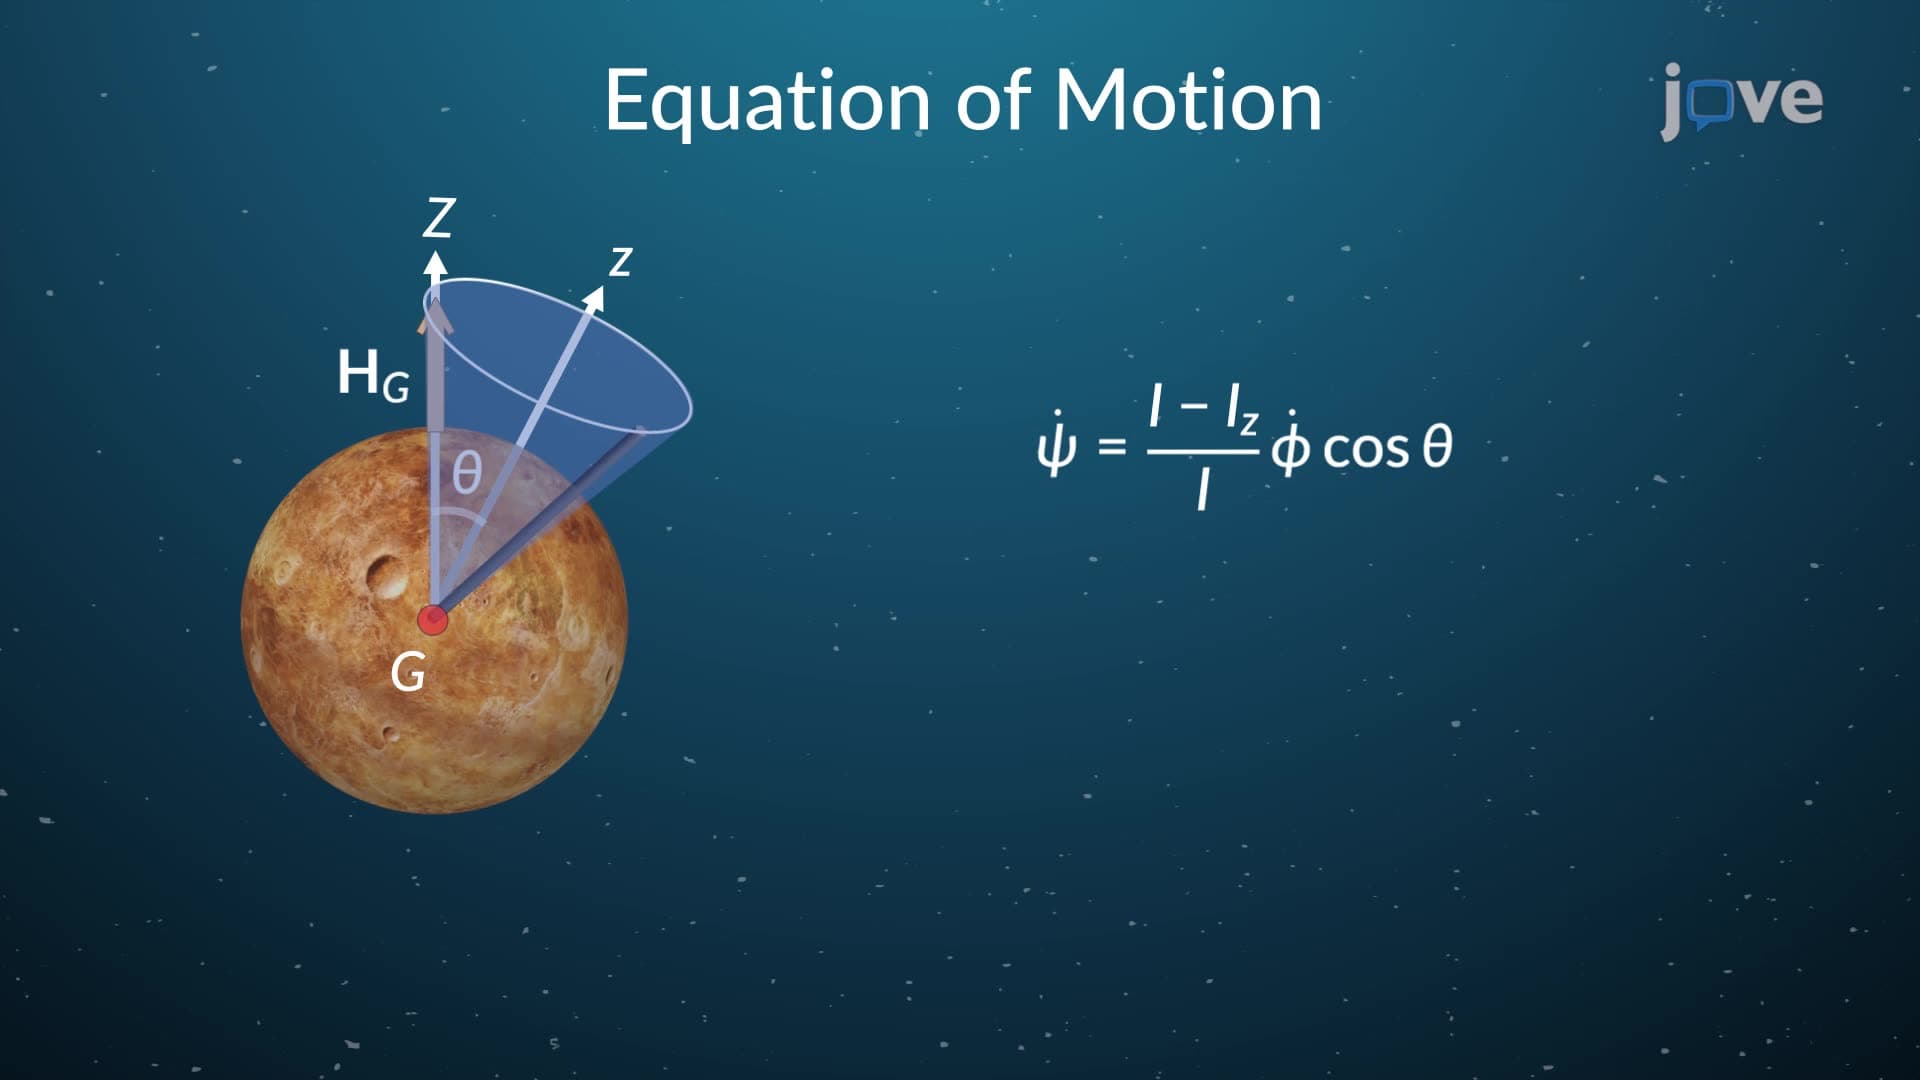
Torque Free Motion
 01:27
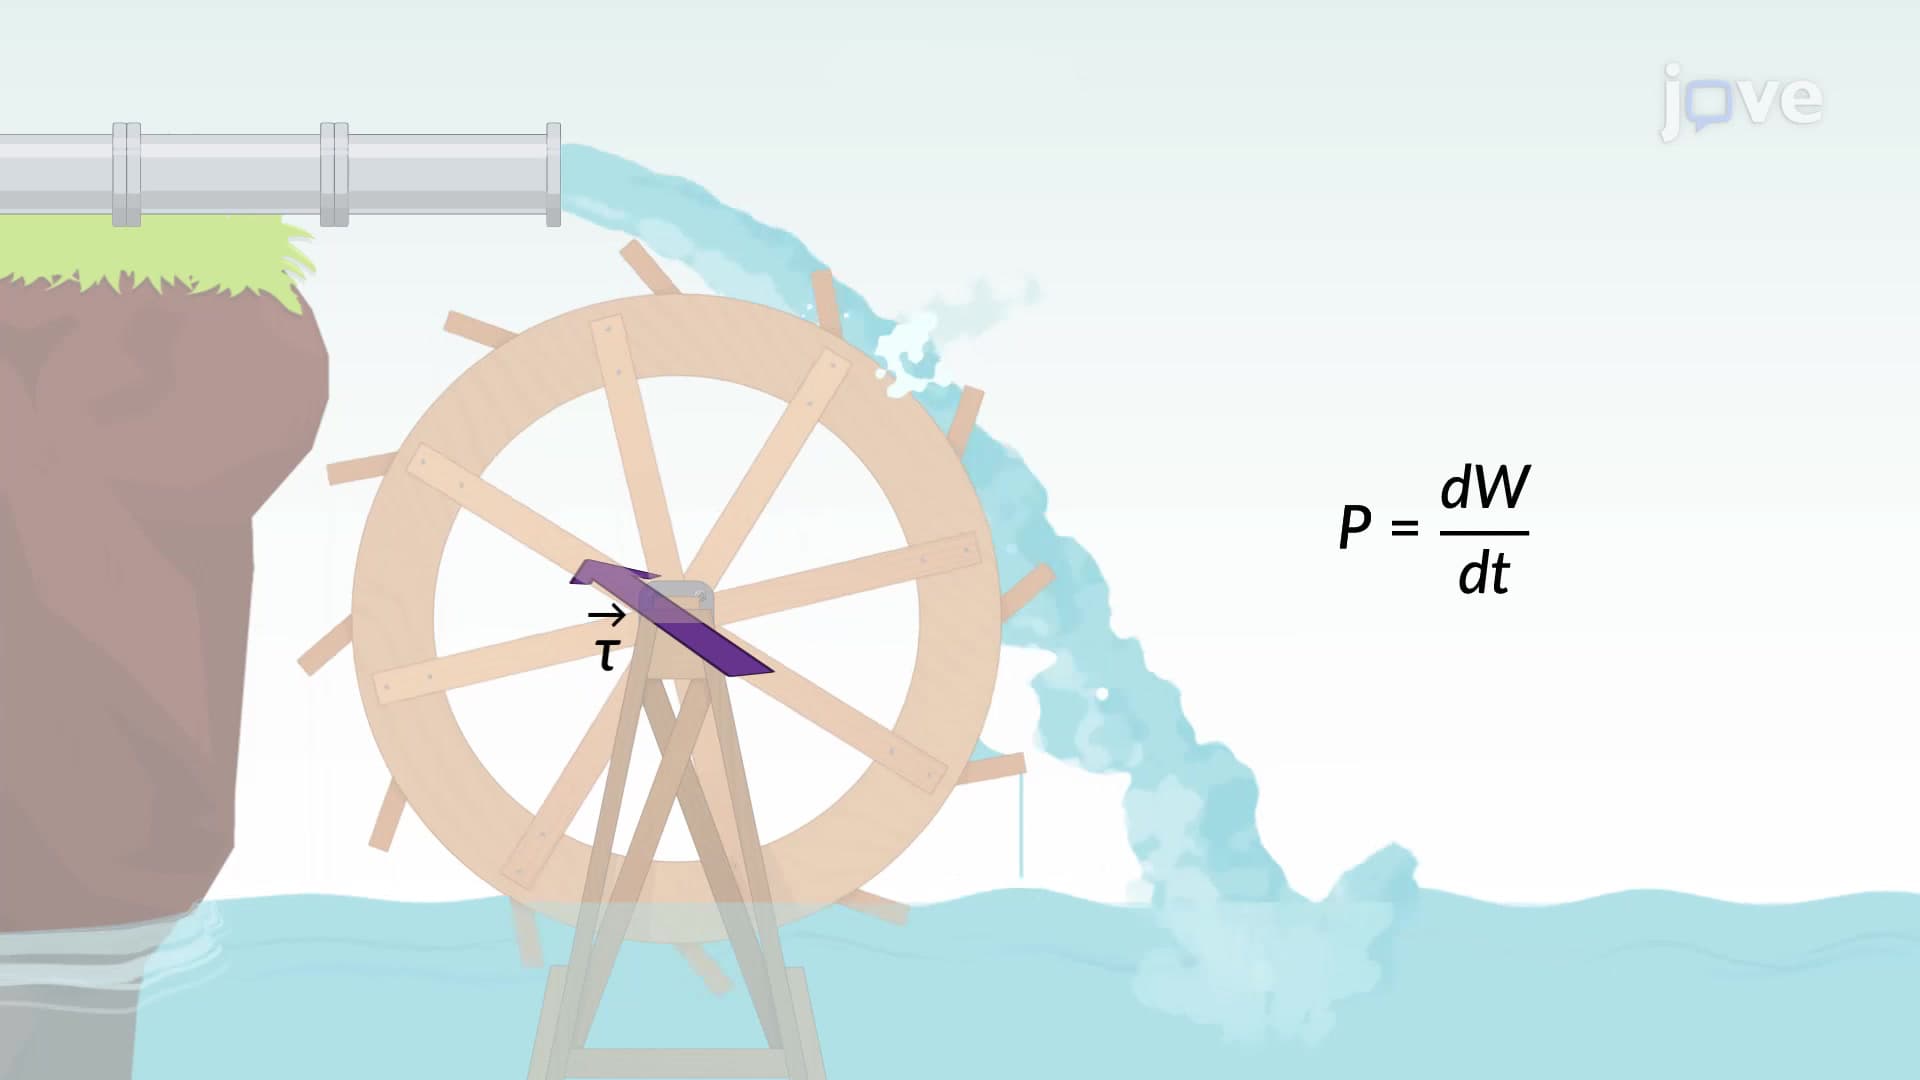
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis...