Related Experiment Video
Updated: Aug 25, 2025


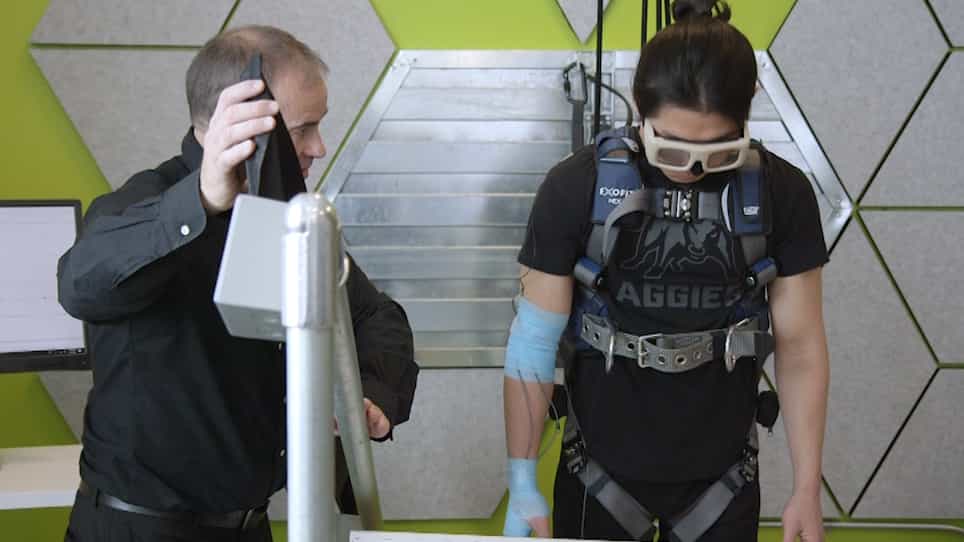
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Rethinking margin of stability: Incorporating step-to-step regulation to resolve the paradox
Meghan E Kazanski1, Joseph P Cusumano2, Jonathan B Dingwell1
1Department of Kinesiology, Pennsylvania State University, University Park, PA 16802, USA.

Abstract:
Derived from inverted pendulum dynamics, mediolateral Margin of Stability (MoSML) is a mechanically-grounded measure of instantaneous frontal-plane stability. However, average MoSML measures yield paradoxical results. Gait pathologies or perturbations often induce larger (supposedly "more stable") average MoSML, despite clearly destabilizing factors. However, people do not walk "on average" - they walk (and sometimes lose balance) one step at a time. We assert the paradox arises because averaging MoSML discards crucial step-to-step dynamics. We present a framework unifying the inverted pendulum with Goal-Equivalent Manifold (GEM) analyses. We identify in the pendulum's center-of-mass dynamics constant-MoSML manifolds, including one candidate "stability GEM" signifying the goal to maintain some constant MoSML∗. We used this framework to assess step-to-step MoSML dynamics of humans walking in destabilizing environments. While goal-relevant deviations were readily corrected, people did not exploit equifinality by allowing deviations to persist along this GEM. Thus, maintaining a constant MoSML∗ is inconsistent with observed step-to-step fluctuations in center-of-mass states. Conversely, the extent to which participants regulated fluctuations in mediolateral foot placements strongly predicted their regulation of center-of-mass fluctuations. Thus, center-of-mass dynamics may arise indirectly as a consequence of regulating mediolateral foot placements. To help resolve the paradox caused by averaging MoSML, we present a new statistic, Probability of Instability (PoIL), used here to predict lateral instability likelihood. Participants exhibited increased PoIL when destabilized (p = 9.45 × 10⁻³⁴), despite exhibiting larger ("more stable") average MoSML (p = 1.70 × 10⁻¹⁵). Thus, PoIL correctly captured people's increased risk of losing lateral balance, whereas average MoSML did not. PoIL also helps explain why people's average MoSML increased in destabilizing contexts.

Related Concept Videos
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...