Related Experiment Video
Updated: Aug 25, 2025
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
Spatio-temporal categorization for first-person-view videos using a convolutional variational autoencoder and
Masatoshi Nagano1, Tomoaki Nakamura1, Takayuki Nagai2,3
1Department of Mechanical Engineering and Intelligent Systems, The University of Electro-Communications, Tokyo, Japan.

Abstract:
In this study, HcVGH, a method that learns spatio-temporal categories by segmenting first-person-view (FPV) videos captured by mobile robots, is proposed. Humans perceive continuous high-dimensional information by dividing and categorizing it into significant segments. This unsupervised segmentation capability is considered important for mobile robots to learn spatial knowledge. The proposed HcVGH combines a convolutional variational autoencoder (cVAE) with HVGH, a past method, which follows the hierarchical Dirichlet process-variational autoencoder-Gaussian process-hidden semi-Markov model comprising deep generative and statistical models. In the experiment, FPV videos of an agent were used in a simulated maze environment. FPV videos contain spatial information, and spatial knowledge can be learned by segmenting them. Using the FPV-video dataset, the segmentation performance of the proposed model was compared with previous models: HVGH and hierarchical recurrent state space model. The average segmentation F-measure achieved by HcVGH was 0.77; therefore, HcVGH outperformed the baseline methods. Furthermore, the experimental results showed that the parameters that represent the movability of the maze environment can be learned.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Depth Perception and Spatial Vision
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:20
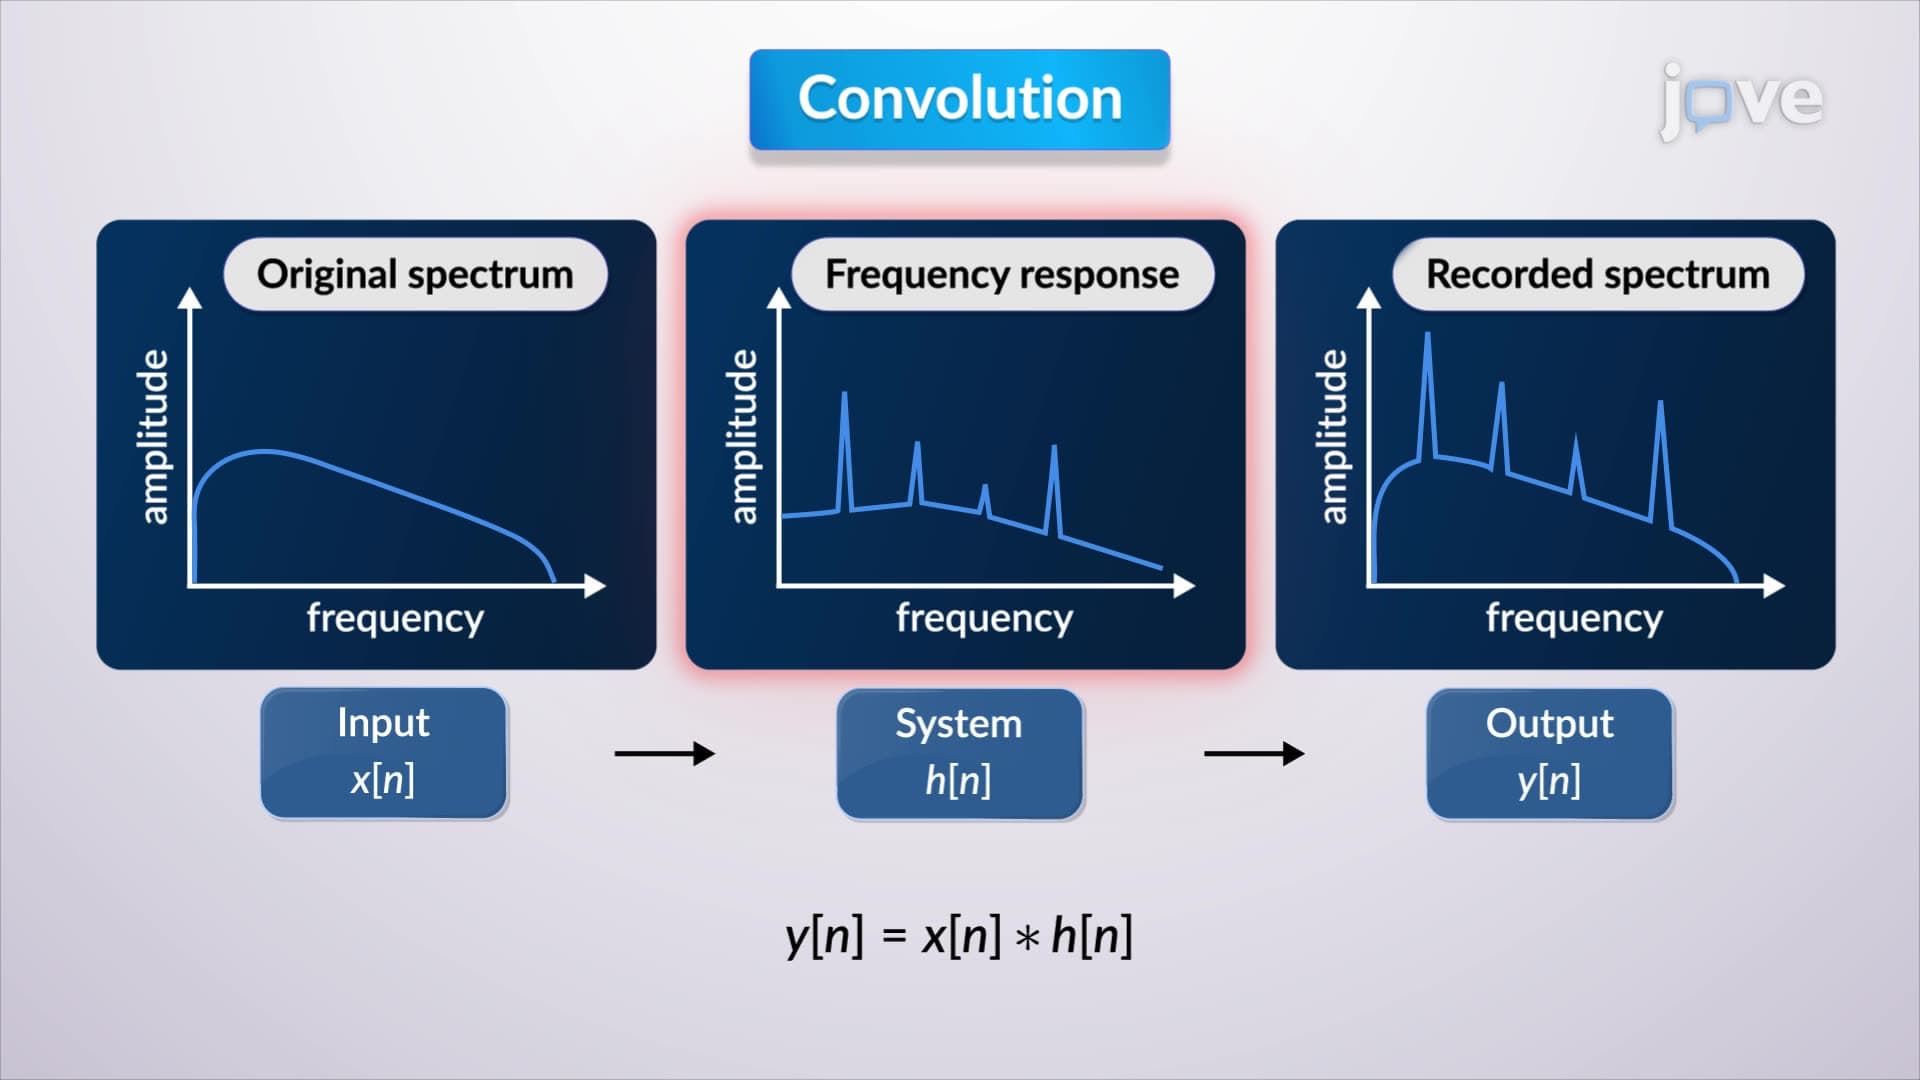
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...