Continuum robots for endoscopic sinus surgery: Recent advances, challenges, and prospects
Related Experiment Video
Updated: Aug 25, 2025
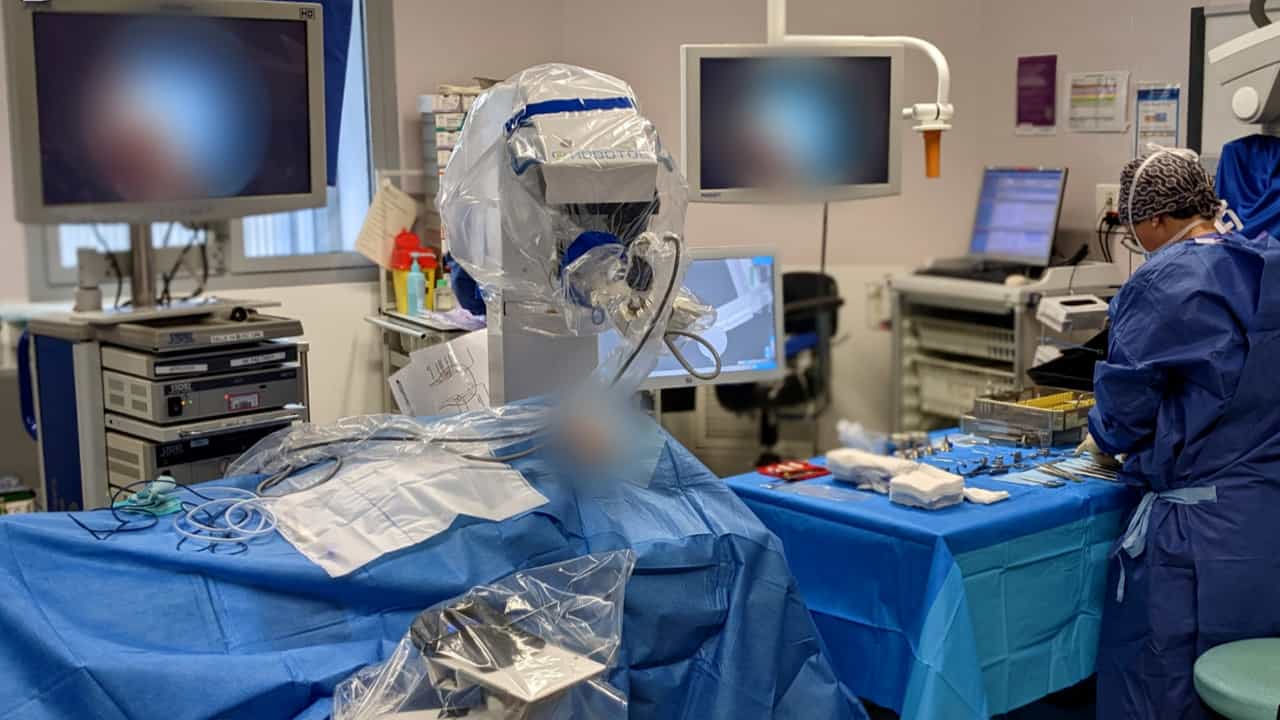
Robot-Assisted Transcanal Endoscopic Ear Surgery for Congenital Cholesteatoma
Published on: December 15, 2023
Yongfeng Cao1, Yuxuan Shi2,3, Wuzhou Hong1
1School of Materials Science and Engineering, Shanghai Jiao Tong University, Shanghai, China.

Purpose:
Endoscopic sinus surgery (ESS) has been recognized as an effective treatment modality for paranasal sinus diseases. Over the past decade, continuum robots (CRs) for ESS have been studied, but there are still some challenges. This paper presents a review on the scientific studies of CRs for ESS.
Methods:
Based on the analysis of the anatomical structure of the paranasal sinus, the requirements of CRs for ESS are discussed. Recent studies on rigid robots, handheld flexible robots, and CRs for ESS are presented. Surgical path planning, navigation, and control are also included.
Results:
Concentric tube CRs and cable-driven CRs have great potential for applications in ESS. The CRs incorporated with multiple replaceable arms with different functions are preferable in ESS.
Conclusion:
Further study on navigation and control is required to improve the performance of CRs for ESS.
More Related Videos
Related Concept Videos
 01:28
Endoscopic Procedures III: Video Capsule Endoscopy
 01:30
Endoscopic Studies I: Bronchoscopy and Thoracoscopy
Bronchoscopy
Description
Bronchoscopy is a procedure that involves direct visualization of the larynx, trachea, and bronchi for diagnostic and therapeutic purposes. A flexible fiber optic or rigid bronchoscope is used to carry out the procedure. The fiber-optic bronchoscope is more frequently used due...
 01:26
Endoscopic Procedures V: ERCP
Patient...