Related Experiment Video
Updated: Aug 24, 2025
Automated Interactive Video Playback for Studies of Animal Communication
Published on: February 9, 2011
Hamiltonian-Driven Adaptive Dynamic Programming With Efficient Experience Replay

Abstract:
This article presents a novel efficient experience-replay-based adaptive dynamic programming (ADP) for the optimal control problem of a class of nonlinear dynamical systems within the Hamiltonian-driven framework. The quasi-Hamiltonian is presented for the policy evaluation problem with an admissible policy. With the quasi-Hamiltonian, a novel composite critic learning mechanism is developed to combine the instantaneous data with the historical data. In addition, the pseudo-Hamiltonian is defined to deal with the performance optimization problem. Based on the pseudo-Hamiltonian, the conventional Hamilton-Jacobi-Bellman (HJB) equation can be represented in a filtered form, which can be implemented online. Theoretical analysis is investigated in terms of the convergence of the adaptive critic design and the stability of the closed-loop systems, where parameter convergence can be achieved under a weakened excitation condition. Simulation studies are investigated to verify the efficacy of the presented design scheme.

Related Concept Videos
 01:16
Statically Indeterminate Problem Solving
 02:20
Dynamic Equilibrium
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
 01:16
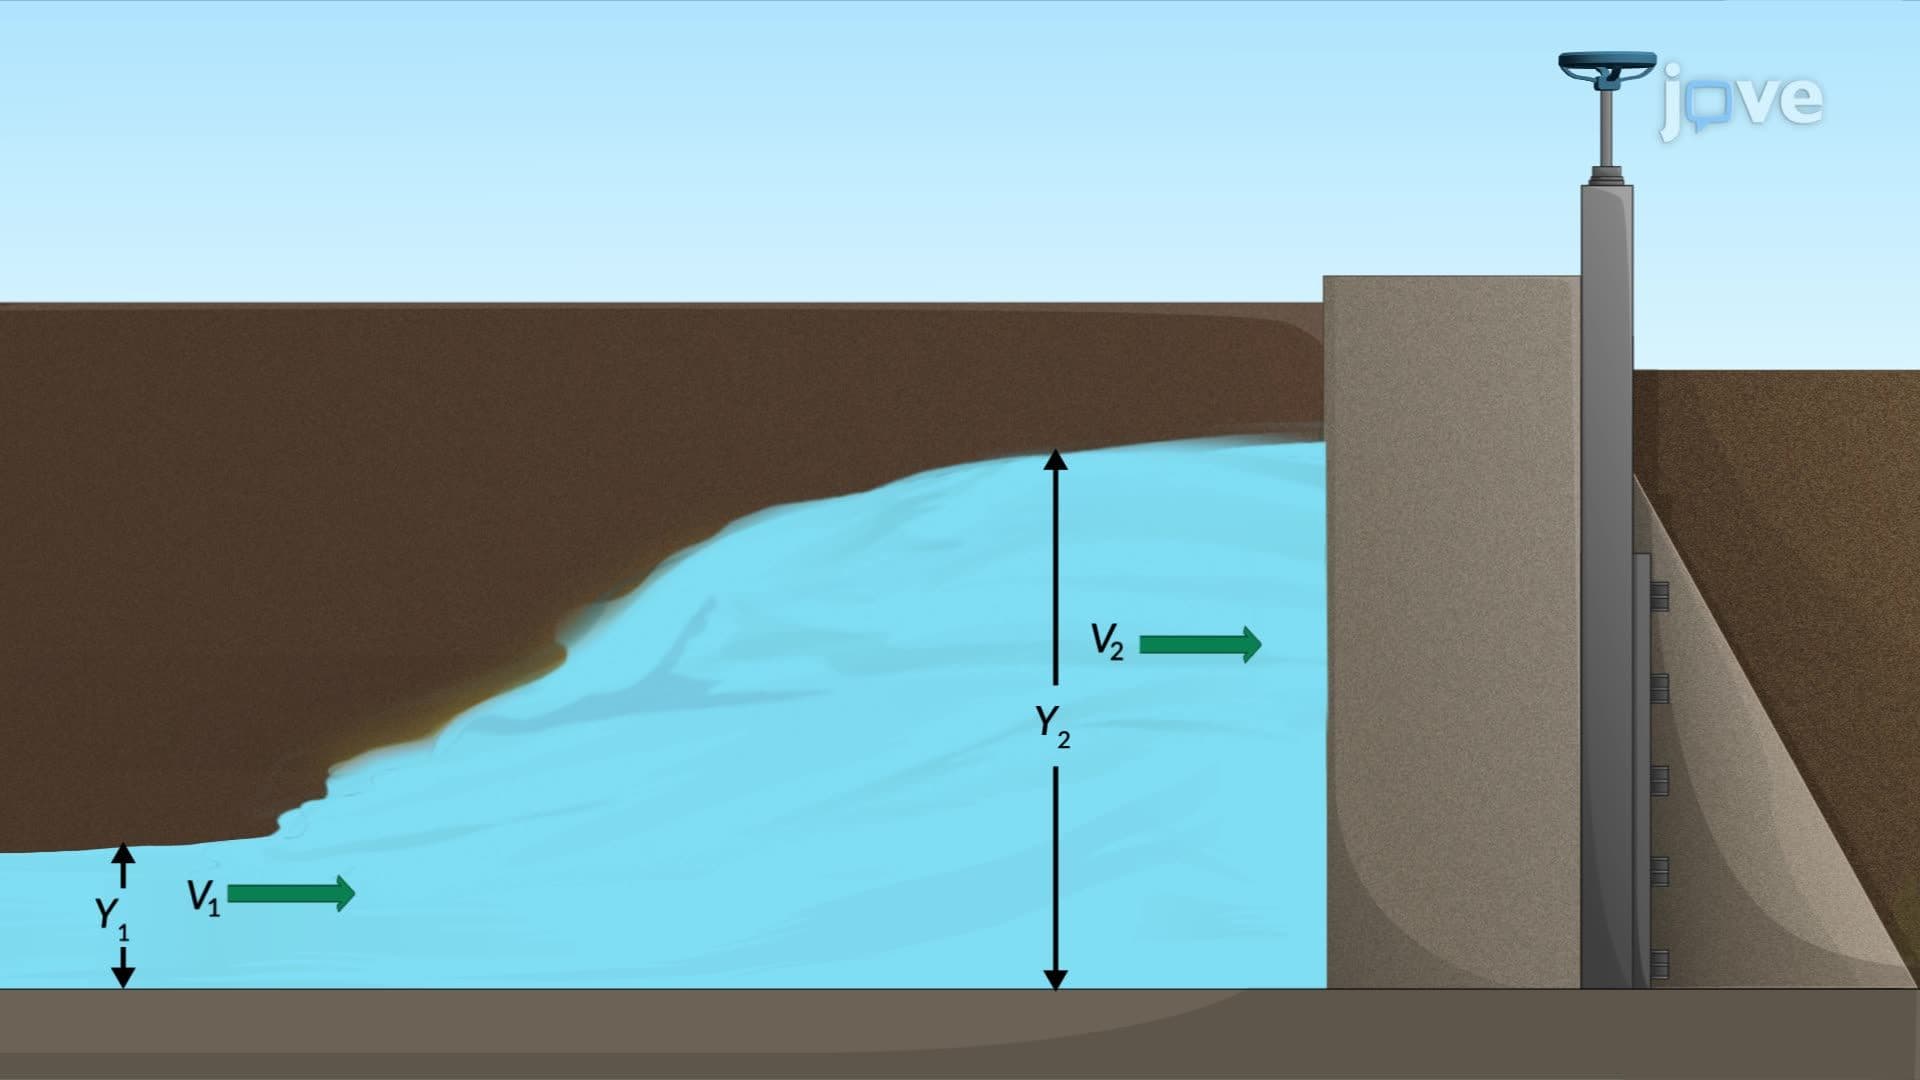
Hydraulic Jump: Problem Solving
 01:17
Ampere-Maxwell's Law: Problem-Solving
To solve the problem, we can use the equations from the analysis of an RC circuit and Maxwell's version of Ampère's law.
For the first part of...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...