Related Experiment Video
Updated: Aug 23, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Robust Control Strategy of Gradient Magnetic Drive for Microrobots Based on Extended State Observer
Jiawei Lu1, Yueyue Liu1, Wentao Huang1
1College of Internet of Things Engineering, Jiangnan University, Wuxi 214000, China.

Abstract:
Microrobots have great application potential in the biomedical field, to realize the precision and efficiency of microrobots in vivo is research focus in this field. Microrobots are accompanied by various disturbances in complex environment. These disturbances will affect the motion control of microrobots, resulting in the inability of the micromanipulation tasks to be completed effectively. To this end, a robust motion control method is proposed for precise path tracking of microrobots in this paper. The extended state observer (ESO) is used to estimate the total disturbances and uncertainties of the system. A path tracking controller is designed by combining sliding mode control (SMC) and disturbances compensation, which is used to eliminate the total disturbances of the system and realize the fast and accurate path tracking of microrobots. Finally, the path tracking experiments are implemented in the gradient magnetic field drive system. The experimental results show that the mean absolute error of the path tracking for microrobots in a simulated vascular structure is less than 14 μm, and the root mean square error is less than 17 μm by using the robust control method proposed in this paper. Compared with the traditional PID control method, it can better suppress external disturbances and uncertainties of the system and improve the path tracking accuracy of microrobots effectively. It shows stronger anti-interference ability and robustness.
More Related Videos
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:13
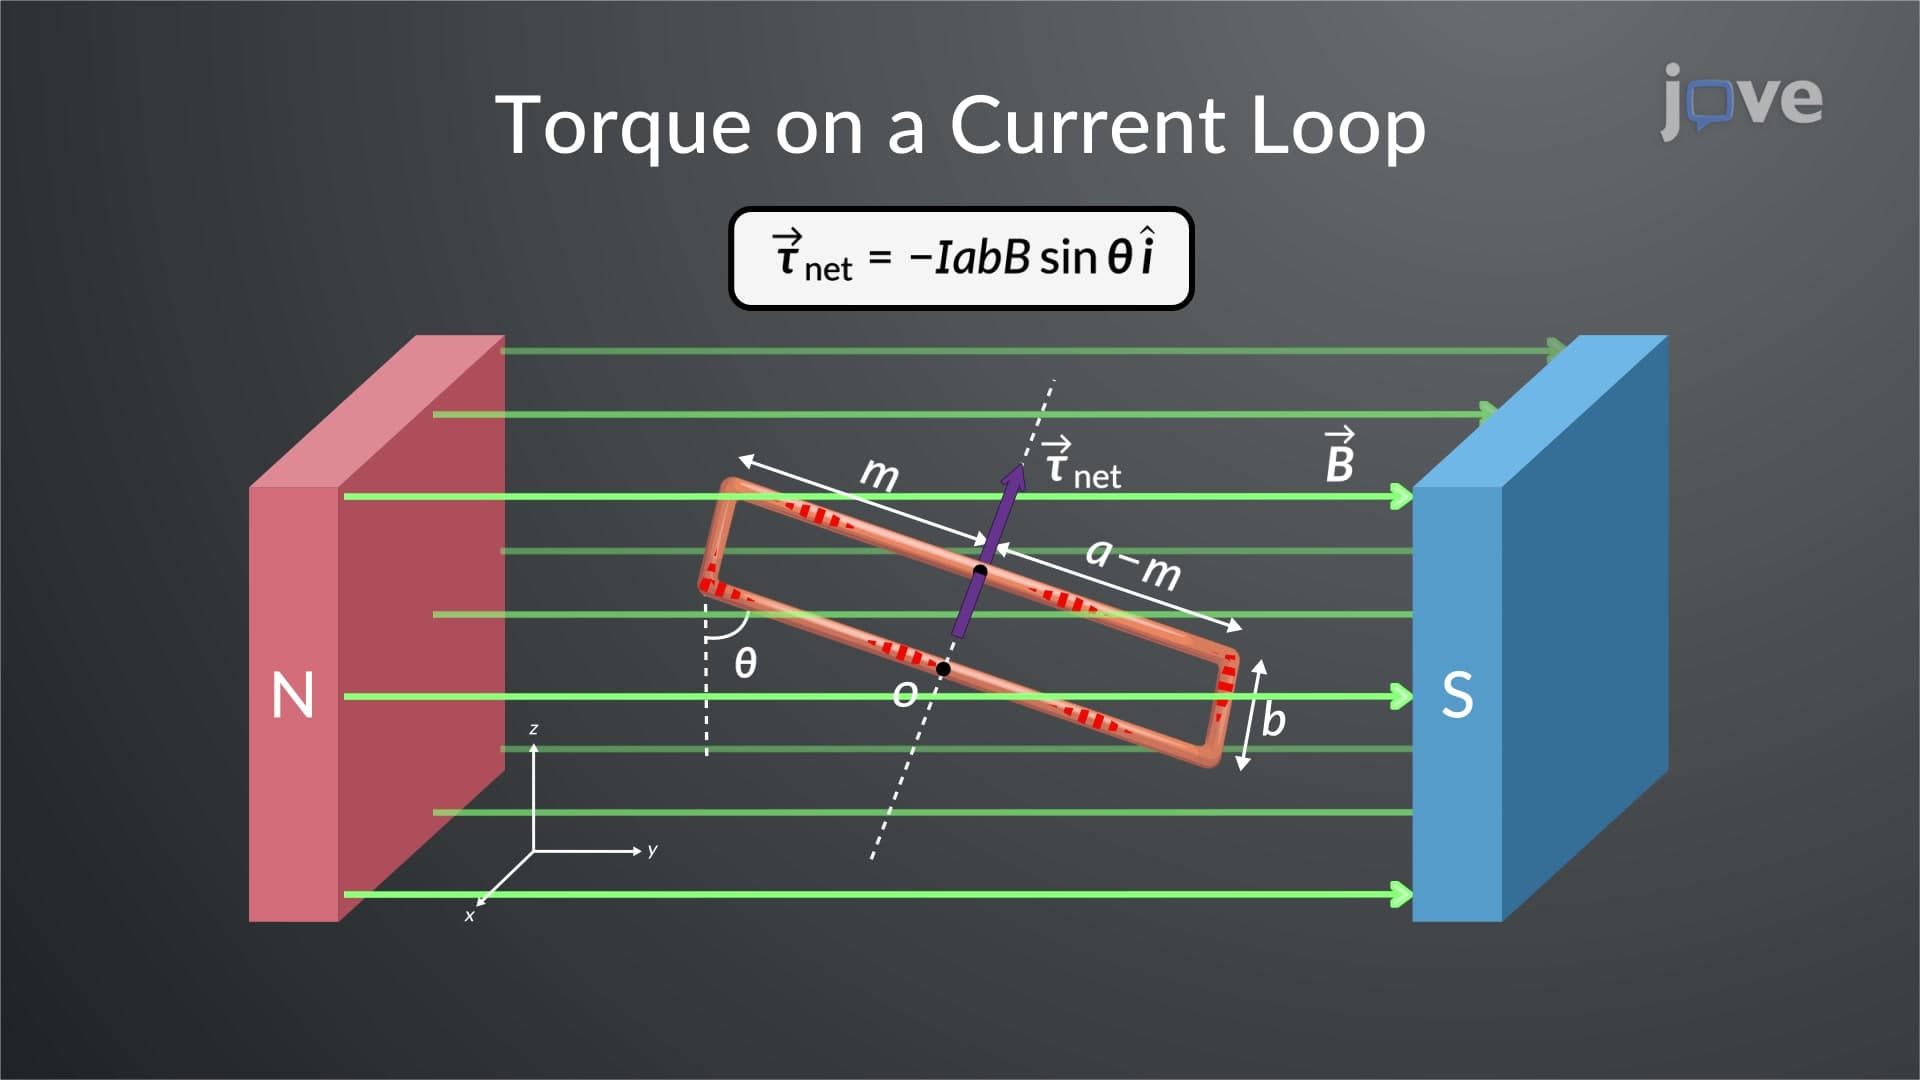
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:19
PID Controller