Related Experiment Video
Updated: Aug 22, 2025


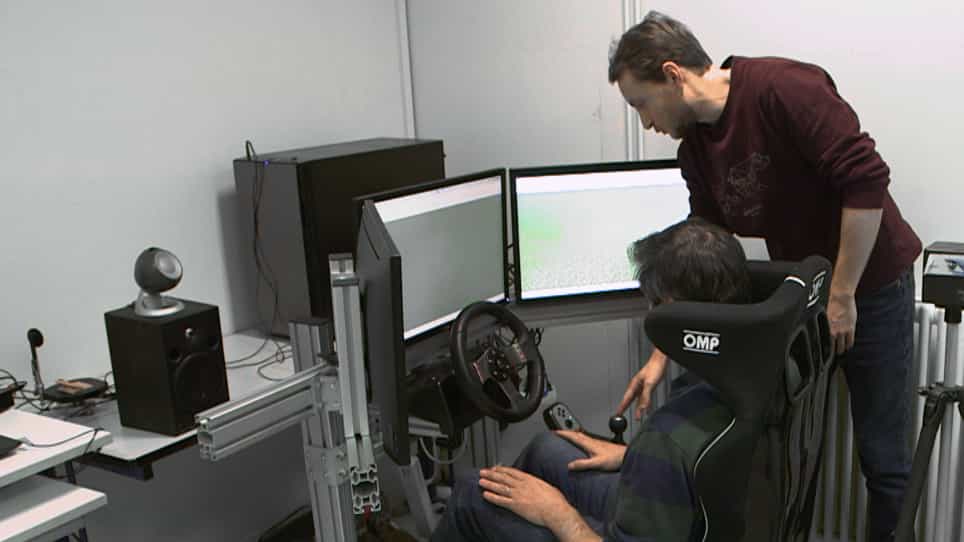
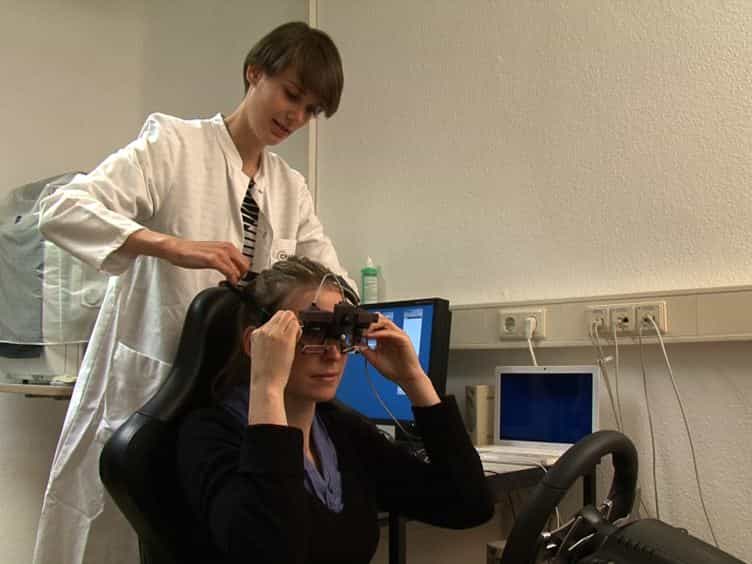
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Examining the Effects of Visibility and Time Headway on the Takeover Risk during Conditionally Automated Driving
Haorong Peng1,2, Feng Chen3, Peiyan Chen3
1Tongji Architectural Design (Group) Co., Ltd., 1230 Siping Road, Yangpu, Shanghai 200092, China.

Abstract:
The objective of this study is to examine the effects of visibility and time headway on the takeover performance in L3 automated driving. Both non-critical and critical driving scenarios were considered by changing the acceleration value of the leading vehicle. A driving simulator experiment with 18 driving scenarios was conducted and 30 participants complete the experiment. Based on the data obtained from the experiment, the takeover reaction time, takeover control time, and takeover responses were analyzed. The minimum Time-To-Collision (Min TTC) was used to measure the takeover risk level and a binary logit model for takeover risk levels was estimated. The results indicate that the visibility distance (VD) has no significant effects on the takeover control time, while the time headway (THW) and the acceleration of the leading vehicle (ALV) could affect the takeover control time significantly; most of the participants would push the gas pedal to accelerate the ego vehicle as the takeover response under non-critical scenarios, while braking was the dominant takeover response for participants in critical driving scenarios; decreasing the TCT and taking the appropriate takeover response would reduce the takeover risk significantly, so it is suggested that the automation system should provide the driver with the urgency of the situation ahead and the tips for takeover responses by audio prompts or the head-up display. This study is expected to facilitate the overall understanding of the effects of visibility and time headway on the takeover performance in conditionally automated driving.
More Related Videos
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:29
Sight Distance in a Vertical Curve
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility