Related Experiment Video
Updated: Aug 22, 2025


Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
Oriented Vehicle Detection in Aerial Images Based on YOLOv4
1Department of Information & Computer Engineering, Chung Yuan Christian University, Taoyuan 320, Taiwan.

Abstract:
CNN-based object detectors have achieved great success in recent years. The available detectors adopted horizontal bounding boxes to locate various objects. However, in some unique scenarios, objects such as buildings and vehicles in aerial images may be densely arranged and have apparent orientations. Therefore, some approaches extend the horizontal bounding box to the oriented bounding box to better extract objects, usually carried out by directly regressing the angle or corners. However, this suffers from the discontinuous boundary problem caused by angular periodicity or corner order. In this paper, we propose a simple but efficient oriented object detector based on YOLOv4 architecture. We regress the offset of an object's front point instead of its angle or corners to avoid the above mentioned problems. In addition, we introduce the intersection over union (IoU) correction factor to make the training process more stable. The experimental results on two public datasets, DOTA and HRSC2016, demonstrate that the proposed method significantly outperforms other methods in terms of detection speed while maintaining high accuracy. In DOTA, our proposed method achieved the highest mAP for the classes with prominent front-side appearances, such as small vehicles, large vehicles, and ships. The highly efficient architecture of YOLOv4 increases more than 25% detection speed compared to the other approaches.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 02:16
Light Acquisition
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:20
Deconvolution
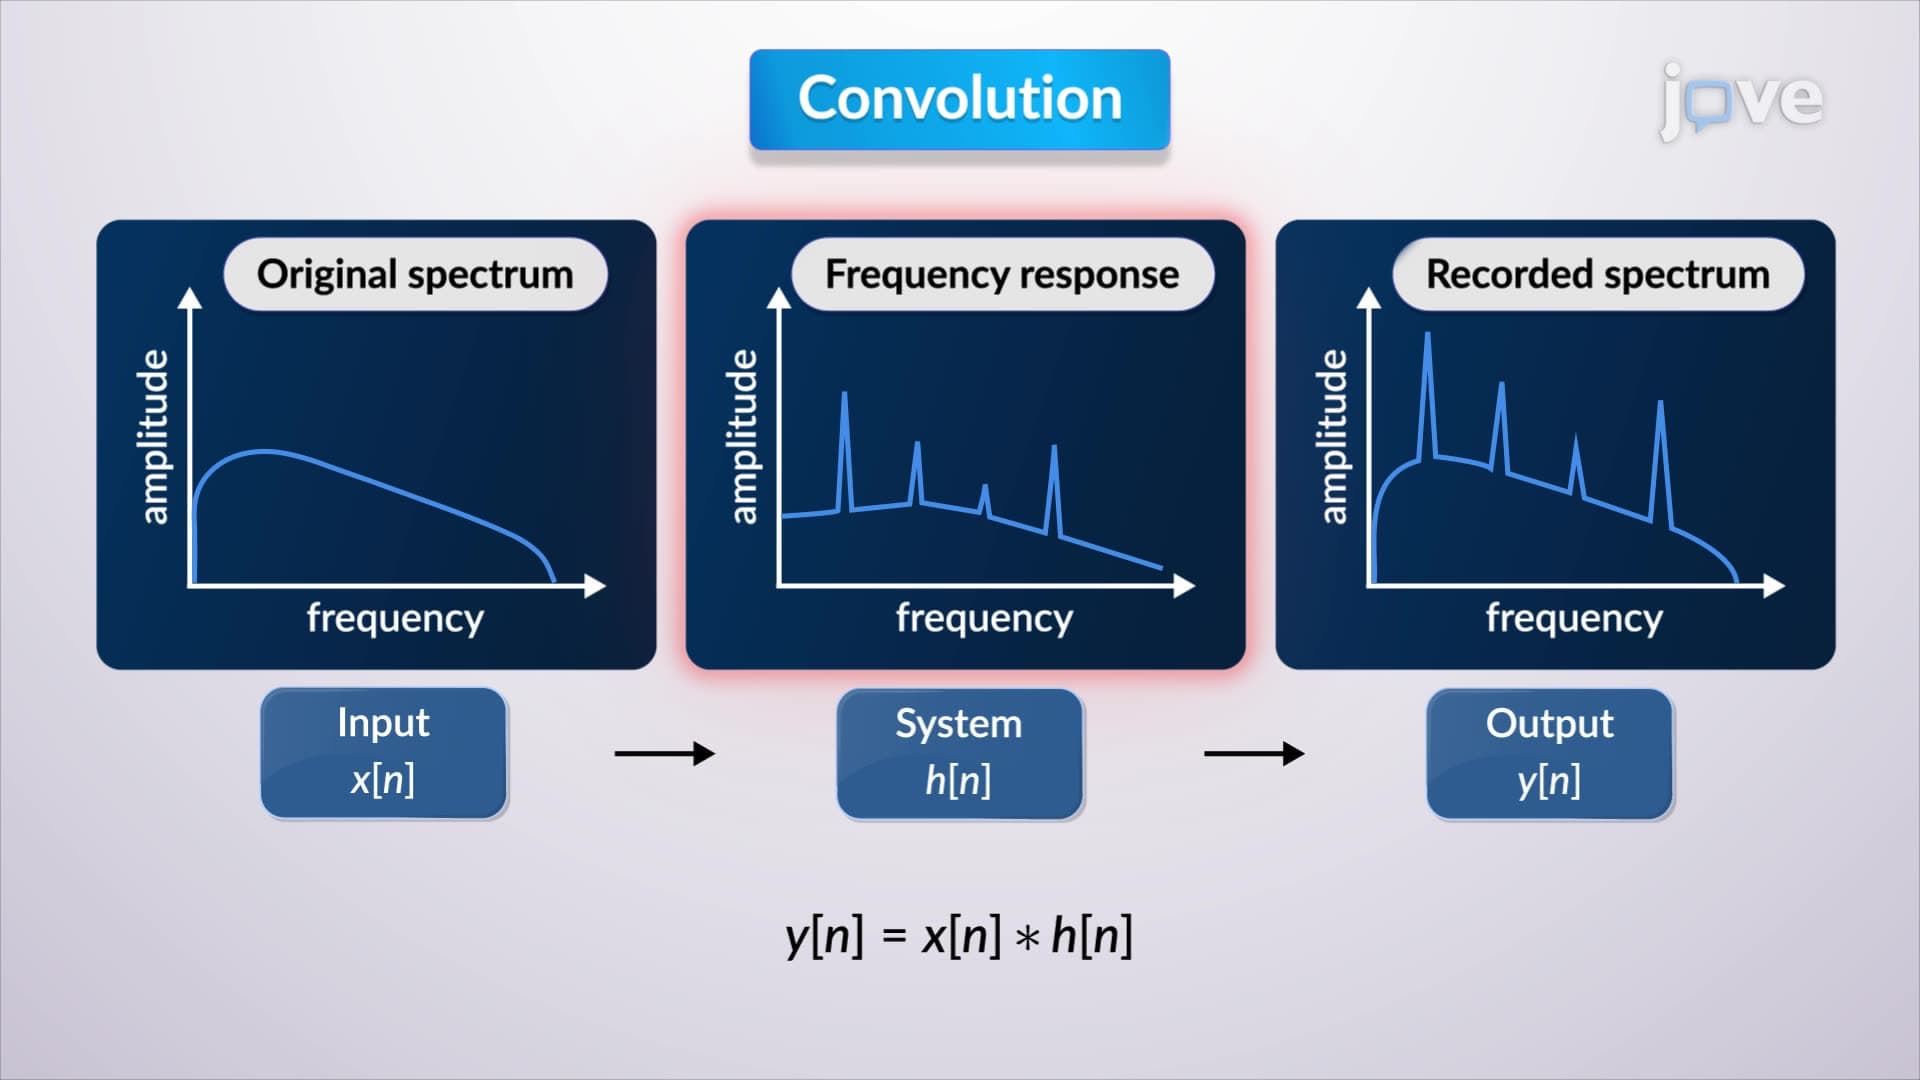
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...