

Aeroelastics-aware compensation system for soft aerial vehicle stabilization
Fernando Ruiz1, Begoña C Arrue1, Aníbal Ollero1
1GRVC Aerial Robotics Laboratory, University of Seville, Seville, Spain.

Abstract:
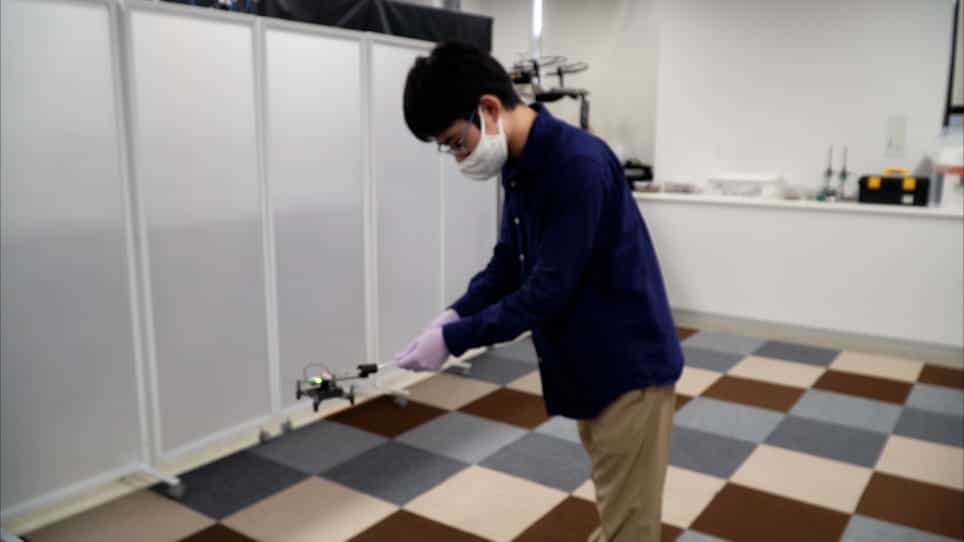
This paper describes a compensation system for soft aerial vehicle stabilization. Balancing the arms is one of the main challenges of soft UAVs since the propeller is freely tilting together with the flexible arm. In comparison with previous designs, in which the autopilot was adjusted to deal with these imbalances with no extra actuation, this work introduces a soft tendon-actuated system to achieve in-flight stabilization in an energy-efficient way. The controller is specifically designed for disturbance rejection of aeroelastic perturbations using the Ziegler-Nichols method, depending on the flight mode and material properties. This aerodynamics-aware compensation system allows to further bridge the gap between soft and aerial robotics, leading to an increase in the flexibility of the UAV, and the ability to deal with changes in material properties, increasing the useful life of the drone. In energetic terms, the novel system is 15-30% more efficient, and is the basis for future applications such as object grasping.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Gyroscope: Precession
 01:02
Gyroscope