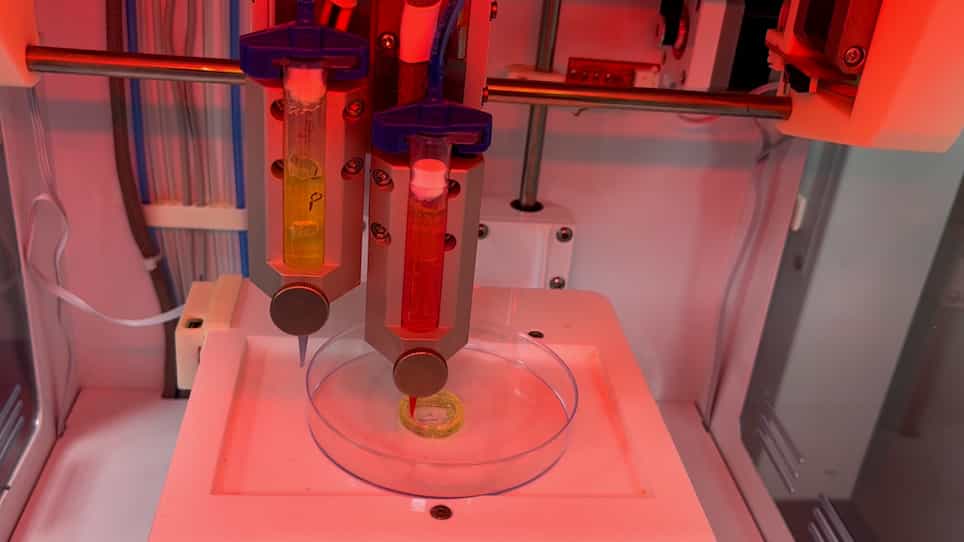
Related Experiment Video
Updated: Aug 19, 2025


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Bioinspired 3D-Printed Snakeskins Enable Effective Serpentine Locomotion of a Soft Robotic Snake
Xinda Qi1, Tong Gao2,3, Xiaobo Tan1
1Department of Electrical and Computer Engineering, Science and Engineering, Michigan State University, East Lansing, Michigan, USA.

Abstract:
We present a multi-material three-dimensional-printed snakeskin with orthotropic friction anisotropy, which permits undulatory slithering of a soft snake robot on rough surfaces. Such a snakeskin is composed of a soft skin base and embedded rigid scales attached to the robot's ventral surface. The bioinspired designs of scale shapes and arrangements lead effectively to various types of anisotropic friction, and provide means of switching robot's locomotion direction to be either the same as or opposite to the propagation direction of the traveling-wave undulation. Furthermore, steering of locomotion can be achieved by applying additional pressure bias in one air path to break symmetry of body deformation. We also successfully demonstrate the snake robot's mobility on various outdoor rough substrates, including concrete surfaces and a grass lawn, as well as pipes of different dimensions and materials, for potential field applications.