Robust observer design for LPV systems using Kronecker sum and direct searching
Related Experiment Video
Updated: Aug 19, 2025
Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
Nahid Abbasi1, Maryam Dehghani1, Mohammad Hasan Asemani1
1School of Electrical and Computer Engineering, Shiraz University, Shiraz, Iran.

Abstract:
This paper addresses a robust Luenberger observer for an uncertain linear parameter varying (LPV) system based on the concepts of direct searching, Kronecker sum, and small gain theorem. An algorithm is proposed to investigate the situation of the different parts of the initial observer design space, in terms of suitability for being selected as the observer gain or needing elimination due to being an undesirable part. To find the undesirable parts of the design space, the singularity of the Kronecker sum matrix of the estimation error is checked by employing the small gain theorem concept. By excluding undesired parts from the entire design space and checking the remaining parts' feasibility, a suitable solution can be found, appropriately. The performance of the proposed observer design method is illustrated by using numerical examples and an electric ground vehicle (EGV) system for the estimation of the vehicle sideslip angle and the yaw rate. The results prove the appropriateness of the designed observer using the proposed approach.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 04:15
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Related Concept Videos
 01:19
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:05
Properties of the Root Locus
To determine if a point lies on the root locus, the criterion involves the sum of angles contributed by all poles and zeros to that point. Specifically, this sum must be an odd multiple of 180 degrees. The gain at any point on...
 01:15
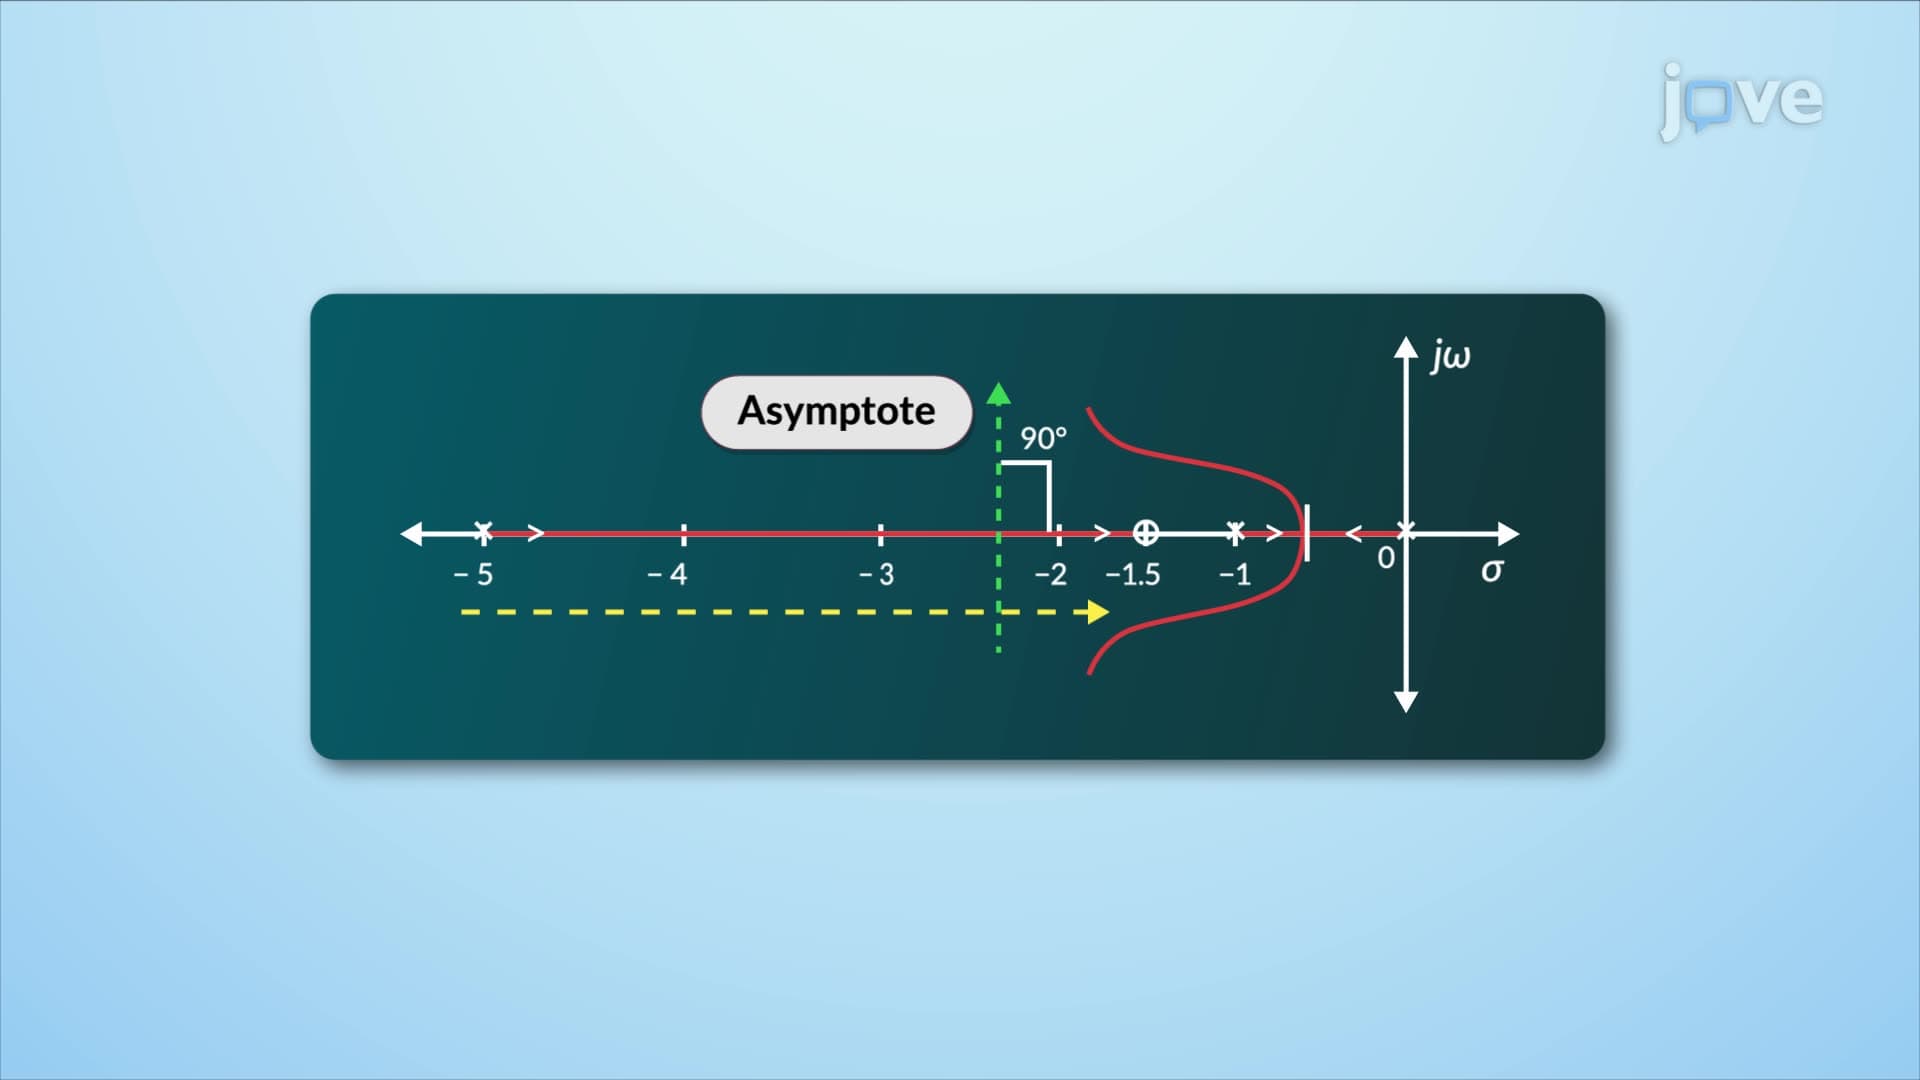
Construction of Root Locus
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
PI Controller: Design