Related Experiment Video
Updated: Aug 18, 2025
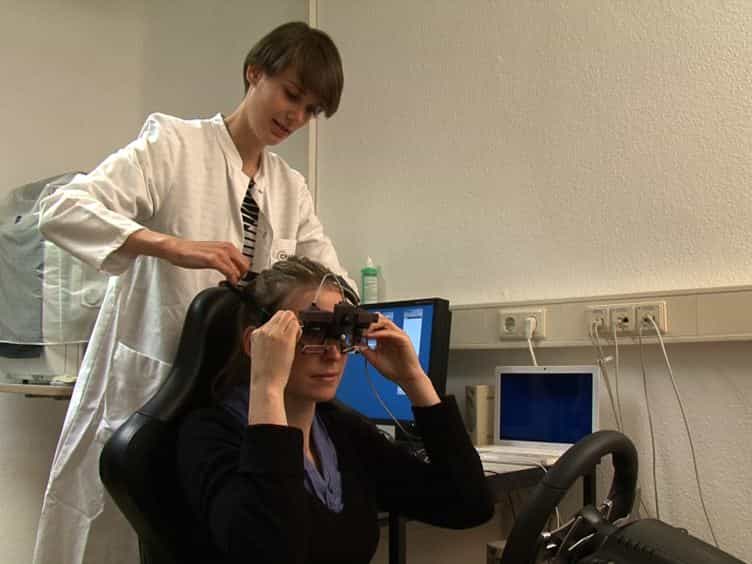

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Autonomous driving using imitation learning with look ahead point for semi structured environments
Joonwoo Ahn1, Minsoo Kim1, Jaeheung Park2,3,4
1Dynamic Robotic Systems (DYROS) Lab., Graduate School of Convergence Science and Technology, Seoul National University, 1, Gwanak-ro, Seoul, 08826, Republic of Korea.

Abstract:
Semi-structured environments are difficult for autonomous driving because there are numerous unknown obstacles in drivable area without lanes, and its width and curvature considerably change. In such environments, searching for a path on a real-time is difficult, and localization data are inaccurate, reducing path tracking accuracy. Instead, alternative methods that reactively avoid obstacles in real-time using candidate paths or an artificial potential field have been studied. However, these require heuristics to identify specific parameters for handling various environments and are vulnerable to inaccurate input data. To address these limitations, this study proposes a method in which a vehicle drives toward drivable area using vision and deep learning. The proposed imitation learning method learns the look-ahead point where the vehicle should reach on a vision-based occupancy grid map to obtain a safe policy with a clear state action pattern relationship. Furthermore, using this point, the data aggregation (DAgger) algorithm with weighted loss function is proposed, which imitates expert behavior more accurately, especially in unsafe or near-collision situations. Experimental results in actual semi-structured environments demonstrated the limitations of general model-based methods and the effectiveness of the proposed imitation learning method. Moreover, simulation experiments showed that DAgger with the weight obtains a safer policy than existing DAgger algorithms.

Related Concept Videos
 01:12
Observational Learning
 01:22
Purposive Learning
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...