Related Experiment Video
Updated: Aug 17, 2025
Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
UVMS task-priority planning framework for underwater task goal classification optimization
Yu-Er Gao1,2, Xiaohui Zhang1,2, Yan Su1,2
1Department of Information and Control Engineering, Xi'an University of Technology, Xi'an, China.

Abstract:
This paper presents a task prioritization strategy based on a generic underwater task goal classification transformation for multitasking underwater operational tasks: attitude control, floating manipulation, collision-free motion, especially optimizing trajectory of the end-effector of an underwater vehicle manipulator system (UVMS) in a complex marine environment. The design framework aims to divide the complex underwater operational tasks into UVMS executable generic task combinations and optimize the resource consumption during the whole task. In order to achieve the corresponding underwater task settings, the system needs to satisfy different task scheduling structures. We consider the actual application scenarios of the operational goals and prioritize and define each category of task hierarchy accordingly. Multiple tasks simultaneously enable fast adaptation to UVMS movements and planning to complete UVMS autonomous movements. Finally, an underwater vehicle manipulator system implements the task prioritization planning framework for a practical scenario with different constraints on different goals. We quickly and precisely realize the interconversion of different tasks under goal constraints. The autonomous motion planning and real-time performance of UVMS are improved to cope with the increasing operational task requirements and the complex and changing practical engineering application environments.
More Related Videos
 11:53
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
 07:52
Author Spotlight: Advancing Human Brain Modulation – Optimized Protocols for Transcranial Ultrasound Stimulation Experiments
Published on: June 28, 2024
Related Concept Videos
 01:11
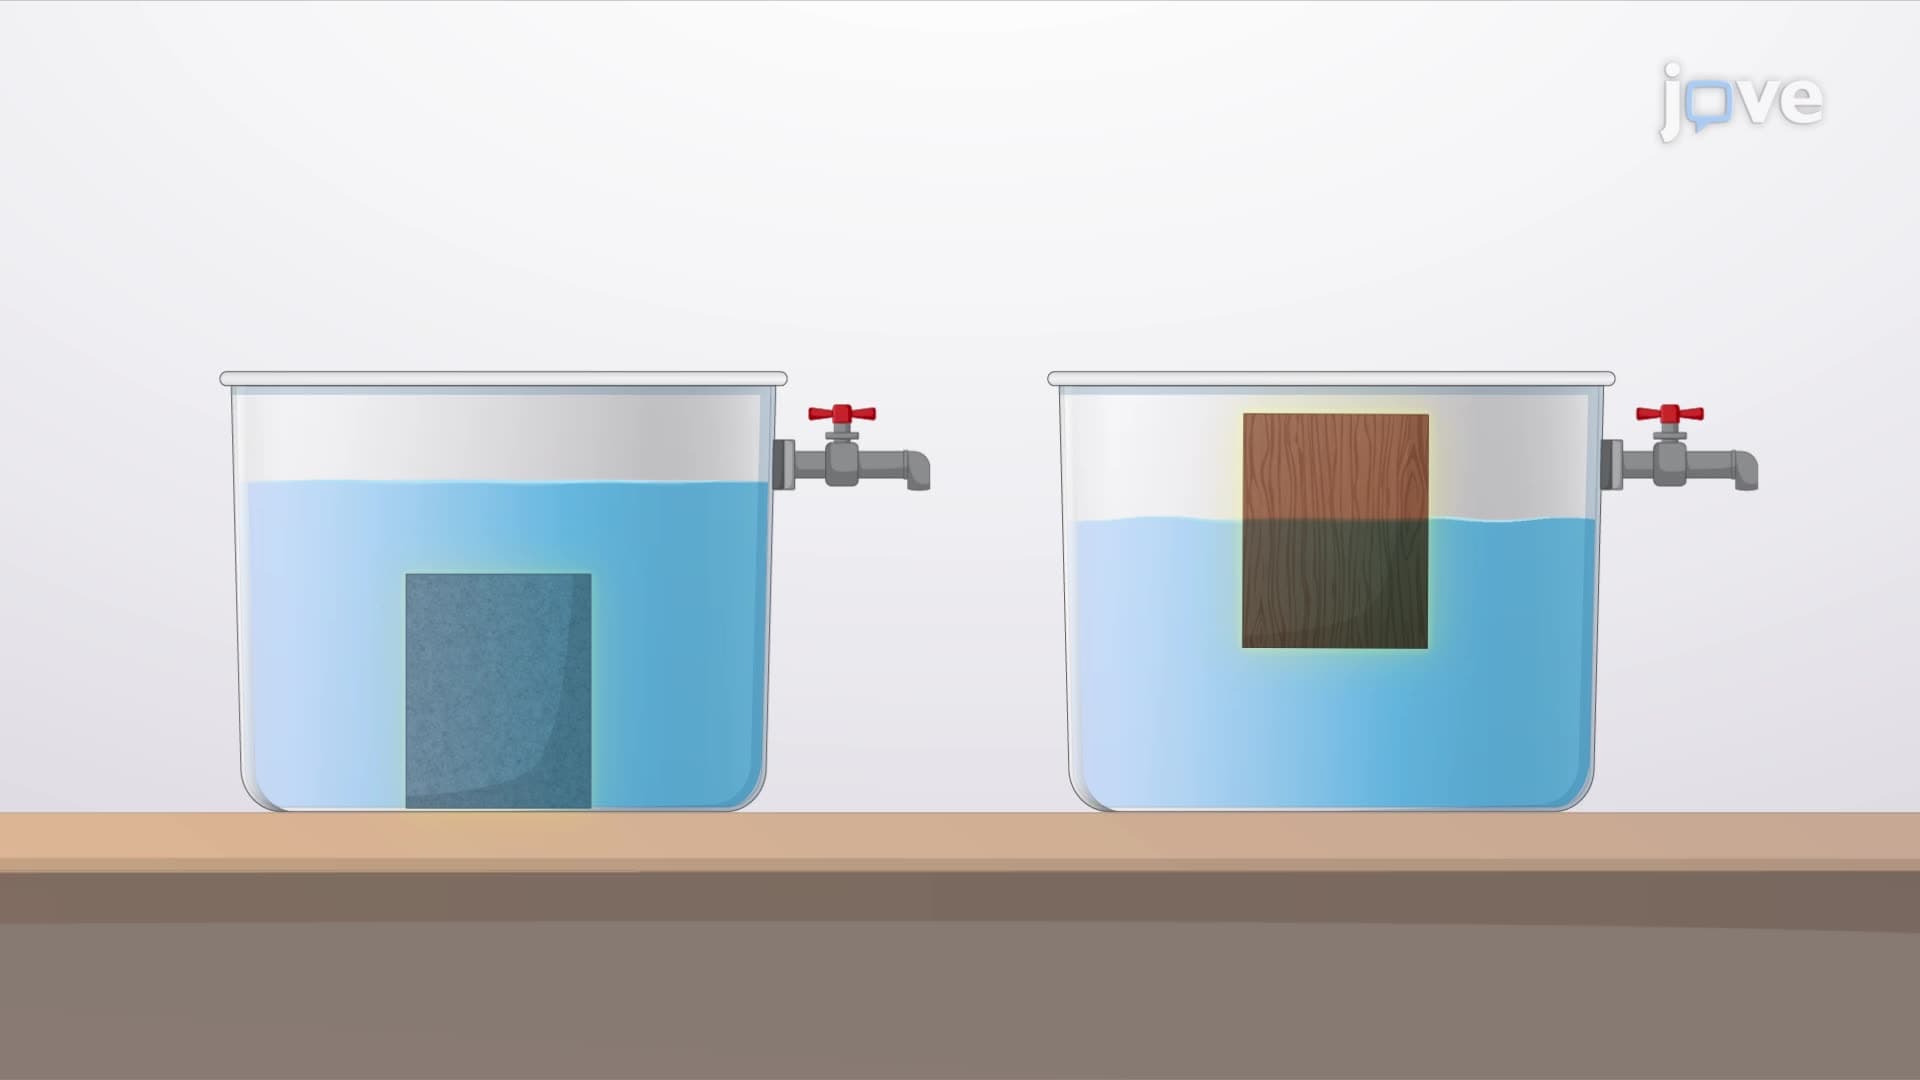
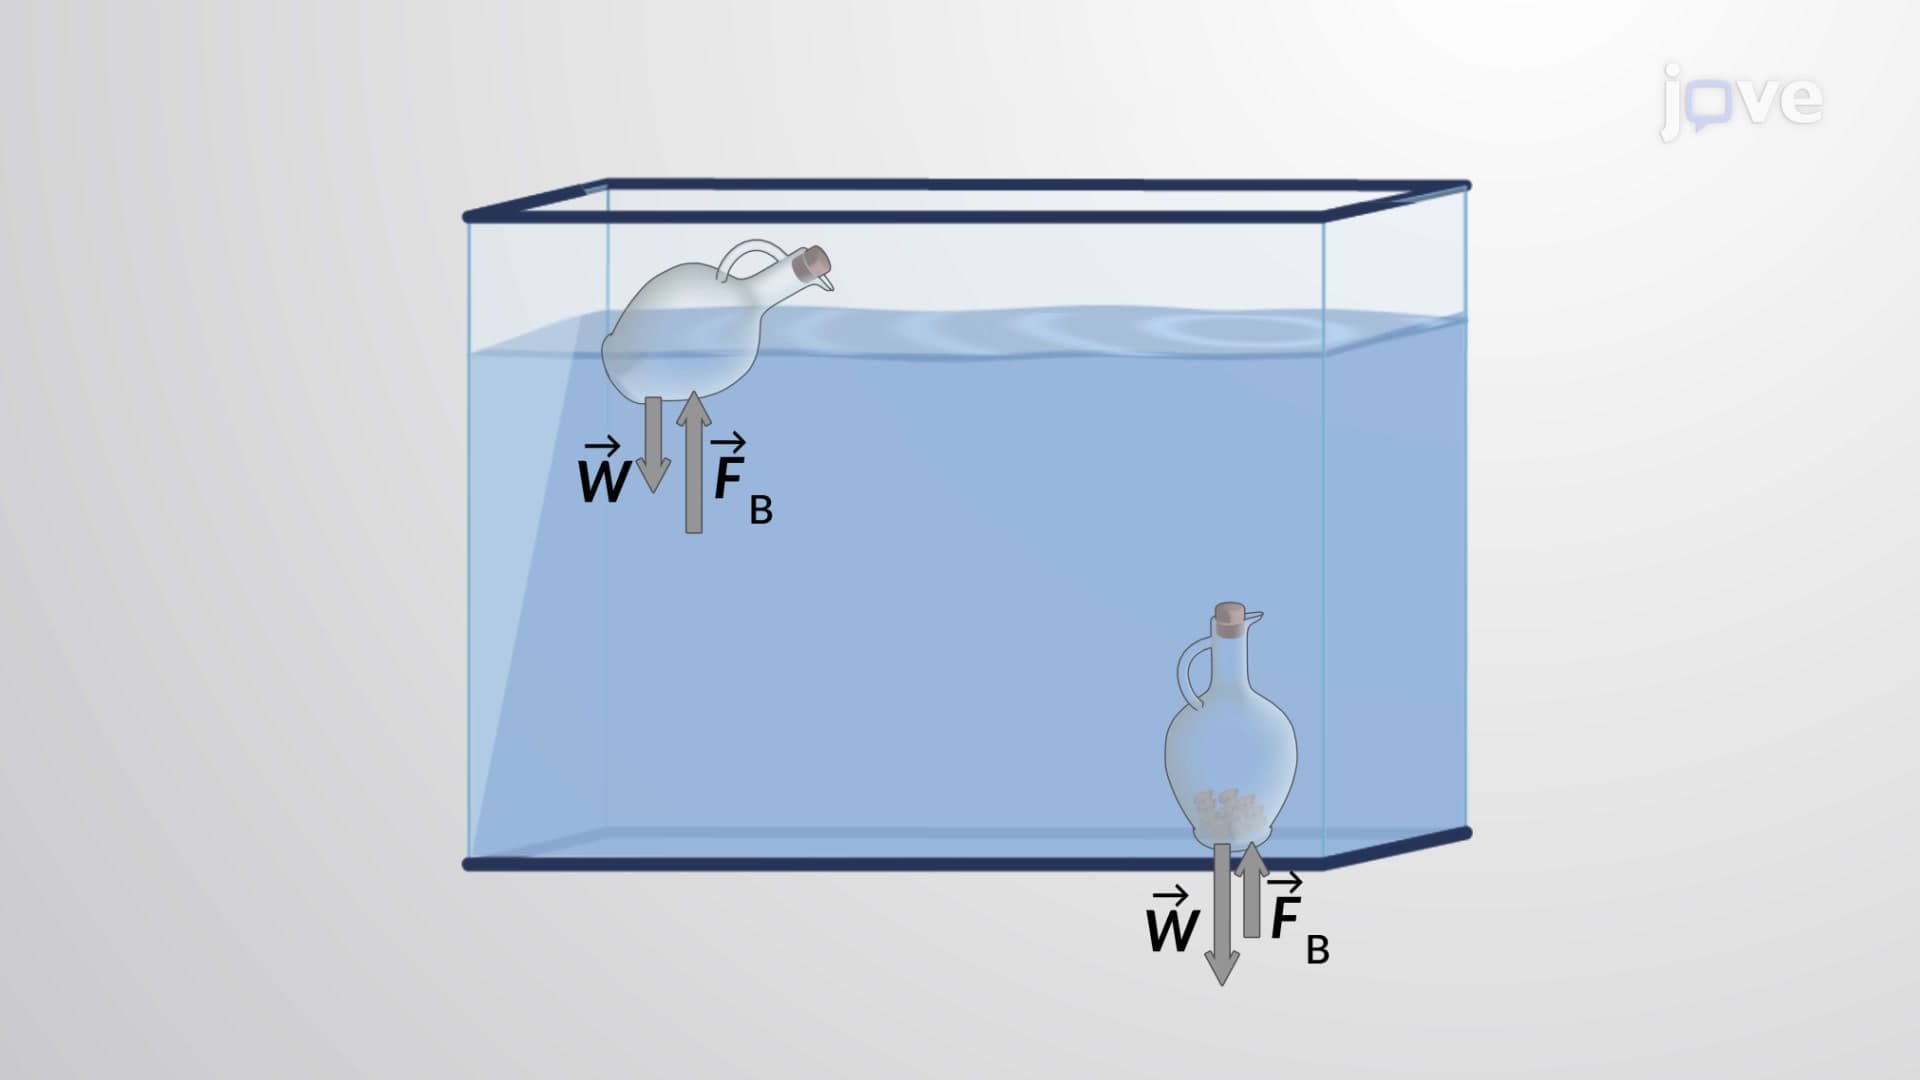
Buoyancy and Stability for Submerged and Floating Bodies
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
 01:27
Uniform Depth Channel Flow
 01:13
Principle of Virtual Work: Problem Solving
To apply the principle of virtual work,...
 00:59
Buoyancy