Related Experiment Video
Updated: Aug 17, 2025
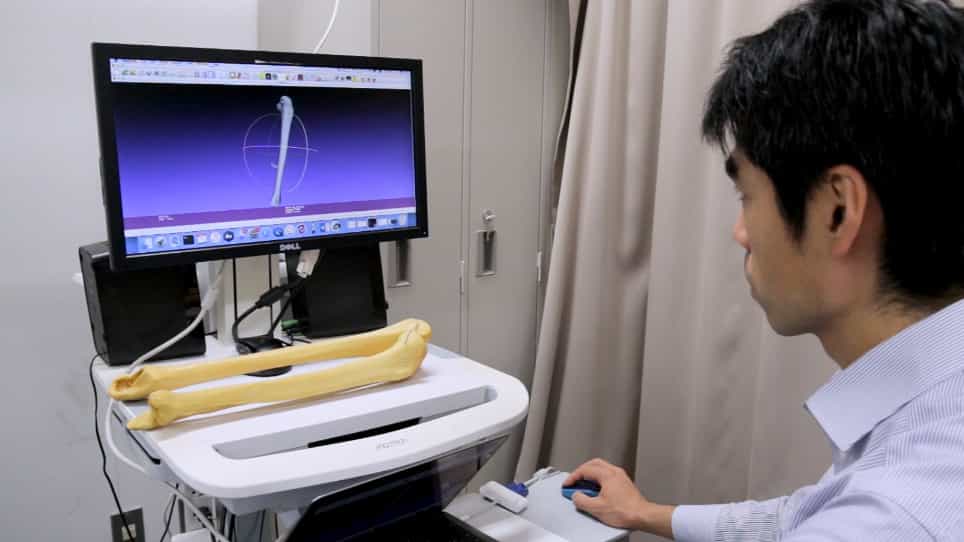

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Kinematic analysis of forearm rotation using four-dimensional computed tomography
Joris G M Oonk1,2, Johannes G G Dobbe1,2, Gustav J Strijkers1
1Amsterdam UMC location University of Amsterdam, Biomedical Engineering and Physics, Amsterdam, The Netherlands.

Abstract:
This study aimed to quantify forearm kinematics with a focus on the forearm rotation axis. Ten healthy volunteers were included in the study. One three-dimensional computed tomographic scan and two four-dimensional computed tomographic scans were done in all the arms to capture forearm joint motion. After image processing, the rotation axis and the movement of the radius with respect to various axes were quantified. The rotation axis was calculated using finite helical axis analysis and a circle fitting approach. The mean error of the rotation axis found through circle fitting was 0.2 mm (SD 0.1) distally and 0.1 mm (SD 0.1) proximally, indicating an improvement in precision over the finite helical axis approach. The translations of the radius along the ulnar axis and the forearm rotation axis were 2.6 (SD 0.8) and 0.6 mm (SD 0.9), respectively. The rotation of the radius around the radial axis was 7.2°. The techniques presented provide a detailed description of forearm kinematics.
Related Concept Videos
 01:10
Computed Tomography
The technique was invented in the 1970s and is based on the principle that as X-rays pass through the body, they are absorbed or reflected at different levels. In the technique, a patient lies on a motorized platform while a computerized axial tomography (CAT) scanner rotates...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:19
Bones of the Upper Limb: Humerus
 01:27
Imaging Studies III: Computed Tomography
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...