Related Experiment Video
Updated: Aug 17, 2025


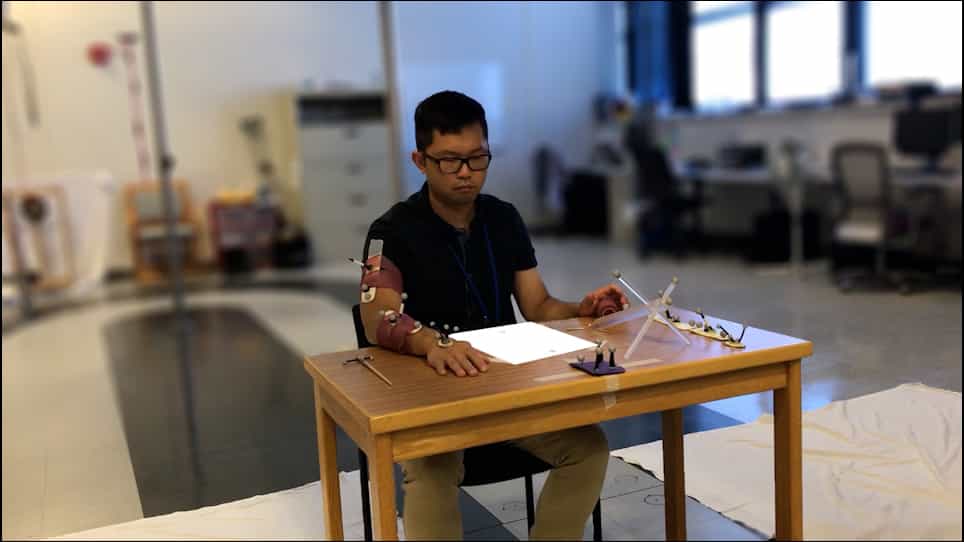
Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Identification of inverse kinematic parameters in redundant systems: Towards quantification of inter-joint
Mahdi Khoramshahi1, Agnes Roby-Brami1, Ross Parry2
1Sorbonne Université, CNRS, INSERM, Institute for Intelligent Systems and Robotics (ISIR), Paris, France.

Abstract:
Understanding and quantifying inter-joint coordination is valuable in several domains such as neurorehabilitation, robot-assisted therapy, robotic prosthetic arms, and control of supernumerary arms. Inter-joint coordination is often understood as a consistent spatiotemporal relation among kinematically redundant joints performing functional and goal-oriented movements. However, most approaches in the literature to investigate inter-joint coordination are limited to analysis of the end-point trajectory or correlation analysis of the joint rotations without considering the underlying task; e.g., creating a desirable hand movement toward a goal as in reaching motions. This work goes beyond this limitation by taking a model-based approach to quantifying inter-joint coordination. More specifically, we use the weighted pseudo-inverse of the Jacobian matrix and its associated null-space to explain the human kinematics in reaching tasks. We propose a novel algorithm to estimate such Inverse Kinematics weights from observed kinematic data. These estimated weights serve as a quantification for spatial inter-joint coordination; i.e., how costly a redundant joint is in its contribution to creating an end-effector velocity. We apply our estimation algorithm to datasets obtained from two different experiments. In the first experiment, the estimated Inverse Kinematics weights pinpoint how individuals change their Inverse Kinematics strategy when exposed to the viscous field wearing an exoskeleton. The second experiment shows how the resulting Inverse Kinematics weights can quantify a robotic prosthetic arm's contribution (or the level of assistance).
More Related Videos

Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Method of Joints: Problem Solving II