Related Experiment Video
Updated: Aug 15, 2025

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Complex Three-Dimensional Terrains Traversal of Insect-Scale Soft Robot
Ying Liu1, Jiaming Liang2, Jiangfeng Lu1
1Tsinghua-Berkeley Shenzhen Institute, Tsinghua University, Shenzhen, China.

Abstract:
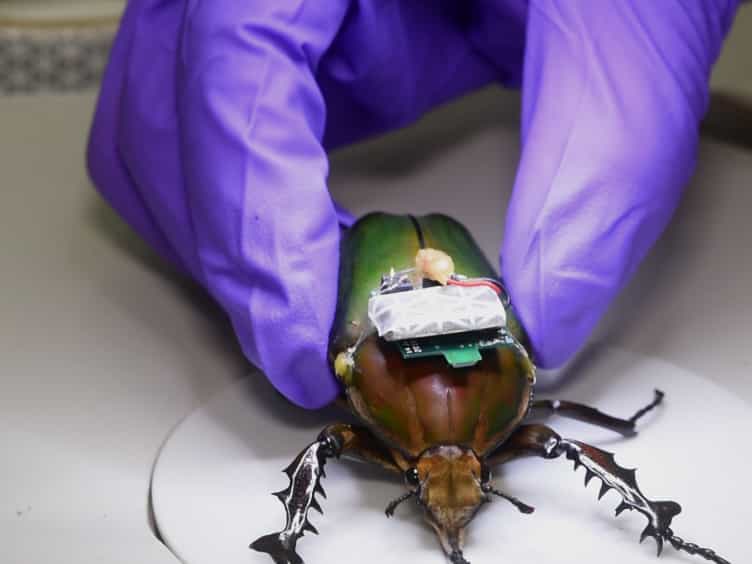
This article proposes a piezoelectric-driven insect-scale soft robot with ring-like curved legs, enabling it to traverse complex three-dimensional (3D) terrain only by body-terrain mechanical action. Relying on the repeated deformation of the main body's n and u shapes, the robot's leg-ground mechanical action produces an "elastic gait" to move. Regarding the detailed design, first, a theoretical curve of the front leg with a fixed angle of attack of 75° is designed by finite element simulation and comparative experiments. It ensures no increase in drag and no decrease in the lift when climbing steps. Second, a ring-like leg structure with 100% closed degree is proposed to ensure a smooth pass through small-sized uneven terrain without getting stuck. Then, the design of the overall asymmetrical structure of the robot can improve the conversion ratio of vibration to forward force. The shape of curved legs is controlled by pulling the flexible leg structure with two metal wires working as spokes. The semirigid leg structure made of fully flexible materials has shape stability and structural robustness. Compared with the plane-legged robot, the curved-legged robot can smoothly traverse different rugged 3D terrains and cross the terrain covering obstacles 0.36 times body height (BH) at a speed of >4 body lengths per second. Moreover, the curved-legged robot shows 100% and 64% chances of climbing steps with 1.2- and 1.9-times BH, respectively.
More Related Videos

Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System
 01:03
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...
 01:16
Hydraulic Jump: Problem Solving