Related Experiment Video
Updated: Aug 15, 2025


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design, modeling, and testing of a one degree of freedom manipulator with three-stage amplification mechanism
Z Y Guo1, W C Zhang2, Y L Tian3
1College of Aeronautical Engineering, Civil Aviation University of China, Tianjin 300300, China.

Abstract:
The one degree of freedom (1-DOF) manipulator with nano-resolution is a significant component in the micro-/nano-manipulation. In order to simultaneously achieve a large stroke and high precision, a piezo-driven 1-DOF flexure-based manipulator consisting of an enhanced double Scott-Russell mechanism (EDSRM), a lever type mechanism, and a Z-shaped mechanism is proposed in this paper. Analytical models are developed to examine the kinetostatic and dynamic properties of the manipulator. A finite element analysis is further performed to evaluate the characteristics of the EDSRM and the complete manipulator. The prototype is fabricated on monolithic AL7075, and various experimental tests have been carried out to investigate the correctness of the modeling. The experimental results show that the proposed manipulator has a satisfactory amplification ratio, static stability, and dynamic performance.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Machines: Problem Solving II
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
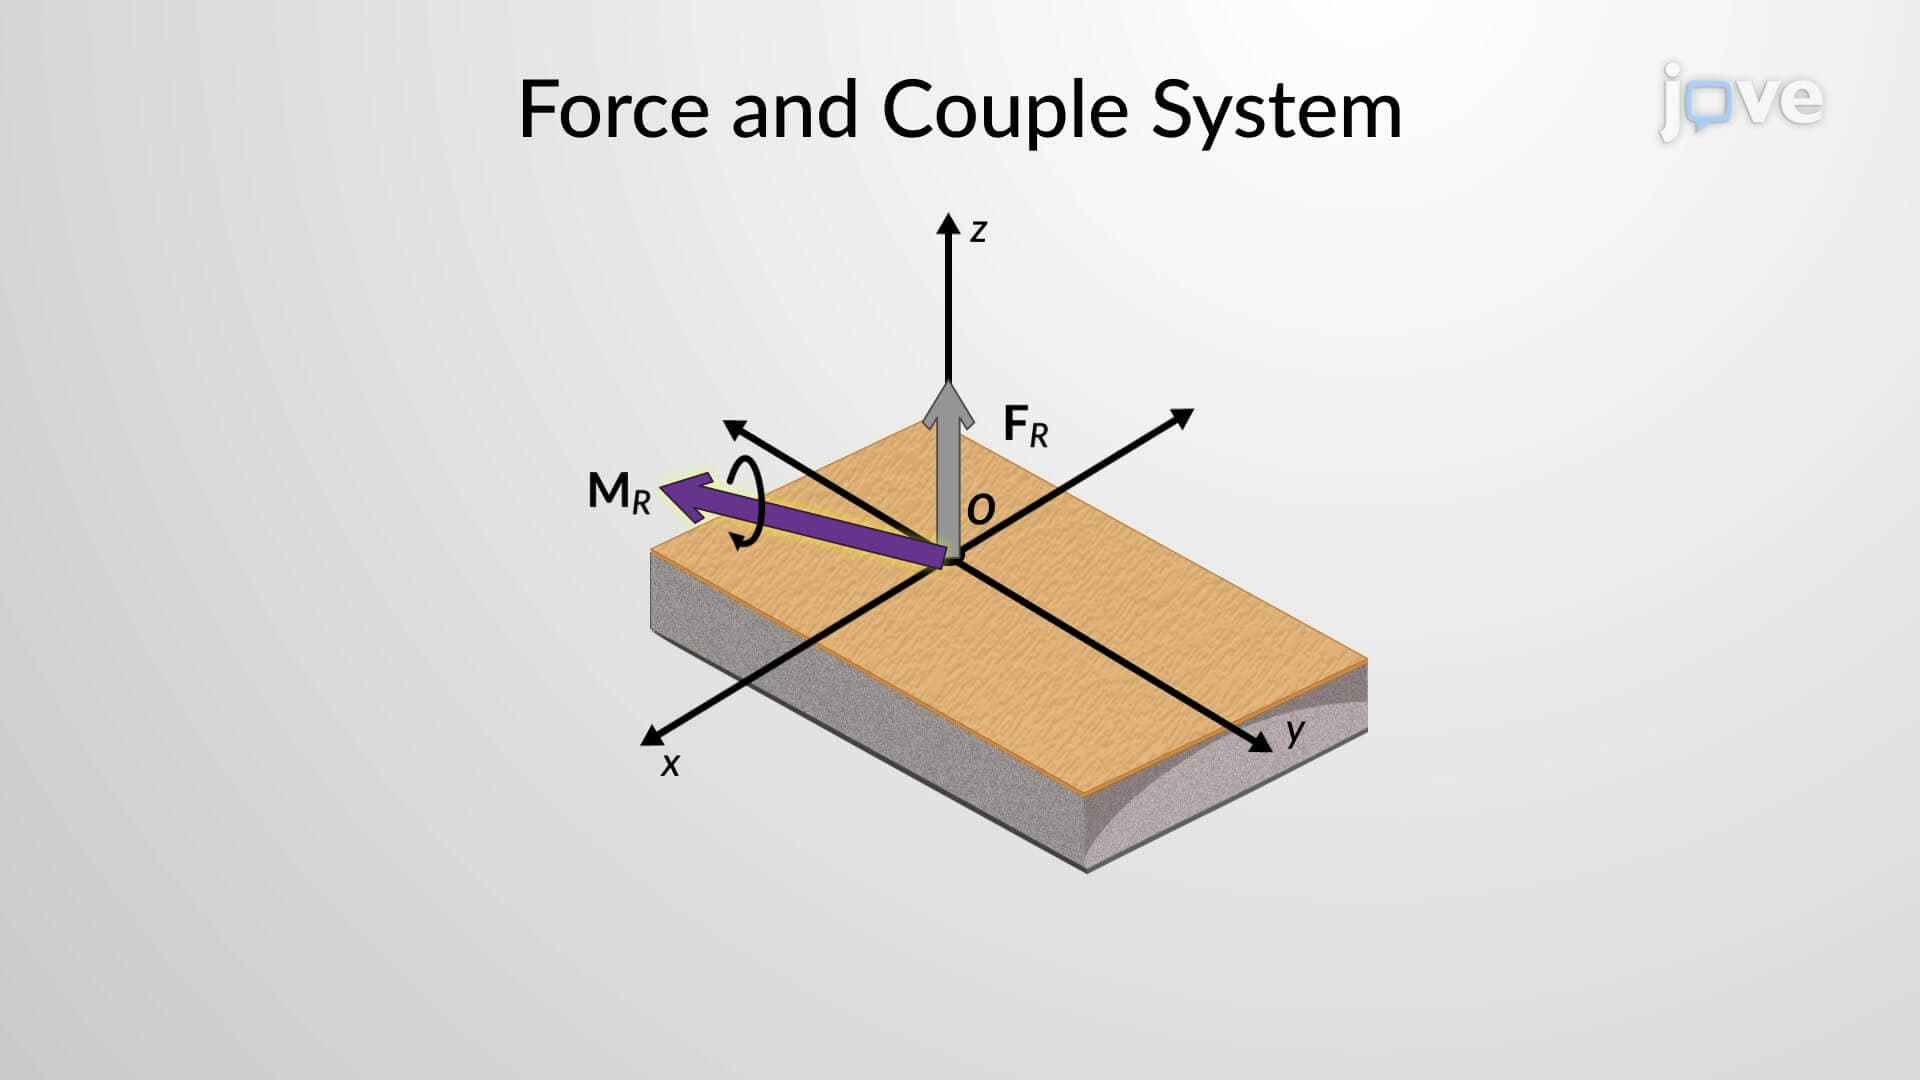 01:23
Simplification of a Force and Couple System: II
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...