Related Experiment Video
Updated: Aug 15, 2025

Mouse Epidermal Neural Crest Stem Cell EPI-NCSC Cultures
Published on: May 9, 2008
On the intrinsic curvature of animal whiskers
Yifu Luo1, Mitra J Z Hartmann1,2
1Department of Mechanical Engineering, Northwestern University, Evanston, Illinois, United States of America.

Abstract:
Facial vibrissae (whiskers) are thin, tapered, flexible, hair-like structures that are an important source of tactile sensory information for many species of mammals. In contrast to insect antennae, whiskers have no sensors along their lengths. Instead, when a whisker touches an object, the resulting deformation is transmitted to mechanoreceptors in a follicle at the whisker base. Previous work has shown that the mechanical signals transmitted along the whisker will depend strongly on the whisker's geometric parameters, specifically on its taper (how diameter varies with arc length) and on the way in which the whisker curves, often called "intrinsic curvature." Although previous studies have largely agreed on how to define taper, multiple methods have been used to quantify intrinsic curvature. The present work compares and contrasts different mathematical approaches towards quantifying this important parameter. We begin by reviewing and clarifying the definition of "intrinsic curvature," and then show results of fitting whisker shapes with several different functions, including polynomial, fractional exponent, elliptical, and Cesàro. Comparisons are performed across ten species of whiskered animals, ranging from rodents to pinnipeds. We conclude with a discussion of the advantages and disadvantages of using the various models for different modeling situations. The fractional exponent model offers an approach towards developing a species-specific parameter to characterize whisker shapes within a species. Constructing models of how the whisker curves is important for the creation of mechanical models of tactile sensory acquisition behaviors, for studies of comparative evolution, morphology, and anatomy, and for designing artificial systems that can begin to emulate the whisker-based tactile sensing of animals.
More Related Videos
Related Concept Videos
 01:16
Accessory Structures of the Skin: Hair and Hair Follicles
Hair is a keratinous filament growing out of the epidermis. It is primarily made of dead, keratinized cells. Hair strands originate at the epidermal penetration called the hair follicle. The hair shaft is the part...
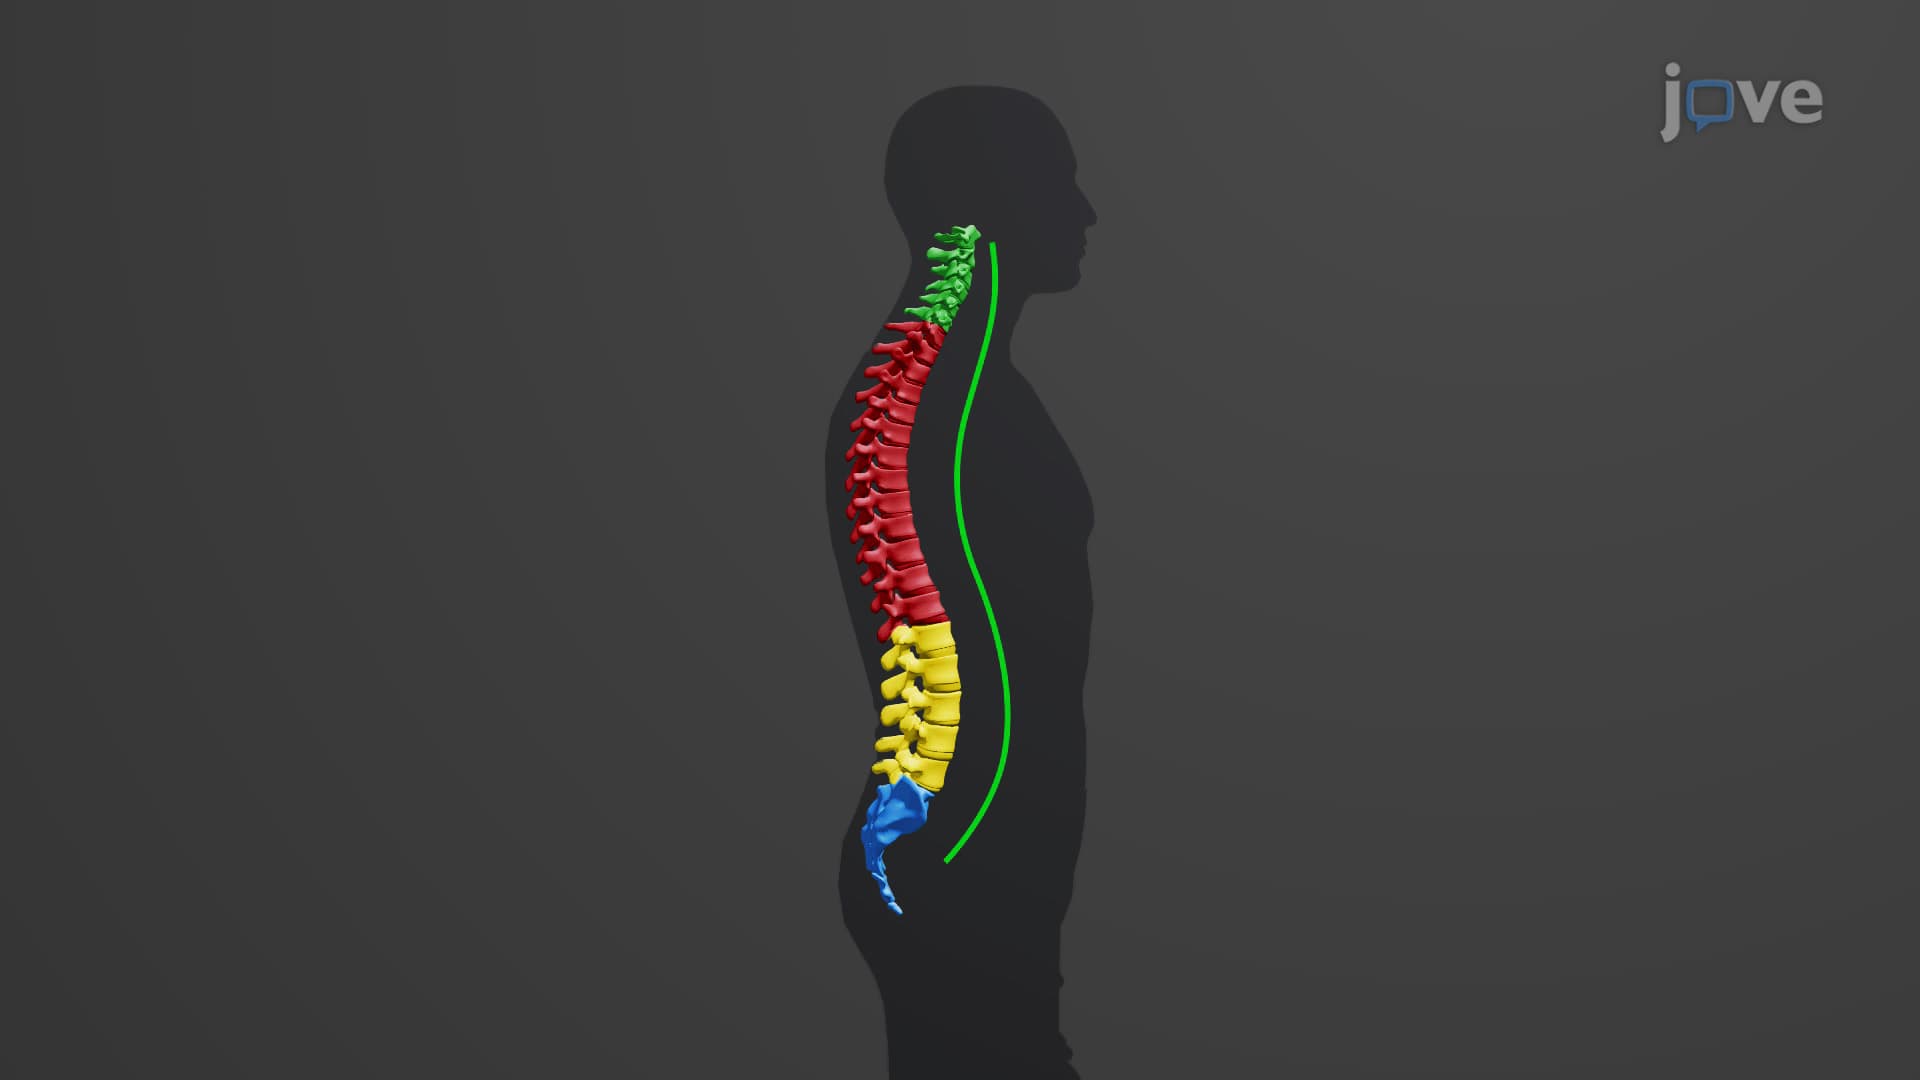 01:16
Vertebral Column: Regions and Curvature
Regions of the Vertebral Column
In an adult, the spine is subdivided into five regions: the cervical, the thoracic, the lumbar, the sacral, and the coccygeal region. The spine initially develops as a series of 33 vertebrae; after 20 years of age, the nine bones in the sacral region, five sacral, and four coccygeal bones fuse to form...
 01:14
Bending of Curved Members - Strain Analysis
The important part of bending analysis for such a member...
 01:21
Tooth Anatomy
The Crown, Neck, and Root
The visible part of the tooth is referred to as the crown. It's covered by enamel, the hardest substance in the human body. The crown is uniquely shaped for each type of tooth, allowing for different functions such as cutting, tearing, or...
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...