Related Experiment Video
Updated: Aug 14, 2025


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Self-vectoring electromagnetic soft robots with high operational dimensionality
Wenbo Li1,2, Huyue Chen3, Zhiran Yi4
1State Key Laboratory of Mechanical System and Vibration, School of Mechanical Engineering, Shanghai Jiao Tong University, Shanghai, 200240, China. wenboli@tongji.edu.cn.

Abstract:
Soft robots capable of flexible deformations and agile locomotion similar to biological systems are highly desirable for promising applications, including safe human-robot interactions and biomedical engineering. Their achievable degree of freedom and motional deftness are limited by the actuation modes and controllable dimensions of constituent soft actuators. Here, we report self-vectoring electromagnetic soft robots (SESRs) to offer new operational dimensionality via actively and instantly adjusting and synthesizing the interior electromagnetic vectors (EVs) in every flux actuator sub-domain of the robots. As a result, we can achieve high-dimensional operation with fewer actuators and control signals than other actuation methods. We also demonstrate complex and rapid 3D shape morphing, bioinspired multimodal locomotion, as well as fast switches among different locomotion modes all in passive magnetic fields. The intrinsic fast (re)programmability of SESRs, along with the active and selective actuation through self-vectoring control, significantly increases the operational dimensionality and possibilities for soft robots.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:15
Magnetic Vector Potential
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
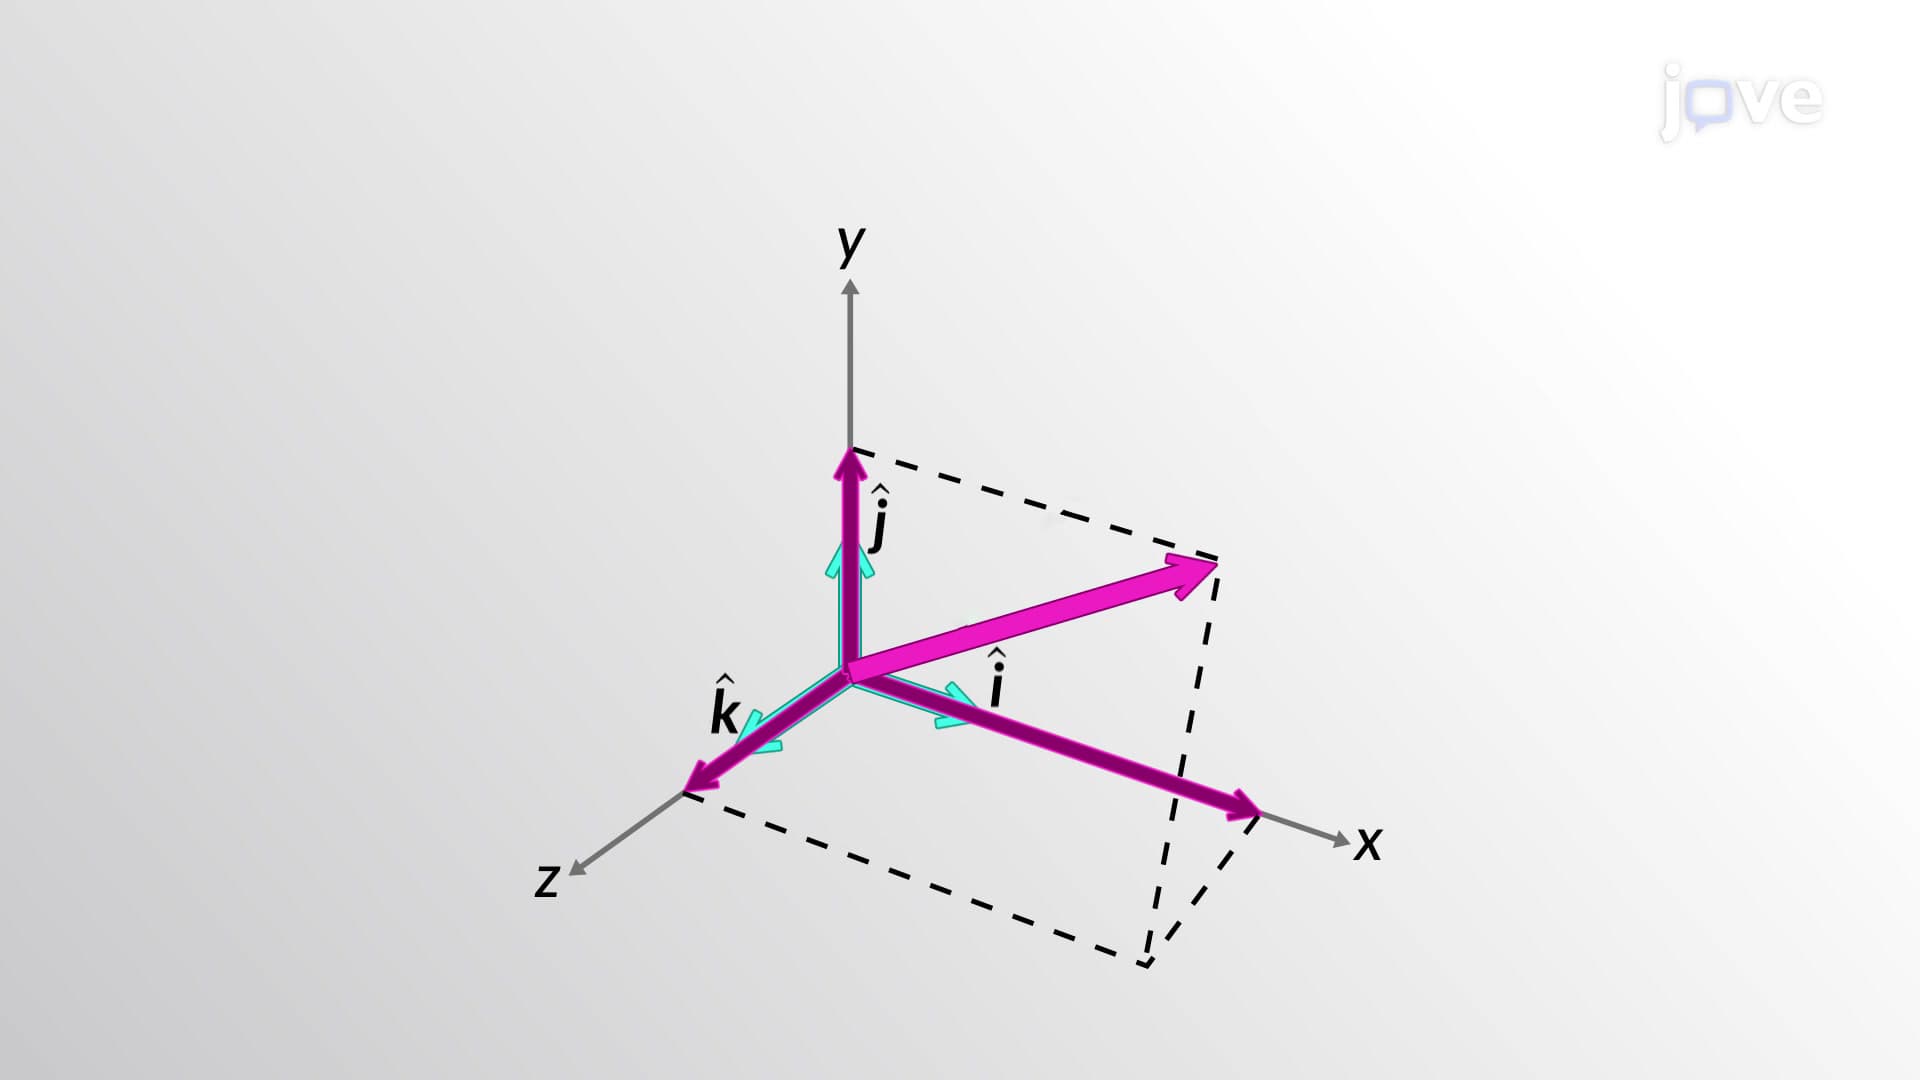 01:29
Vector Components in the Cartesian Coordinate System
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...