Related Experiment Video
Updated: Aug 14, 2025
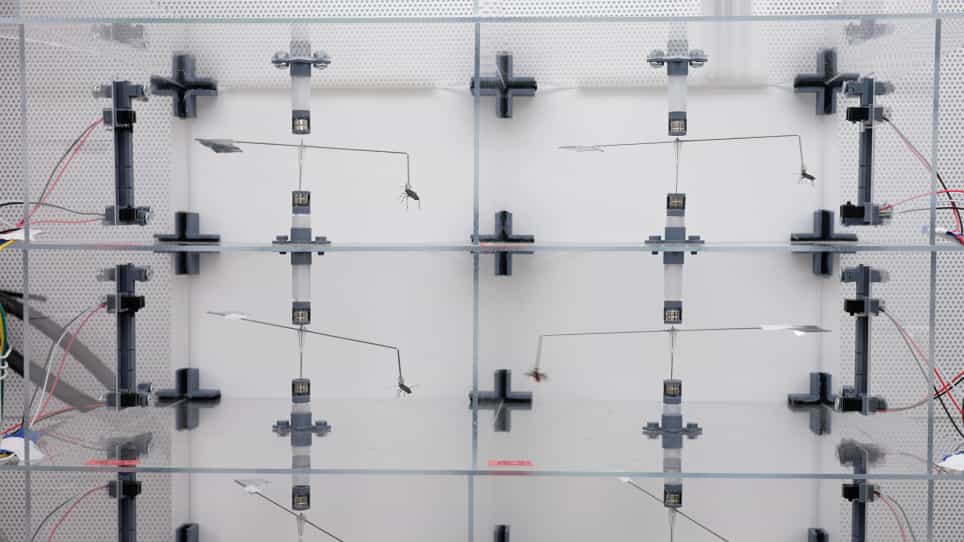

Building an Enhanced Flight Mill for the Study of Tethered Insect Flight
Published on: March 10, 2021
Platform Design and Preliminary Test Result of an Insect-like Flapping MAV with Direct Motor-Driven Resonant Wings
Seung-Hee Jeong1, Jeong-Hwan Kim2, Seung-Ik Choi2
1Department of Aerospace Information Engineering, Konkuk University, Seoul 05029, Republic of Korea.

Abstract:
In this paper, we propose a platform for an insect-like flapping winged micro aerial vehicle with a resonant wing-driving system using extension springs (FMAVRES). The resonant wing-driving system is constructed using an extension spring instead of the conventional helical or torsion spring. The extension spring can be mounted more easily, compared with a torsion spring. Furthermore, the proposed resonant driving system has better endurance compared with systems with torsion springs. Using a prototype FMAVRES, it was found that torques generated for roll, pitch, and yaw control are linear to control input signals. Considering transient responses, each torque response as an actuator is modelled as a simple first-order system. Roll, pitch, and yaw control commands affect each other. They should be compensated in a closed loop controller design. Total weight of the prototype FMAVRES is 17.92 g while the lift force of it is 21.3 gf with 80% throttle input. Thus, it is expected that the new platform of FMAVRES could be used effectively to develop simple and robust flapping MAVs.
Related Concept Videos
 01:22
Mechanical Systems
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:05
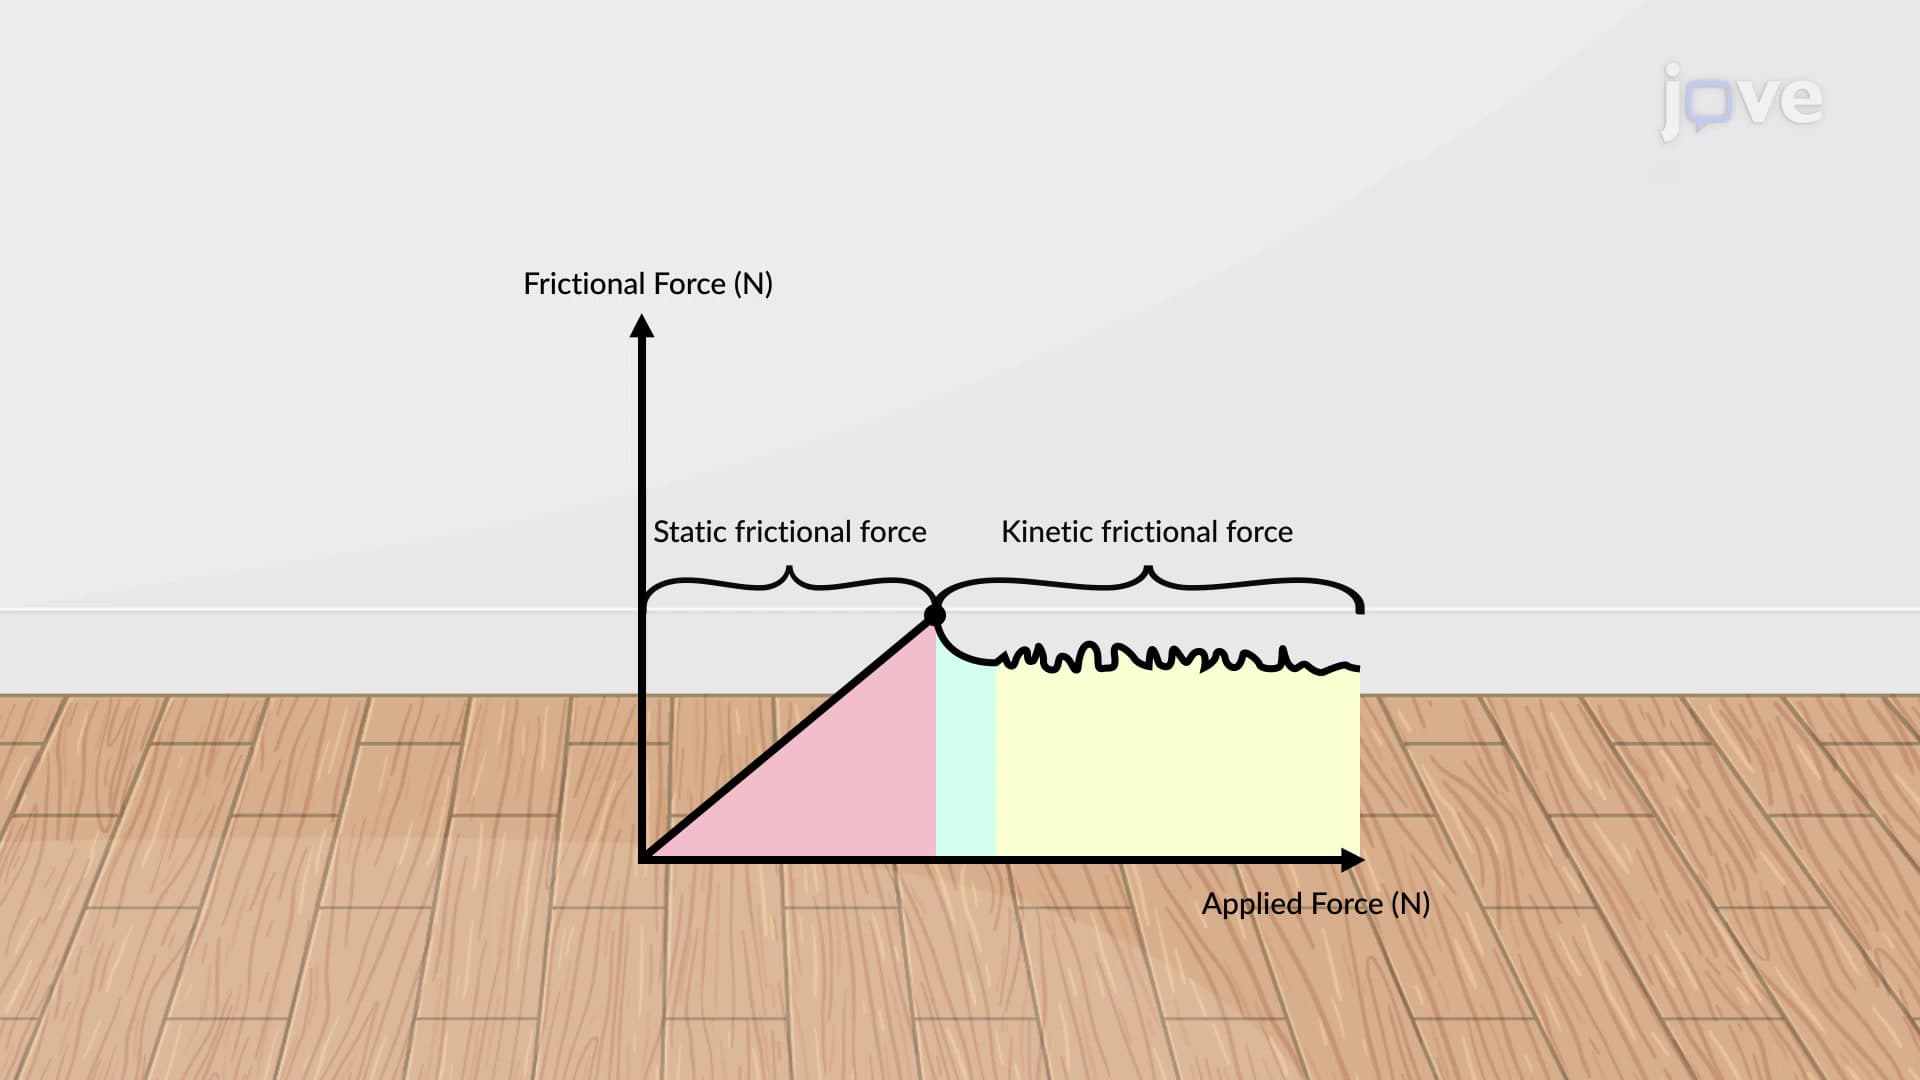
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...