Related Experiment Video
Updated: Aug 13, 2025

Swin-PSAxialNet: An Efficient Multi-Organ Segmentation Technique
Published on: July 5, 2024
Co-Training for Unsupervised Domain Adaptation of Semantic Segmentation Models
Jose L Gómez1,2, Gabriel Villalonga1, Antonio M López1,2
1Computer Vision Center (CVC), Universitat Autònoma de Barcelona (UAB), 08193 Bellaterra, Spain.

Abstract:
Semantic image segmentation is a core task for autonomous driving, which is performed by deep models. Since training these models draws to a curse of human-based image labeling, the use of synthetic images with automatically generated labels together with unlabeled real-world images is a promising alternative. This implies addressing an unsupervised domain adaptation (UDA) problem. In this paper, we propose a new co-training procedure for synth-to-real UDA of semantic segmentation models. It performs iterations where the (unlabeled) real-world training images are labeled by intermediate deep models trained with both the (labeled) synthetic images and the real-world ones labeled in previous iterations. More specifically, a self-training stage provides two domain-adapted models and a model collaboration loop allows the mutual improvement of these two models. The final semantic segmentation labels (pseudo-labels) for the real-world images are provided by these two models. The overall procedure treats the deep models as black boxes and drives their collaboration at the level of pseudo-labeled target images, i.e., neither modifying loss functions is required, nor explicit feature alignment. We test our proposal on standard synthetic and real-world datasets for onboard semantic segmentation. Our procedure shows improvements ranging from approximately 13 to 31 mIoU points over baselines.
More Related Videos

Related Concept Videos
 02:07
Improving Translational Accuracy
 01:19
Survival Tree
Building a Survival Tree
Constructing a...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:12
Observational Learning
 01:20
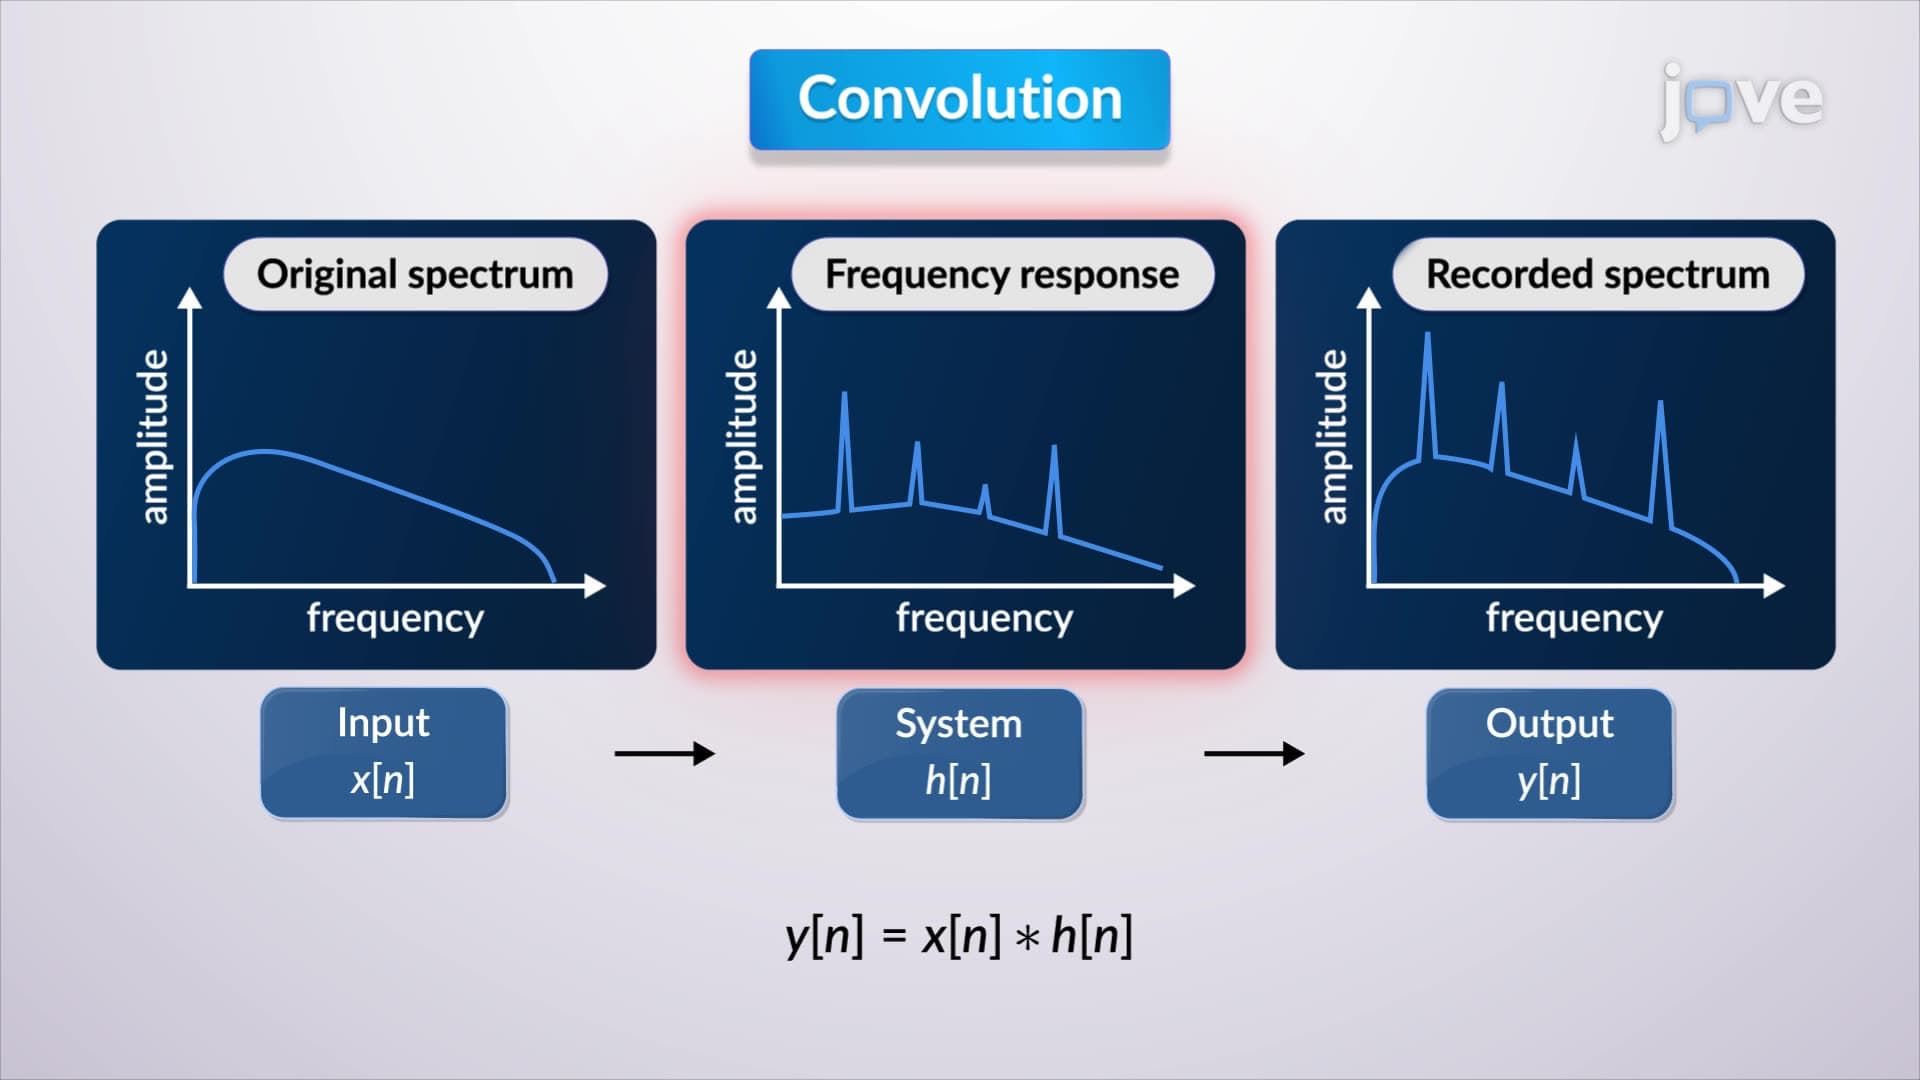
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...