Related Experiment Video
Updated: Aug 12, 2025


Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Machine learning enabled orthogonal camera goniometry for accurate and robust contact angle measurements
1Department of Civil and Environmental Engineering, University of Illinois at Urbana-Champaign, Urbana, IL, USA.

Abstract:
Characterization of surface wettability plays an integral role in physical, chemical, and biological processes. However, the conventional fitting algorithms are not suitable for accurate estimation of wetting properties, especially on hydrophilic surfaces, due to optical distortions triggered by changes in the focal length of the moving drops. Therefore, here we present an original setup coupled with Convolutional Neural Networks (CNN) for estimation of Contact Angle (CA). The developed algorithm is trained on 3375 ground truth images (at different front-lit illuminations), less sensitive to the edges of the drops, and retains its stability for images that are synthetically blurred with higher Gaussian Blurring (GB) values (GB: 0-22) if compared to existing goniometers (GB: 0-12). Besides, the proposed technique can precisely analyze drops of various colors and chemistries on different surfaces. Finally, our automated orthogonal camera goniometer has a significantly lower average standard deviation (6.7° vs. 14.6°) and coefficient of variation (14.9 vs. 29.2%) than the existing techniques and enables wettability assessment of non-spherical drops on heterogeneous surfaces.
Related Concept Videos
 01:13
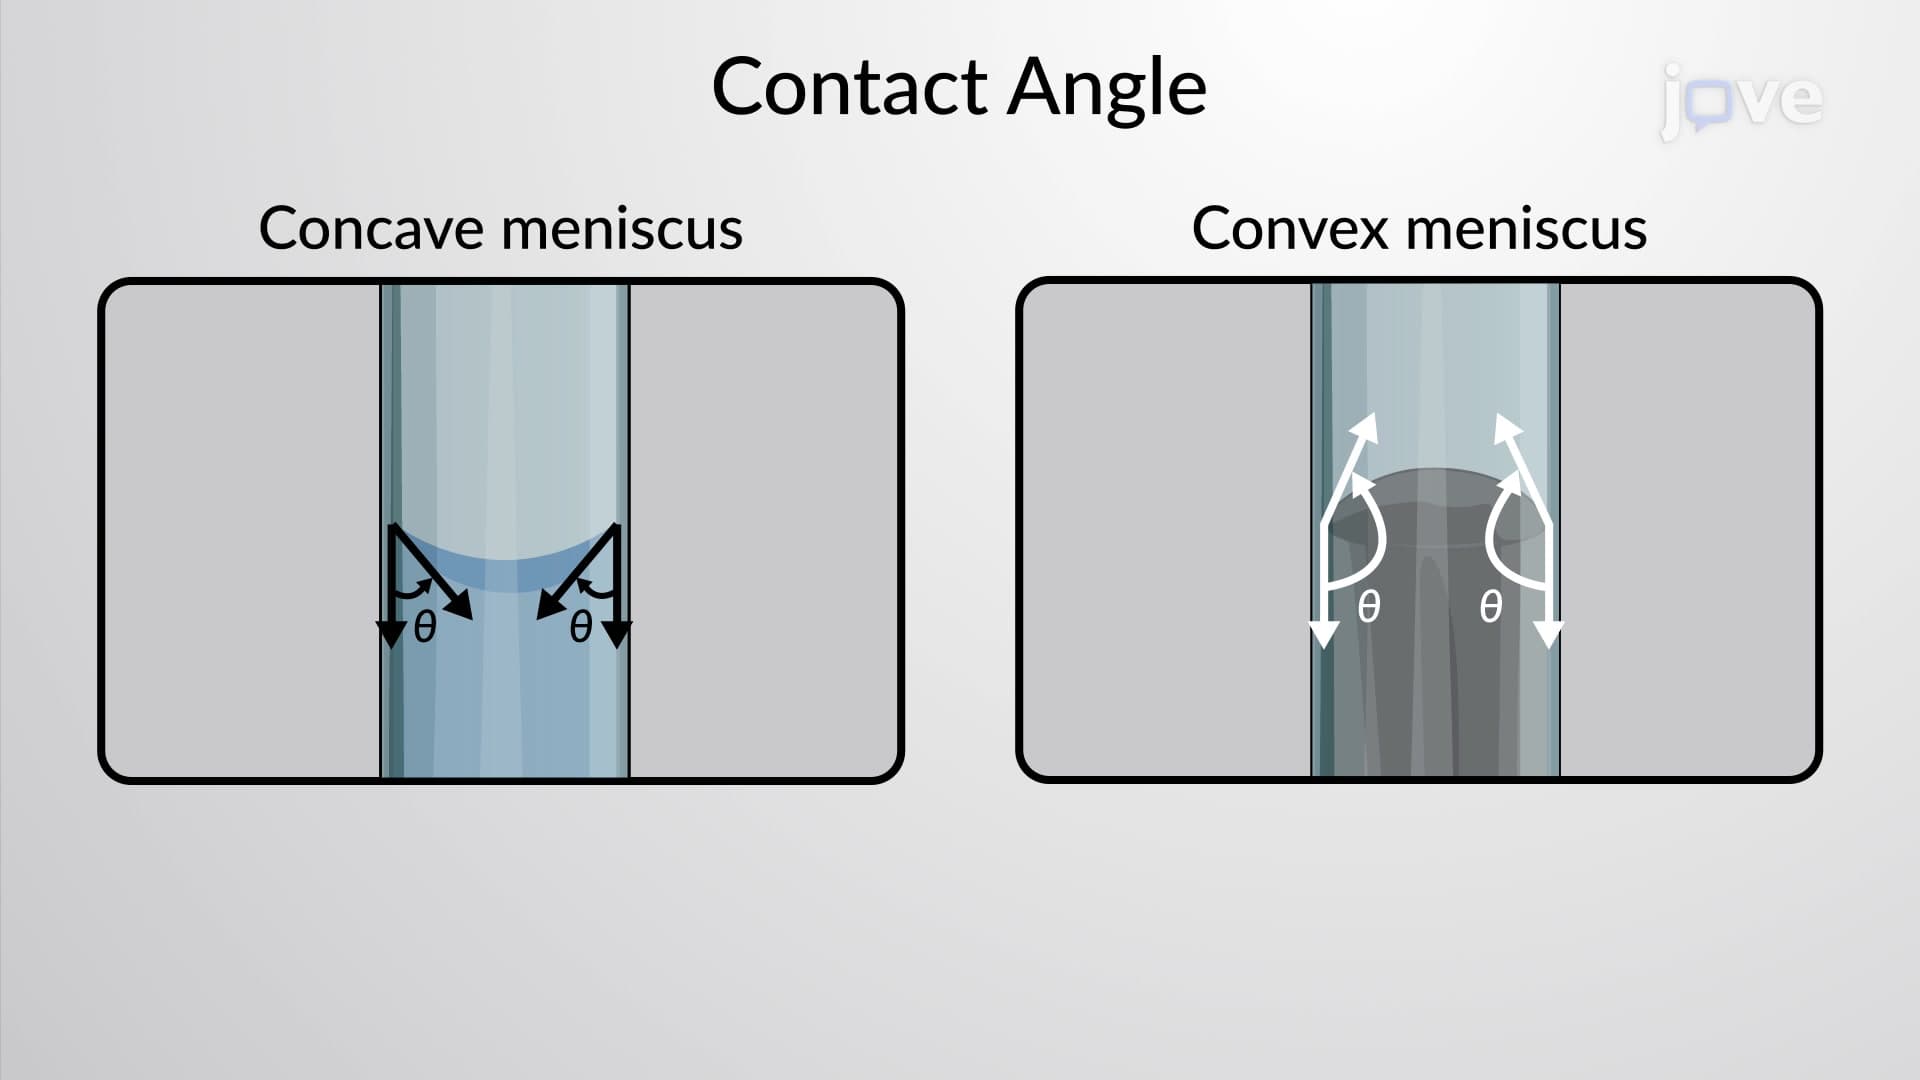
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...
 01:15
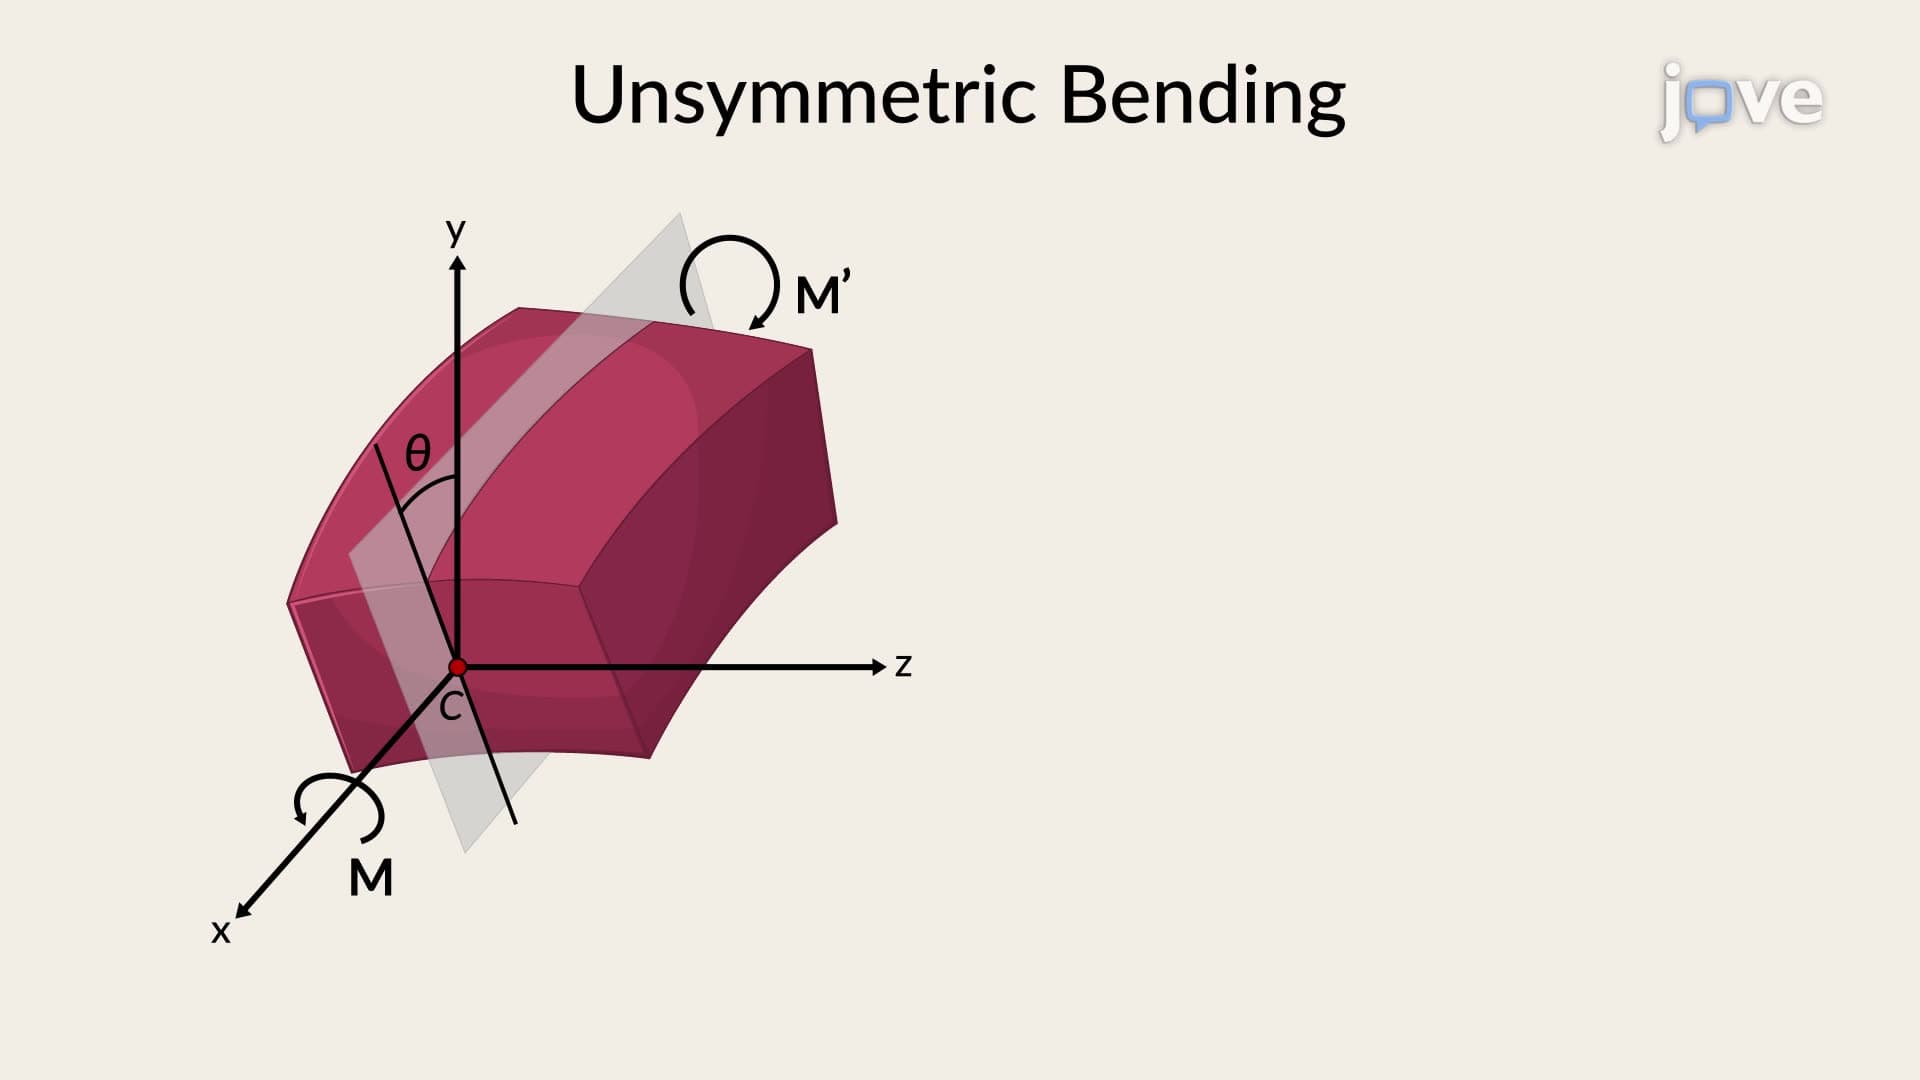
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...