Related Experiment Video
Updated: Aug 11, 2025
Application of Deep Learning-Based Medical Image Segmentation via Orbital Computed Tomography
Published on: November 30, 2022
Keyframe image processing of semantic 3D point clouds based on deep learning
Junxian Wang1, Wei Lv1, Zhouya Wang1
1Alibaba Cloud Big Data Application College, Zhuhai College of Science and Technology, Zhuhai, China.

Abstract:
With the rapid development of web technologies and the popularity of smartphones, users are uploading and sharing a large number of images every day. Therefore, it is a very important issue nowadays to enable users to discover exactly the information they need in the vast amount of data and to make it possible to integrate their large amount of image material efficiently. However, traditional content-based image retrieval techniques are based on images, and there is a "semantic gap" between this and people's understanding of images. To address this "semantic gap," a keyframe image processing method for 3D point clouds is proposed, and based on this, a U-Net-based binary data stream semantic segmentation network is established for keyframe image processing of 3D point clouds in combination with deep learning techniques.
More Related Videos
 11:34
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
 08:25
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:20
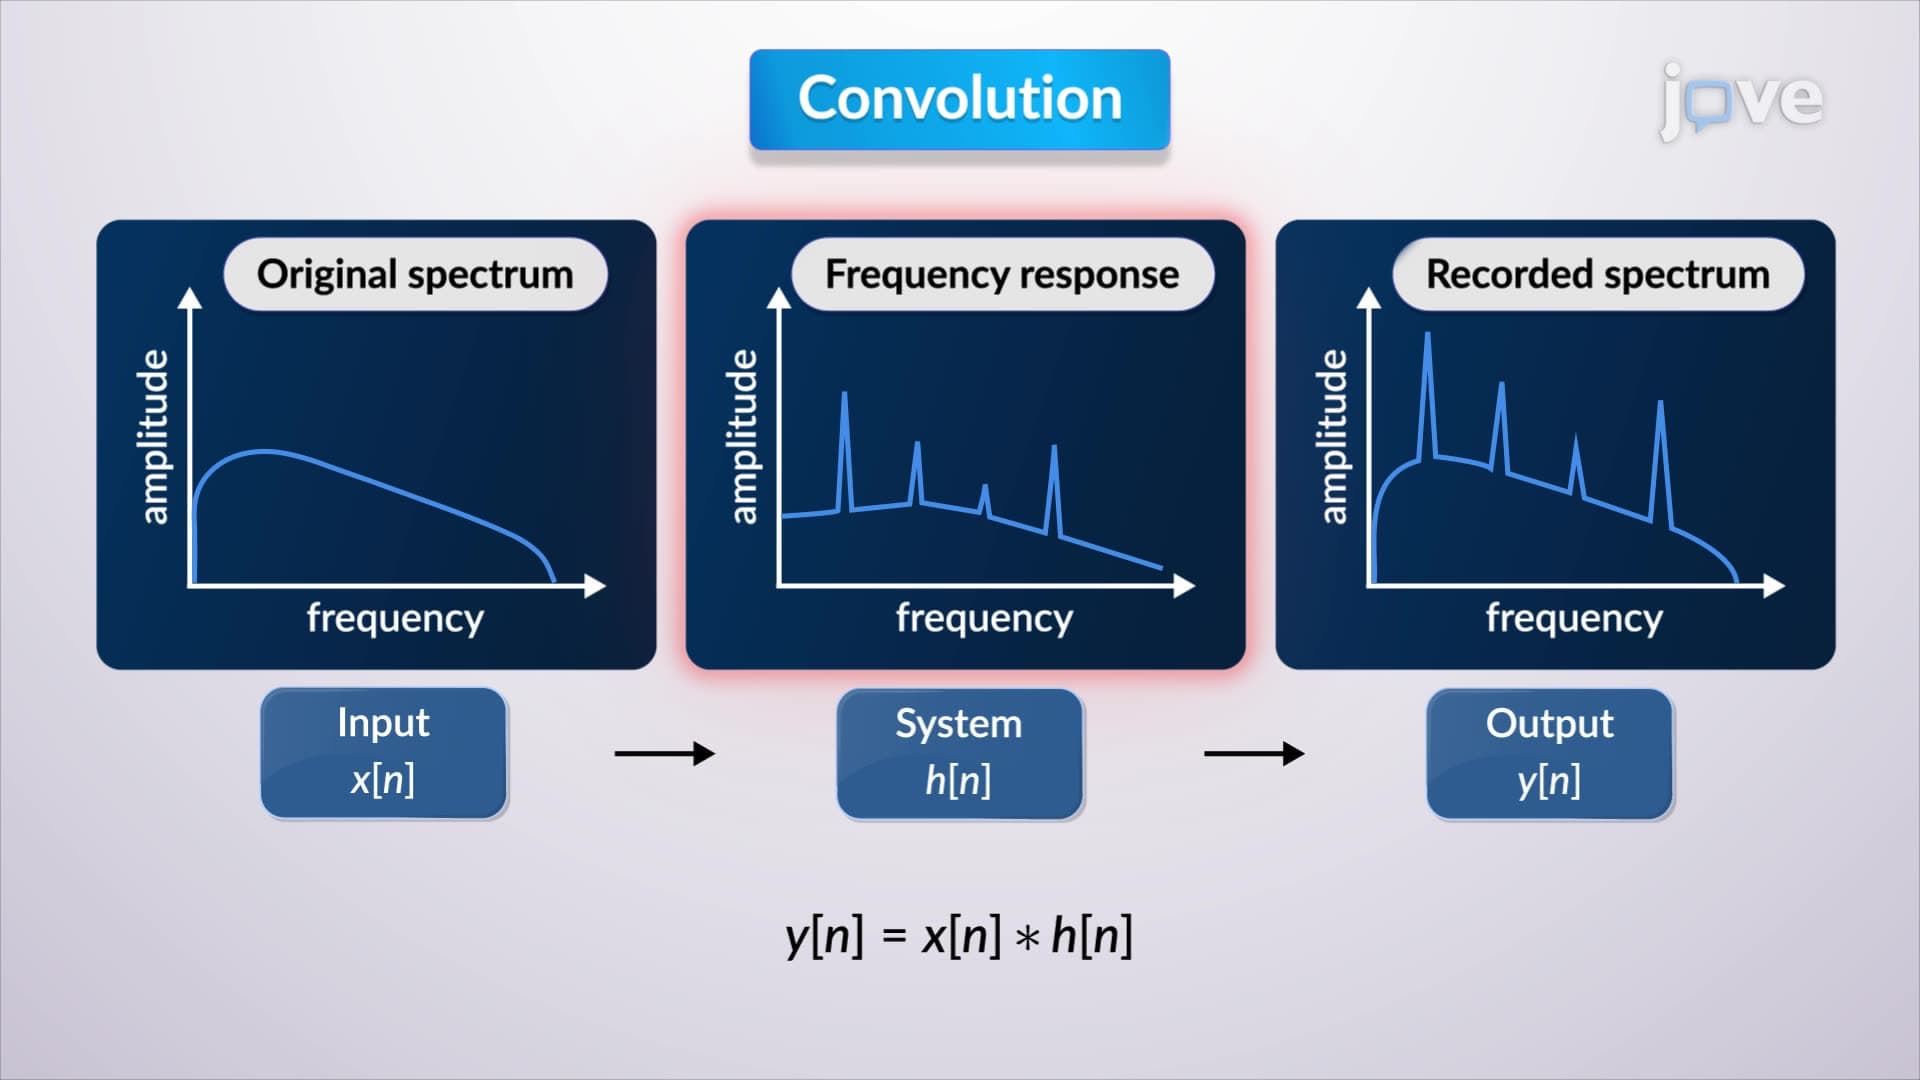
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...