Multimodal bipedal locomotion generation with passive dynamics via deep reinforcement learning
Related Experiment Video
Updated: Aug 11, 2025
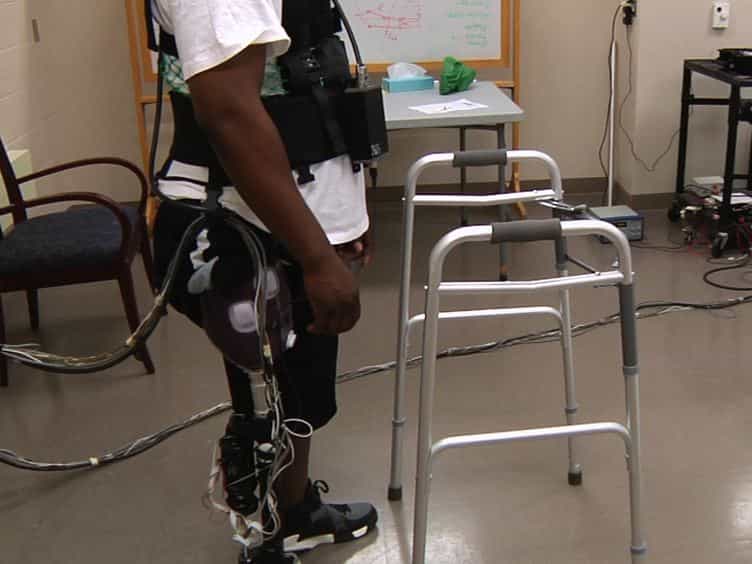
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Shunsuke Koseki1, Kyo Kutsuzawa1, Dai Owaki1
1Neuro-Robotics Lab, Department of Robotics, Graduate School of Engineering, Tohoku University, Sendai, Japan.

Abstract:
Generating multimodal locomotion in underactuated bipedal robots requires control solutions that can facilitate motion patterns for drastically different dynamical modes, which is an extremely challenging problem in locomotion-learning tasks. Also, in such multimodal locomotion, utilizing body morphology is important because it leads to energy-efficient locomotion. This study provides a framework that reproduces multimodal bipedal locomotion using passive dynamics through deep reinforcement learning (DRL). An underactuated bipedal model was developed based on a passive walker, and a controller was designed using DRL. By carefully planning the weight parameter settings of the DRL reward function during the learning process based on a curriculum learning method, the bipedal model successfully learned to walk, run, and perform gait transitions by adjusting only one command input. These results indicate that DRL can be applied to generate various gaits with the effective use of passive dynamics.