Related Experiment Video
Updated: Aug 10, 2025

Experimental Methods for Investigation of Shape Memory Based Elastocaloric Cooling Processes and Model Validation
Published on: May 2, 2016
Nonlinear Vibration Control Experimental System Design of a Flexible Arm Using Interactive Actuations from Shape
Ximei Li1, Guang Jin1, Mingcong Deng1
1The Graduate School of Engineering, Tokyo University of Agriculture and Technology, Tokyo 183-8538, Japan.

Abstract:
The flexible arm easily vibrates due to its thin structural characteristics, which affect the operation accuracy, so reducing the vibration of the flexible arm is a significant issue. Smart materials are very widely used in the research topic of vibration suppression. Considering the hysteresis characteristic of the smart materials, based on previous simulation research, this paper proposes an experimental system design of nonlinear vibration control by using the interactive actuation from shape memory alloy (SMA) for a flexible arm. The experiment system was an interactive actuator-sensor-controller combination. The vibration suppression strategy was integrated with an operator-based vibration controller, a designed integral compensator and the designed n-times feedback loop. In detail, a nonlinear vibration controller based on operator theory was designed to guarantee the robust stability of the flexible arm. An integral compensator based on an estimation mechanism was designed to optimally reduce the displacement of the flexible arm. Obtaining the desired tracking performance of the flexible arm was a further step, by increasing the n-times feedback loop. From the three experimental cases, when the vibration controller was integrated with the designed integral compensator, the vibration displacement of the flexible arm was much reduced compared to that without the integral compensator. Increasing the number of n-times feedback loops improves the tracking performance. The desired vibration control performance can be satisfied when n tends to infinity. The conventional PD controller stabilizes the vibration displacement after the 7th vibration waveform, while the vibration displacement approaches zero after the 4th vibration waveform using the proposed vibration control method, which is proved to be faster and more effective in controlling the flexible arm's vibration. The experimental cases verify the effectiveness of the proposed interactive actuation vibration control approach. It is observed from the experimental results that the vibration displacement of the flexible arm becomes almost zero within less time and with lower input power, compared with a traditional controller.

Related Concept Videos
 01:20
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...
 01:20
Plastic Deformation in Circular Shafts
 01:14
Bending of Curved Members - Strain Analysis
The important part of bending analysis for such a member...
 01:15
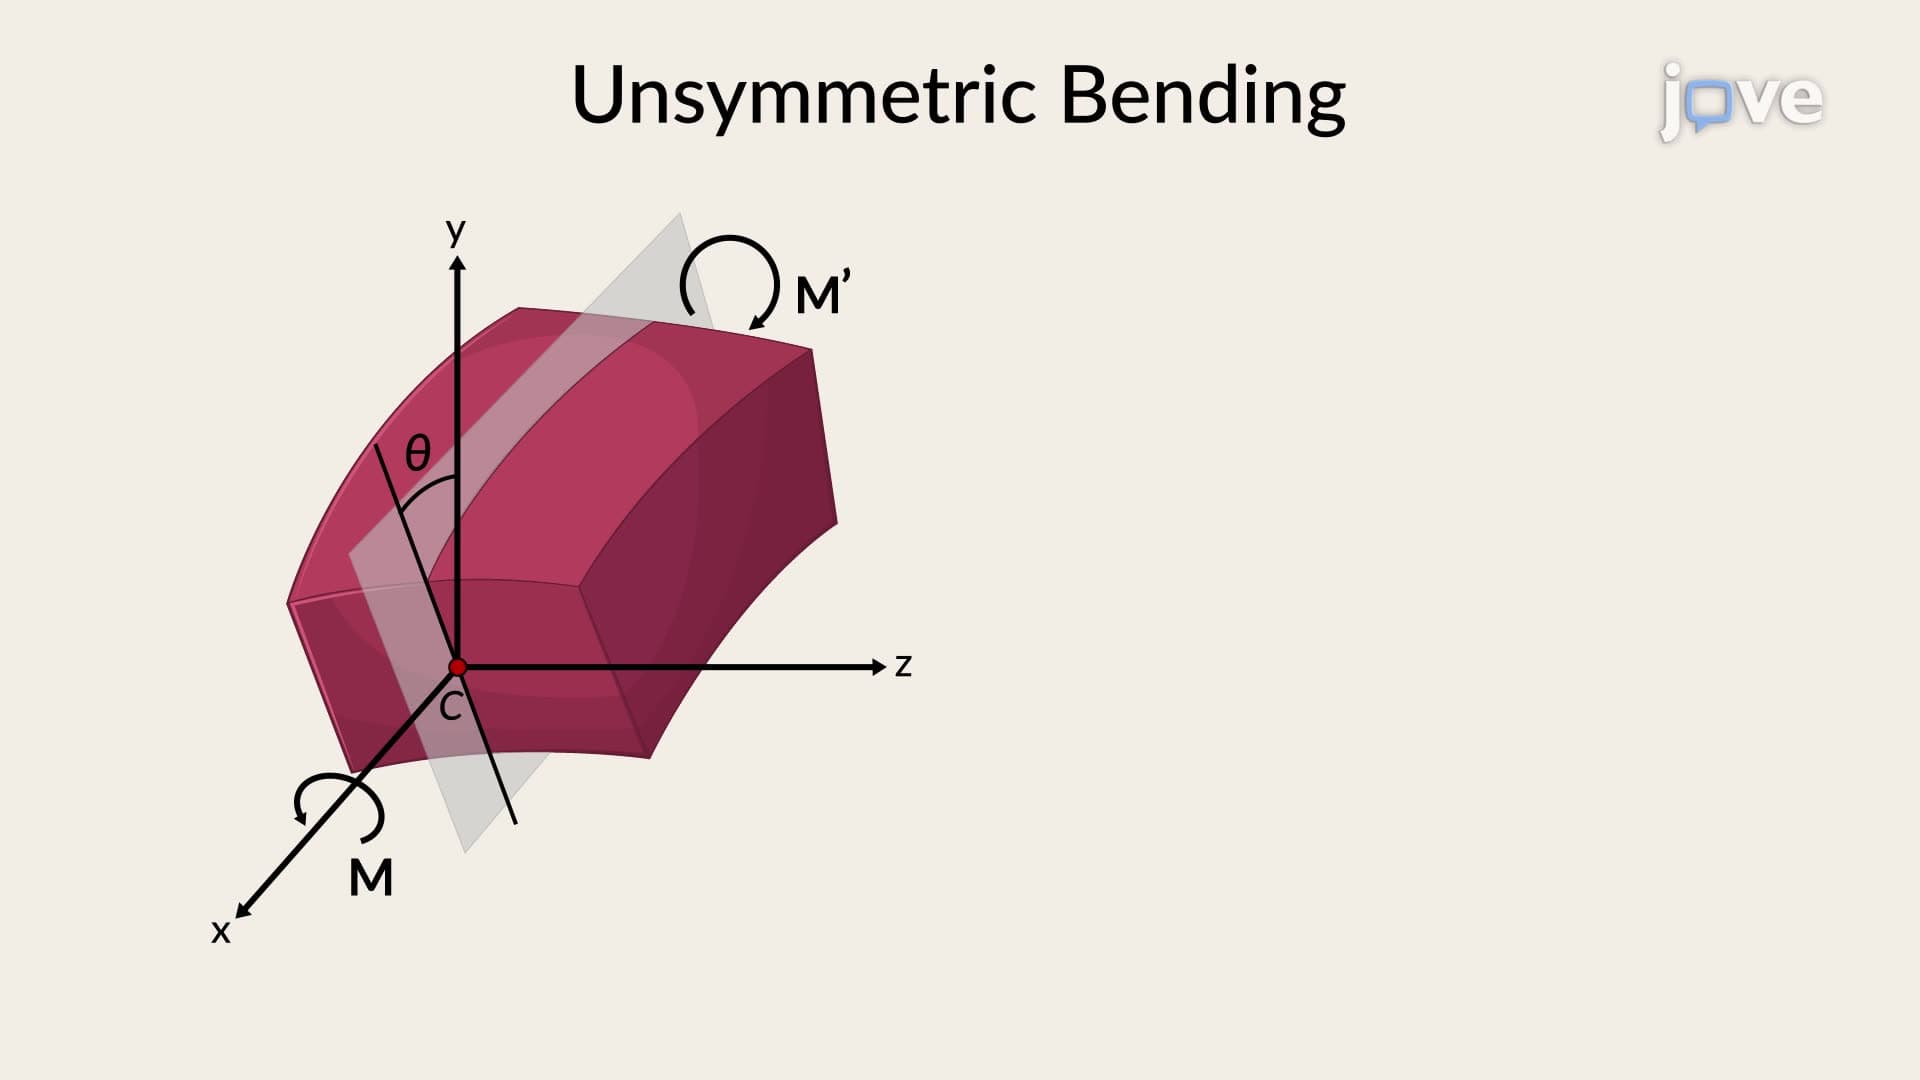
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:10
Deformation in a Circular Shaft
 01:15
Deformation of a Beam under Transverse Loading
The insights from the bending moment diagram extend to...