Motion behaviour recognition dataset collected from human perception of collective motion behaviour
Related Experiment Video
Updated: Aug 8, 2025
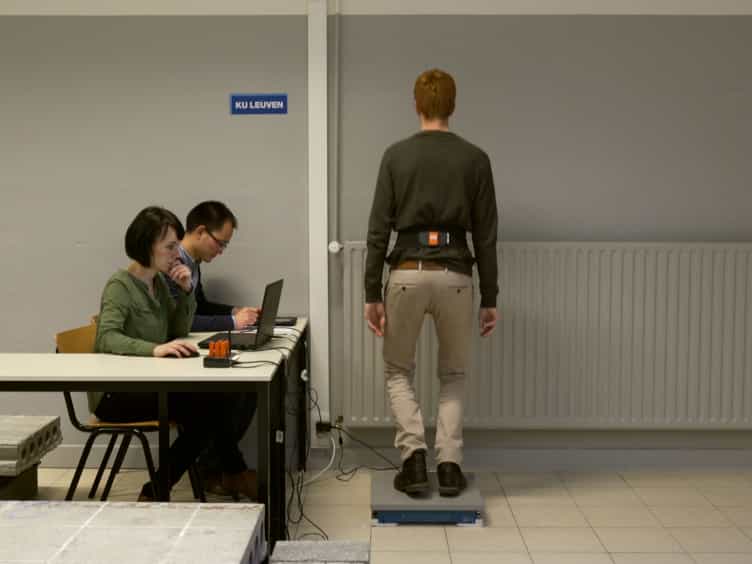
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Shadi Abpeikar1, Kathryn Kasmarik1
1School of Engineering and IT, UNSW Canberra, Northcott Drive, Canberra, ACT, 2612, Australia.

Abstract:
Collective motion behaviour such as the movement of swarming bees, flocking birds or schooling fish has inspired computer-based swarming systems. They are widely used in agent formation control, including aerial and ground vehicles, teams of rescue robots, and exploration of dangerous environments with groups of robots. Collective motion behaviour is easy to describe, but highly subjective to detect. Humans can easily recognise these behaviours; however, it is hard for a computer system to recognise them. Since humans can easily recognise these behaviours, ground truth data from human perception is one way to enable machine learning methods to mimic this human perception. Hence ground truth data has been collected from human perception of collective motion behaviour recognition by running an online survey. In this survey, participants provide their opinion about the behaviour of 'boid' point masses. Each question of the survey contains a short video (around 10 seconds), captured from simulated boid movements. Participants were asked to drag a slider to label each video as either 'flocking' or 'not flocking'; 'aligned' or 'not aligned' or 'grouped' or 'not grouped'. By averaging these responses, three binary labels were created for each video. This data has been analysed to confirm that it is possible for a machine to learn binary classification labels from the human perception of collective behaviour dataset with high accuracy.
More Related Videos

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...