Related Experiment Video
Updated: Aug 7, 2025

A Robotic Platform to Study the Foreflipper of the California Sea Lion
Published on: January 10, 2017
Self-propulsion via slipping: Frictional swimming in multilegged locomotors
Baxi Chong1,2, Juntao He3, Shengkai Li2
1Interdisciplinary Graduate Program in Quantitative Biosciences, Georgia Institute of Technology, Atlanta, GA 30332.

Abstract:
Locomotion is typically studied either in continuous media where bodies and legs experience forces generated by the flowing medium or on solid substrates dominated by friction. In the former, centralized whole-body coordination is believed to facilitate appropriate slipping through the medium for propulsion. In the latter, slip is often assumed minimal and thus avoided via decentralized control schemes. We find in laboratory experiments that terrestrial locomotion of a meter-scale multisegmented/legged robophysical model resembles undulatory fluid swimming. Experiments varying waves of leg stepping and body bending reveal how these parameters result in effective terrestrial locomotion despite seemingly ineffective isotropic frictional contacts. Dissipation dominates over inertial effects in this macroscopic-scaled regime, resulting in essentially geometric locomotion on land akin to microscopic-scale swimming in fluids. Theoretical analysis demonstrates that the high-dimensional multisegmented/legged dynamics can be simplified to a centralized low-dimensional model, which reveals an effective resistive force theory with an acquired viscous drag anisotropy. We extend our low-dimensional, geometric analysis to illustrate how body undulation can aid performance in non-flat obstacle-rich terrains and also use the scheme to quantitatively model how body undulation affects performance of biological centipede locomotion (the desert centipede Scolopendra polymorpha) moving at relatively high speeds (∼0.5 body lengths/sec). Our results could facilitate control of multilegged robots in complex terradynamic scenarios.


Related Concept Videos
 01:31
Mechanism of Lamellipodia Formation
 01:09
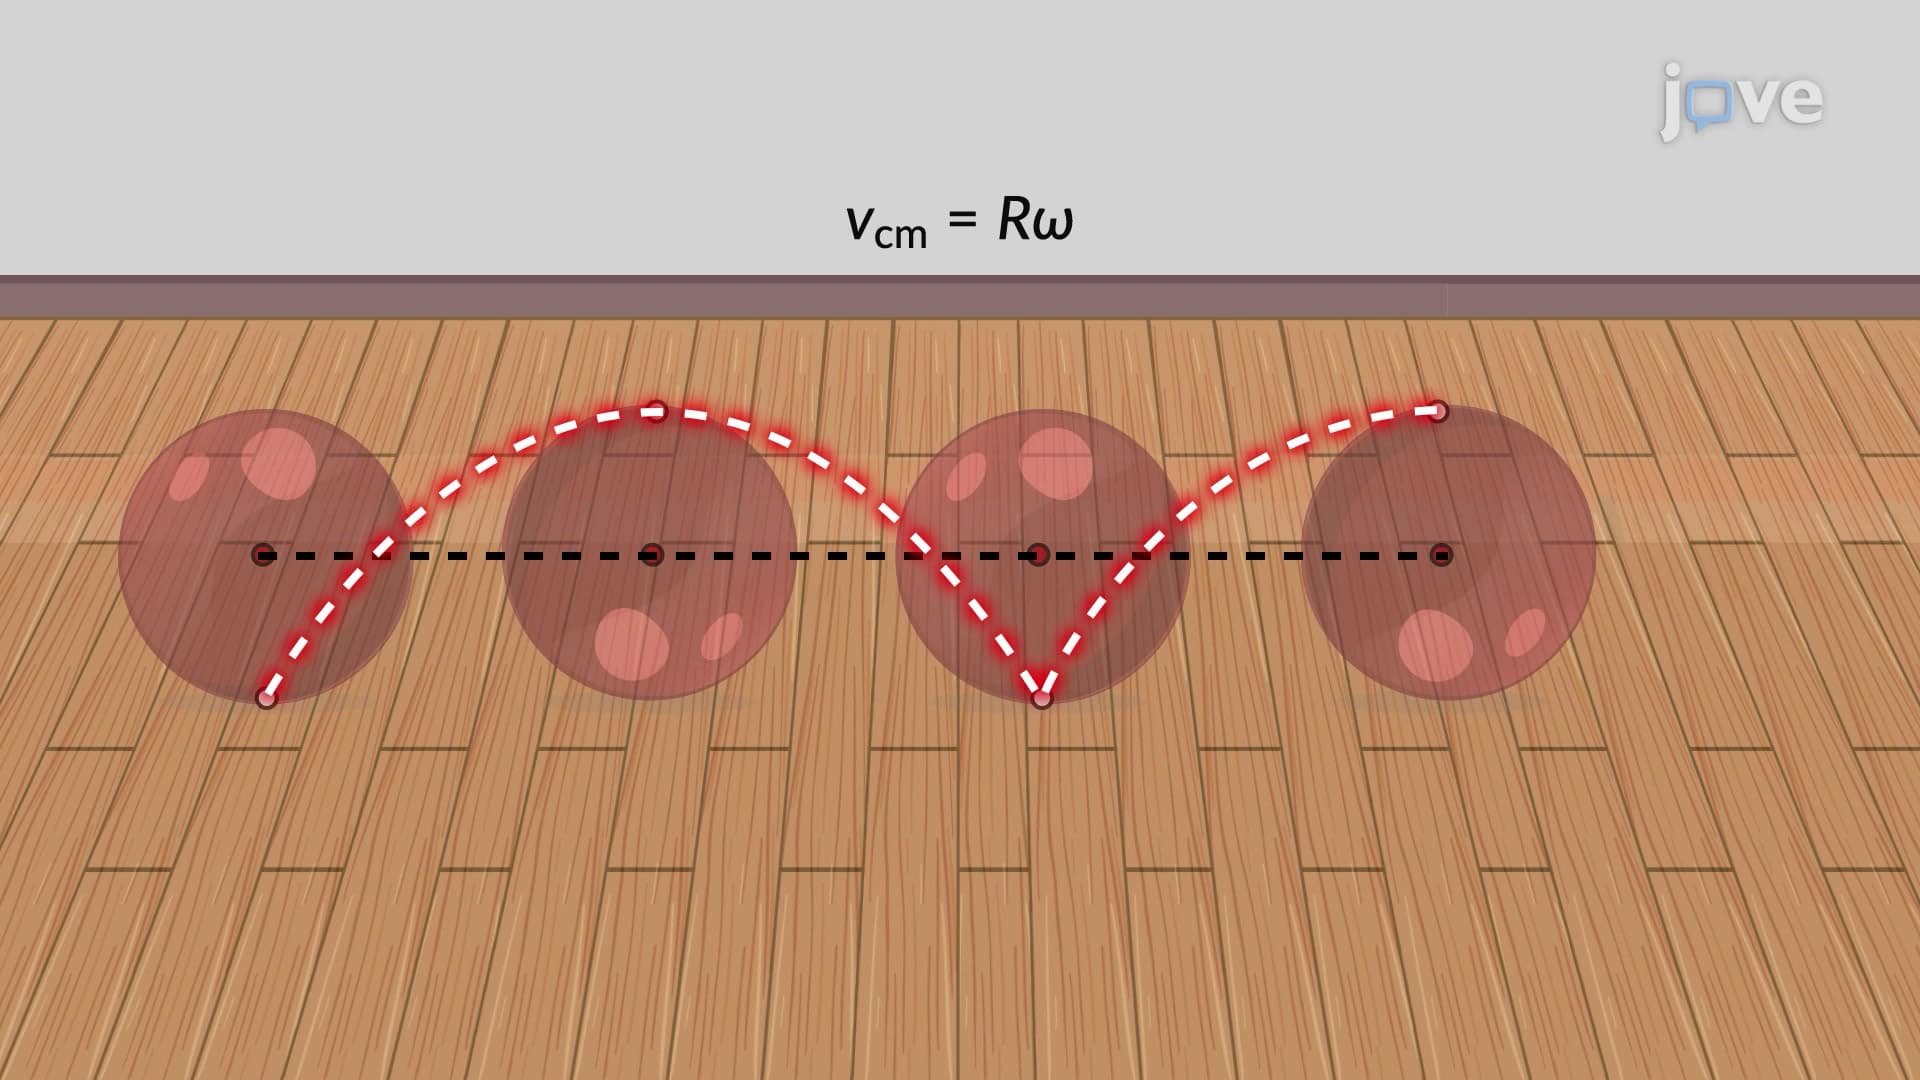
Rolling Without Slipping
 01:14
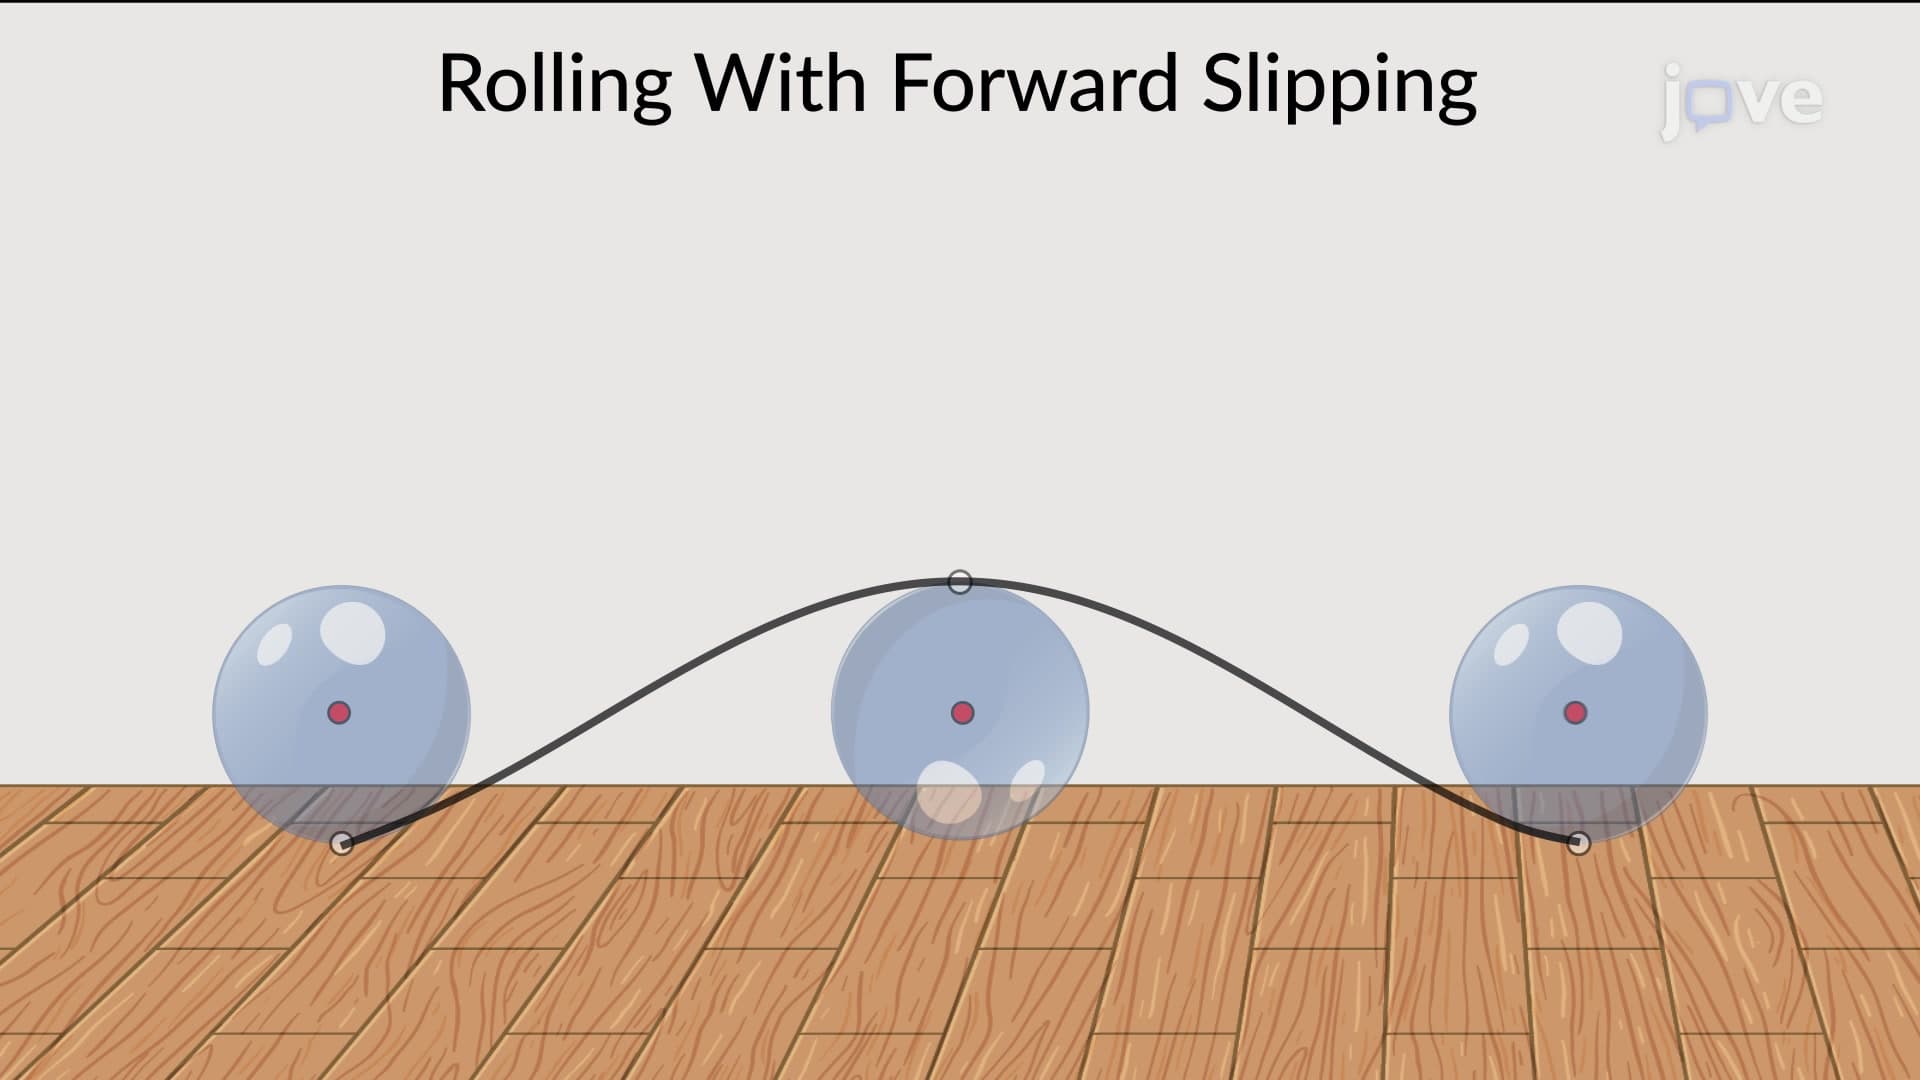
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:18
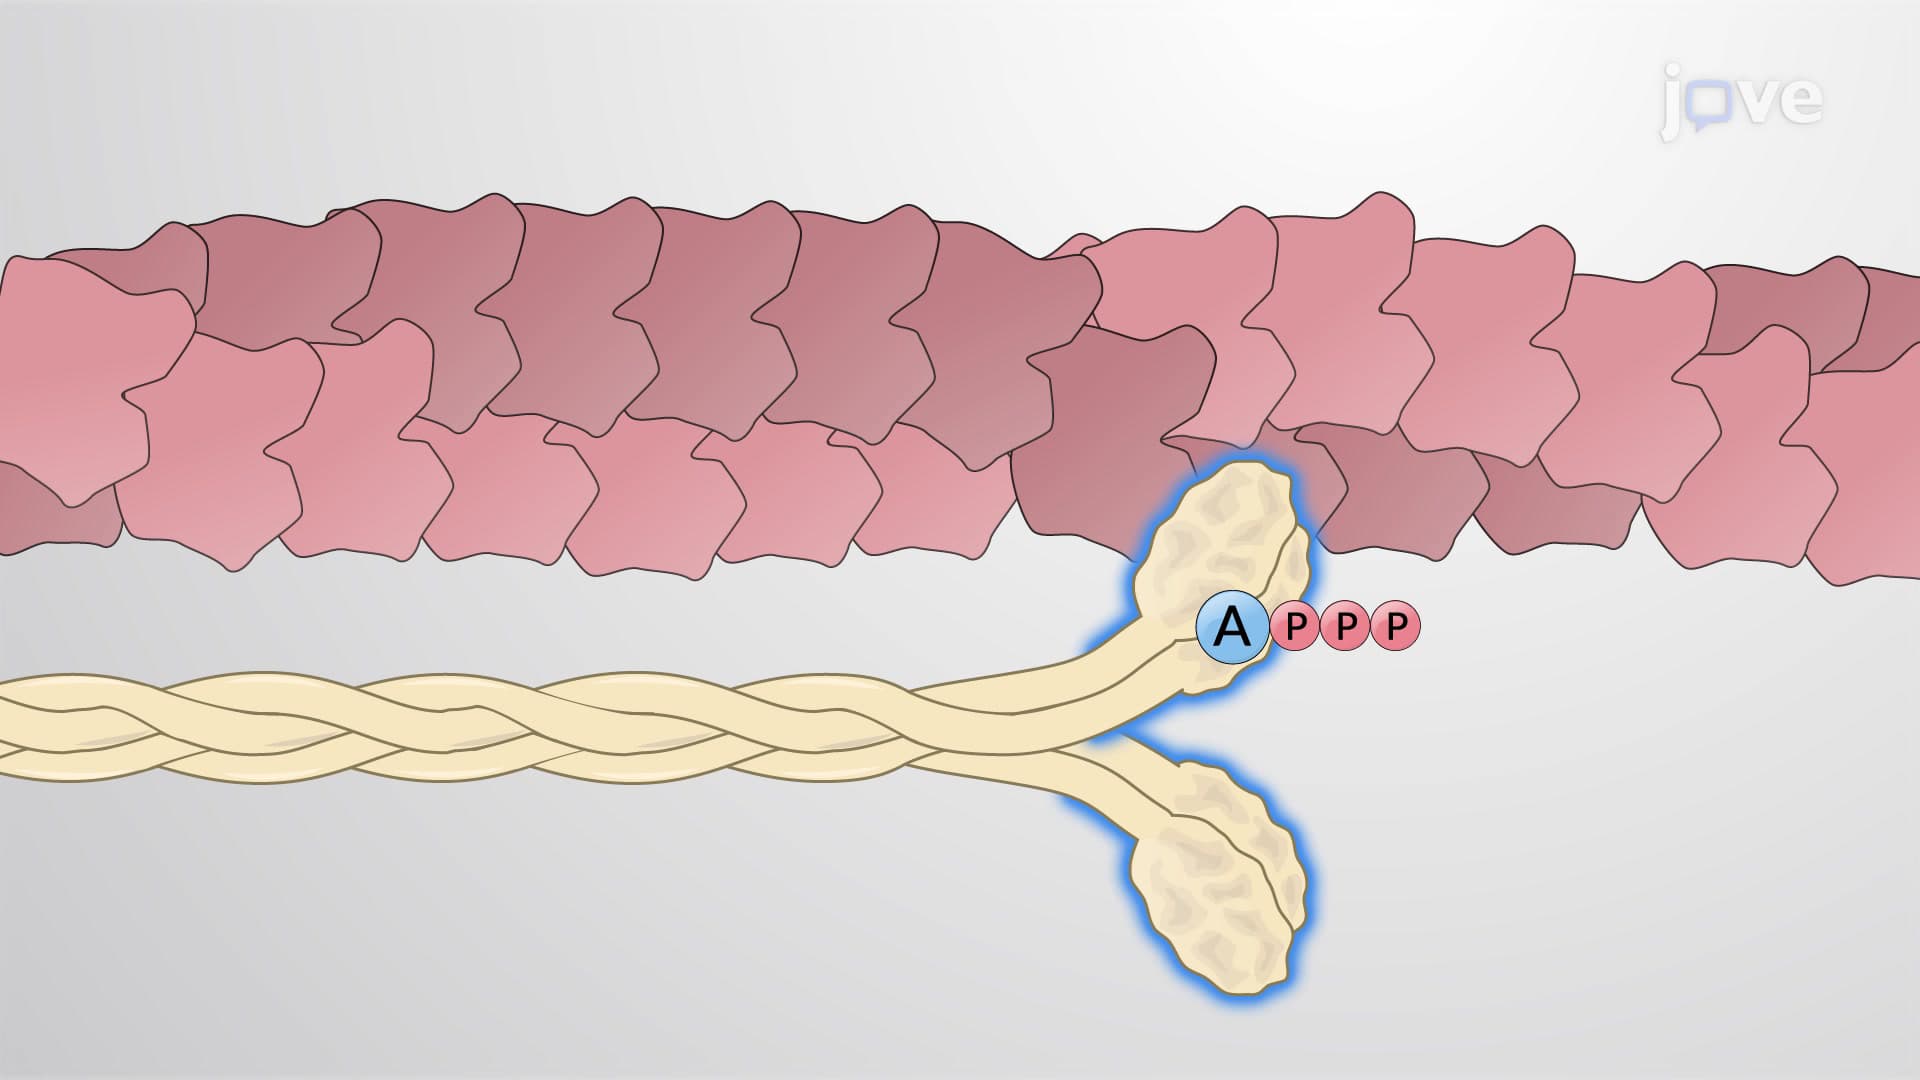
Role of Myosin in Cell Migration
Myosin II is a hexamer comprising two heavy chains with globular heads and coiled-coil tails, two regulatory light chains, and two essential light chains. The ATPase sites on the myosin heads hydrolyze ATP, and the released phosphate generates the force for contraction....
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:05
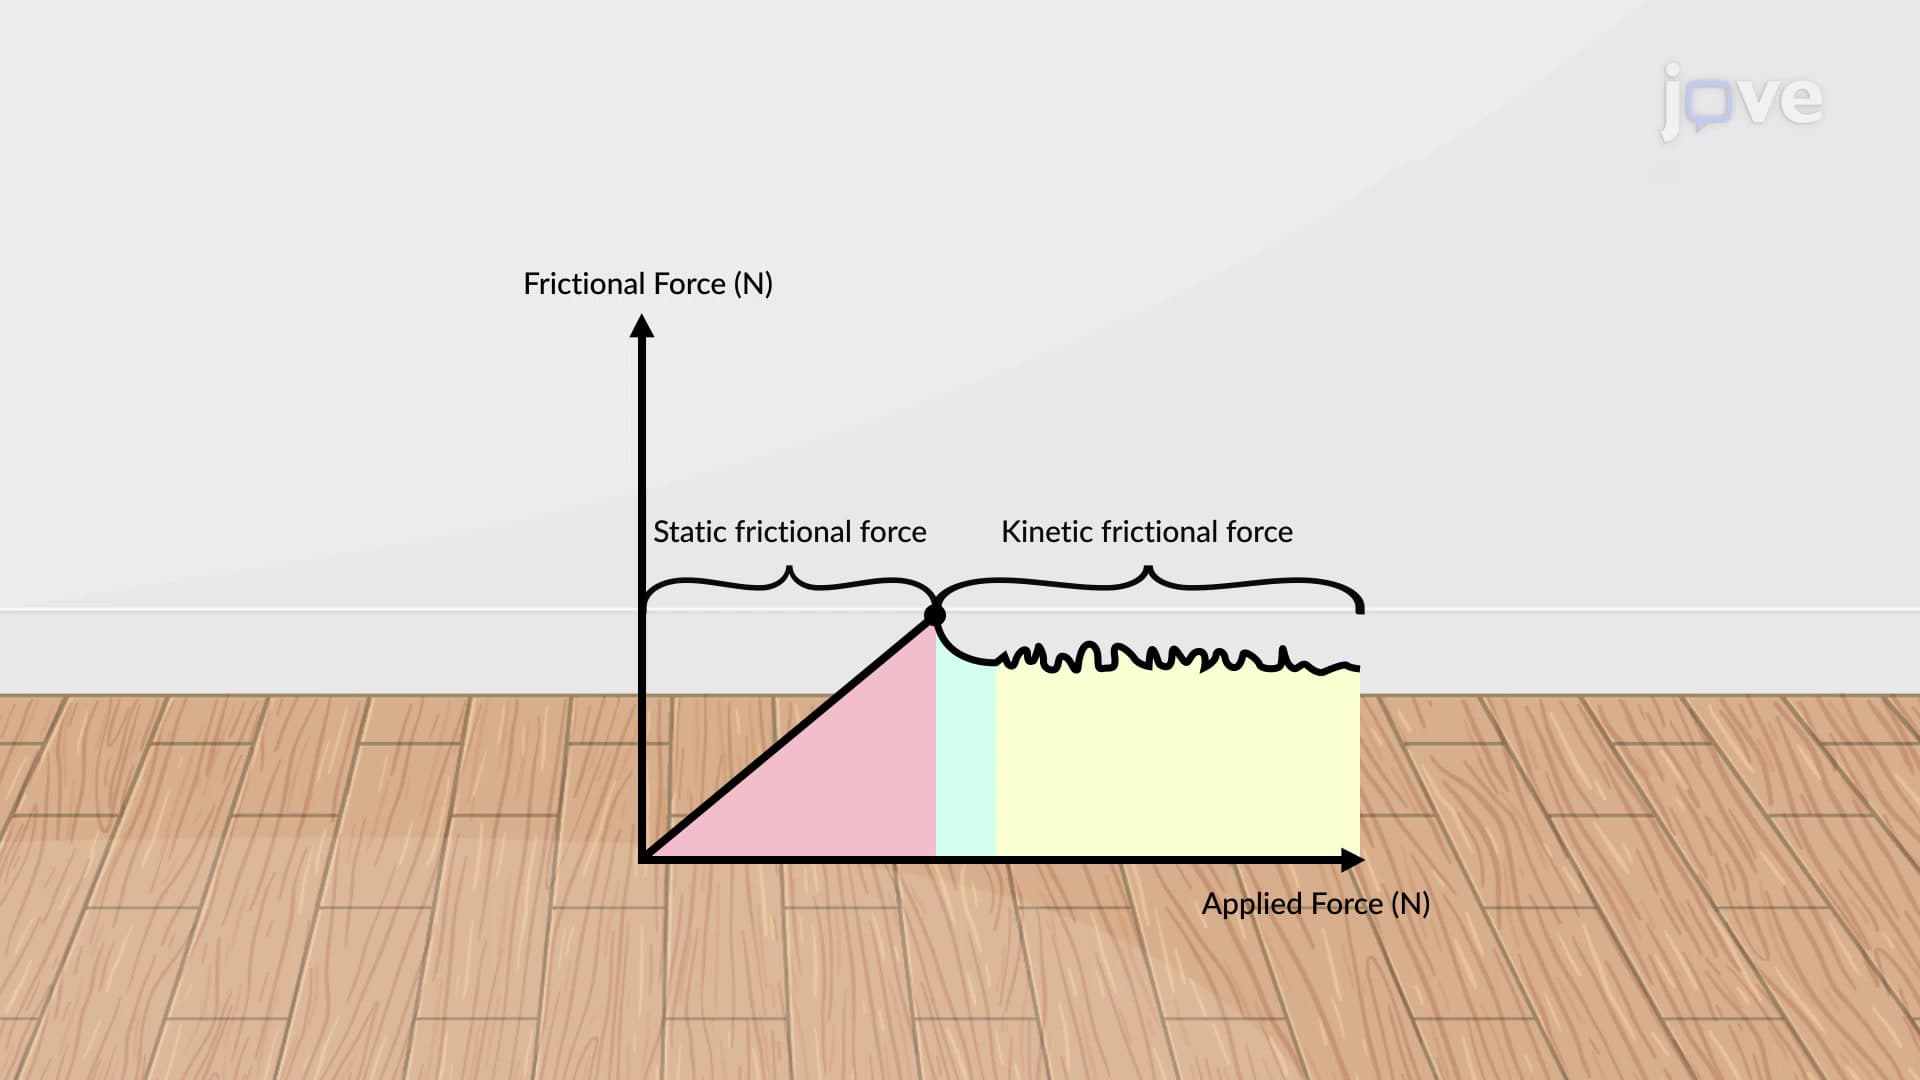
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...