Related Experiment Video
Updated: Aug 7, 2025

Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design and Backdrivability Modeling of a Portable High Torque Robotic Knee Prosthesis With Intrinsic Compliance For
Junxi Zhu1, Chunhai Jiao1, Israel Dominguez1
1Laboratory of Biomechatronics and Intelligent Robotics, Department of Mechanical and Aerospace Engineering, North Carolina State University, Raleigh, NC 27695 USA.

Abstract:
High-performance prostheses are crucial to enable versatile activities like walking, squatting, and running for lower extremity amputees. State-of-the-art prostheses are either not powerful enough to support demanding activities or have low compliance (low backdrivability) due to the use of high speed ratio transmission. Besides speed ratio, gearbox design is also crucial to the compliance of wearable robots, but its role is typically ignored in the design process. This paper proposed an analytical backdrive torque model that accurately estimate the backdrive torque from both motor and transmission to inform the robot design. Following this model, this paper also proposed methods for gear transmission design to improve compliance by reducing inertia of the knee prosthesis. We developed a knee prosthesis using a high torque actuator (built-in 9:1 planetary gear) with a customized 4:1 low-inertia planetary gearbox. Benchtop experiments show the backdrive torque model is accurate and proposed prosthesis can produce 200 Nm high peak torque (shield temperature <60°C), high compliance (2.6 Nm backdrive torque), and high control accuracy (2.7/8.1/1.7 Nm RMS tracking errors for 1.25 m/s walking, 2 m/s running, and 0.25 Hz squatting, that are 5.4%/4.1%/1.4% of desired peak torques). Three able-bodied subject experiments showed our prosthesis could support agile and high-demanding activities.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 08:08
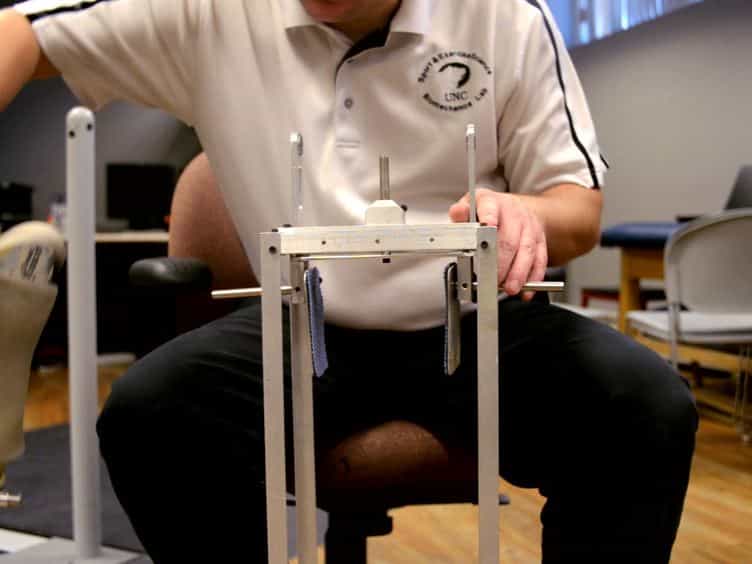
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
