Related Experiment Video
Updated: Aug 6, 2025
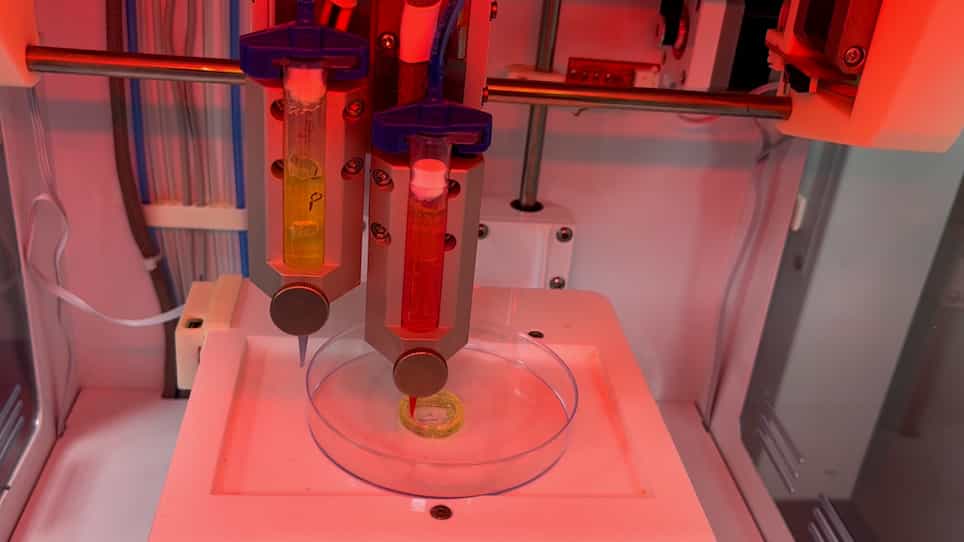

Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
Human hand-inspired all-hydrogel gripper with a high load capacity formed by the split-brushing adhesion of diverse
Hye Been Koo1, Eunseok Heo1, In Cho1
1Department of Materials Science and Engineering, Korea Advanced Institute of Science and Technology (KAIST), Daejeon, 34141, Republic of Korea. jbchang03@kaist.ac.kr.

Abstract:
Human hands are highly versatile. Even though they are primarily made of materials with high water content, they exhibit a high load capacity. However, existing hydrogel grippers do not possess a high load capacity due to their innate softness and mechanical strength. This work demonstrates a human hand-inspired all-hydrogel gripper that can bear more than 47.6 times its own weight. This gripper is made of two hydrogels: poly(methacrylamide-co-methacrylic acid) (P(MAAm-co-MAAc)) and poly(N-isopropylacrylamide) (PNIPAM). P(MAAm-co-MAAc) is extremely stiff but becomes soft above its transition temperature. By taking advantage of the difference in the kinetics of the stiff-soft transition of P(MAAm-co-MAAc) hydrogels and the swelling-shrinking transition of PNIPAM hydrogels, this gripper can be switched between its stiff-bent and stiff-stretched states by simply changing the temperature. The assembly of these two hydrogels into a gripper necessitated the development of a new hydrogel adhesion method, as existing topological adhesion methods are not applicable to such stiff hydrogels. A new hydrogel adhesion method, termed split-brushing adhesion, has been demonstrated to satisfy this need. When applied to P(MAAm-co-MAAc) hydrogels, this method achieves an adhesion energy of 1221.6 J m-2, which is 67.5 times higher than that achieved with other topological adhesion methods.

