Related Experiment Video
Updated: Aug 6, 2025
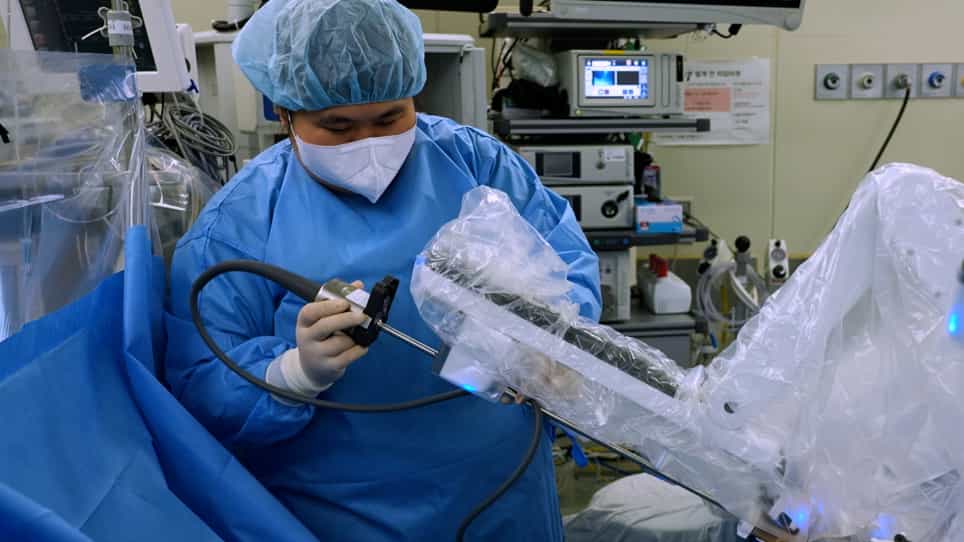

Robot-Assisted Kidney Transplantation
Published on: July 19, 2021
Single Port Robotic Kidney Autotransplantation: Initial Case Series and Description of Technique
Jihad Kaouk1, Jaya S Chavali1, Ethan Ferguson1
1Glickman Urological and Kidney Institute, Cleveland Clinic, Cleveland, OH.

Purpose:
Minimally invasive kidney autotransplantation (KAT) has demonstrated reduced morbidity, however multiport robotic approach required patient repositioning and multiple sets of incisions. We present our initial series of single-port (SP) robotic KAT, ideal for multi-quadrant surgeries, and aim to evaluate feasibility and safety of the novel approach.
Methods:
Between 2018 and 2022, 8 consecutive patients underwent SP KAT using the DaVinci SP platform. Patient clinicopathologic variables and perioperative outcomes were recorded. Indications for KAT include complex or recurrent ureteral stricture, ureteral avulsion, and chronic visceral pain due to multiple etiologies.
Results:
All SP KATs were successfully performed without repositioning or conversion to open. Operative times ranged from 366 to 701 minutes, warm and cold ischemia times between 4 to 10 minutes and 86 to 209 minutes, respectively. Median hospital length of stay was 3 days. At a median of 13 months follow-up, latest postoperative GFRs were stable, ranging from +23% to -10%. There were no complications.
Conclusion:
We demonstrate our single port, multiquadrant robotic kidney auto transplantation technique performed though a single incision further reducing surgical morbidity. All cases were completed successfully without conversion or loss of graft function. All patients reported resolution of flank pain and no radiological evidence of urinary obstruction on follow up.
Related Concept Videos
 01:26
Kidney Transplant II: Surgical Procedure
 01:28
Kidney Transplant I: Introduction