Related Experiment Video
Updated: Aug 6, 2025
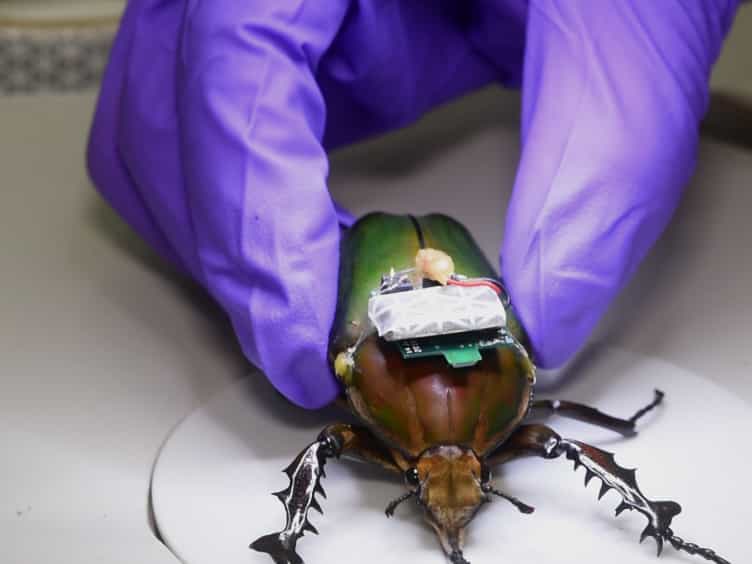

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Movement Optimization for a Cyborg Cockroach in a Bounded Space Incorporating Machine Learning
Mochammad Ariyanto1,2, Chowdhury Mohammad Masum Refat1, Kazuyoshi Hirao1
1Department of Mechanical Engineering, Graduate School of Engineering, Osaka University, Suita 565-0871, Japan.

Abstract:
Cockroaches can traverse unknown obstacle-terrain, self-right on the ground and climb above the obstacle. However, they have limited motion, such as less activity in light/bright areas and lower temperatures. Therefore, the movement of the cyborg cockroaches needs to be optimized for the utilization of the cockroach as a cyborg insect. This study aims to increase the search rate and distance traveled by cockroaches and reduce the stop time by utilizing automatic stimulation from machine learning. Multiple machine learning classifiers were applied to classify the offline binary classification of the cockroach movement based on the inertial measuring unit input signals. Ten time-domain features were chosen and applied as the classifier inputs. The highest performance of the classifiers was implemented for the online motion recognition and automatic stimulation provided to the cerci to trigger the free walking motion of the cockroach. A user interface was developed to run multiple computational processes simultaneously in real time such as computer vision, data acquisition, feature extraction, automatic stimulation, and machine learning using a multithreading algorithm. On the basis of the experiment results, we successfully demonstrated that the movement performance of cockroaches was importantly improved by applying machine learning classification and automatic stimulation. This system increased the search rate and traveled distance by 68% and 70%, respectively, while the stop time was reduced by 78%.

Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:32
Cytoskeletal Coordination in Cell Migration
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:03
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...