Related Experiment Video
Updated: Aug 5, 2025

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Glenohumeral joint trajectory tracking for improving the shoulder compliance of the upper limb rehabilitation robot
Yi Tang1, Duo Hao2, Chengbing Cao2
1Institute of Rehabilitation Engineering and Technology, University of Shanghai for Science and Technology, Shanghai, 200093, China.

Background:
Exoskeletons have become an important tool to help patients with upper extremity motor dysfunction in rehabilitation training and life assistance. In the study of the upper limb exoskeleton, the human glenohumeral joint will produce accompanying movement during the movement of the shoulder joint. This phenomenon causes a positional deviation between the shoulder joint and the exoskeleton, which affects the accuracy of exoskeleton-assisted human movement and the wearing comfort. Spend.
Method:
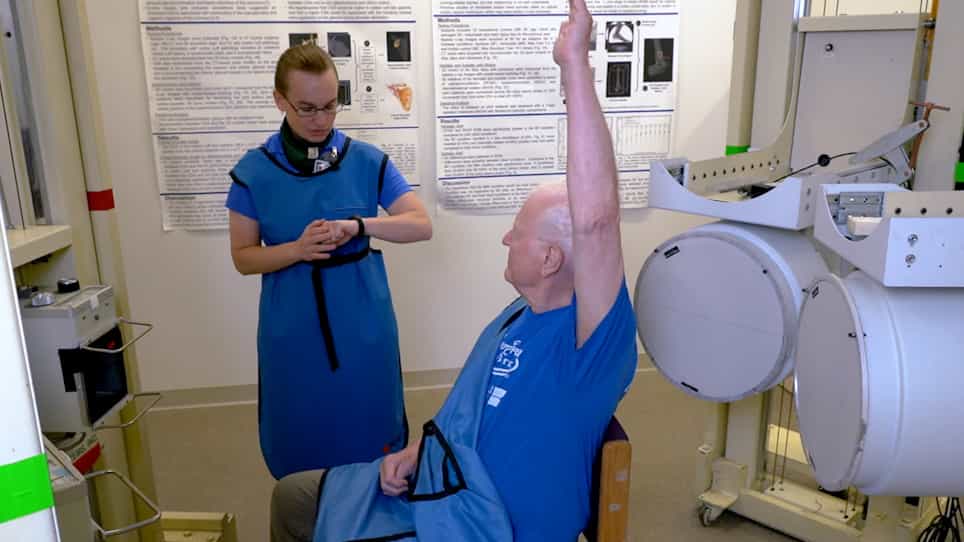
Taking the coronal adduction and abduction of the shoulder joint as the research object, the shoulder joint angle and glenohumeral joint bony motion trajectory were fitted by bi-level X-rays, and then the Ultium Motion motion capture system was used to collect the characteristic motion of the shoulder joint surface and establish a model. A back-propagation neural network with shoulder joint motion and shoulder width as input and the coronal position of the glenohumeral joint as output, finally applied the model to the Nimbot exoskeleton upper limb rehabilitation training robot to verify the effectiveness of the algorithm.
Results:
Real-time prediction of the glenohumeral joint motion trajectory was achieved, and the human-machine coupling compliance during the wearing of the upper limb exoskeleton was improved.