Related Experiment Video
Updated: Aug 5, 2025
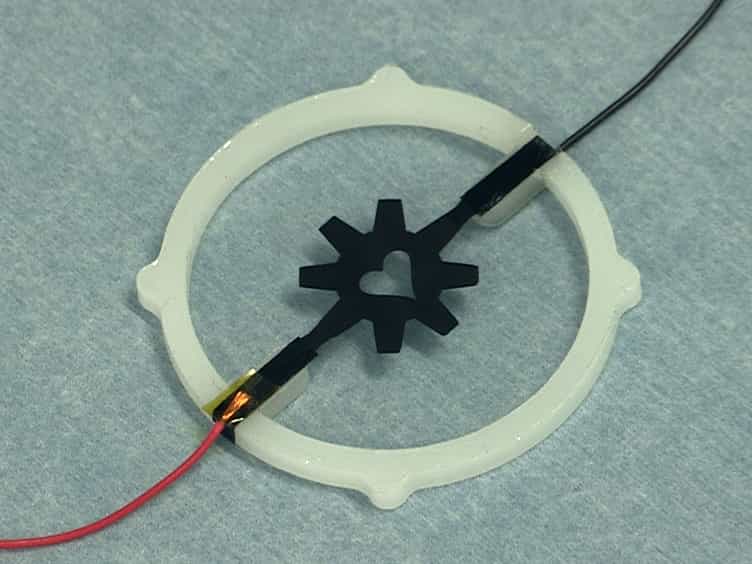

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Optimal Control of Dielectric Elastomer Actuated Multibody Dynamical Systems
Dengpeng Huang1, Sigrid Leyendecker1
1Institute of Applied Dynamics, Friedrich-Alexander-Universität Erlangen-Nürnberg, Erlangen, Germany.

Abstract:
In this work, a simulation model for the optimal control of dielectric elastomer actuated flexible multibody dynamics systems is presented. The dielectric elastomer actuator (DEA) behaves like a flexible artificial muscle in soft robotics. It is modeled as an electromechanically coupled geometrically exact beam, where the electric charges serve as control variables. The DEA-beam is integrated as an actuator into multibody systems consisting of rigid and flexible components. The model also represents contact interaction via unilateral constraints between the beam actuator and, for example, a rigid body during the grasping process of a soft robot. With a mathematically concise and physically representative formulation, a reduced free energy function is developed for the electromechanically coupled beam. In the optimal control problem, an objective function is minimized while the electromechanically coupled dynamic balance equations for the multibody system have to be fulfilled together with the complementarity conditions for the contact and boundary conditions. The optimal control problem is solved via a direct transcription method, transforming it into a constrained nonlinear optimization problem. The electromechanically coupled geometrically exact beam is firstly semidiscretized with one-dimensional finite elements and then the multibody dynamics is temporally discretized with a variational integrator leading to the discrete Euler-Lagrange equations, which are further reduced with the null space projection. The discrete Euler-Lagrange equations and the boundary conditions serve as equality constraints, whereas the contact constraints are treated as inequality constraints in the optimization of the discretized objective. The constrained optimization problem is solved using the Interior Point Optimizer solver. The effectiveness of the developed model is demonstrated by three numerical examples, including a cantilever beam, a soft robotic worm, and a soft robotic grasper.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 11:06
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Related Concept Videos
 01:22
Mechanical Systems
 01:27
Electrostatic Boundary Conditions in Dielectrics
Consider a case where both the mediums across a boundary are two different dielectric materials. Recall that the electric field and electric displacement are proportional and related through the material's...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...