Related Experiment Video
Updated: Aug 5, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Real-Time Trajectory Prediction Method for Intelligent Connected Vehicles in Urban Intersection Scenarios
Pangwei Wang1, Hongsheng Yu1, Cheng Liu1
1Beijing Key Lab of Urban Intelligent Traffic Control Technology, North China University of Technology, Beijing 100144, China.

Abstract:
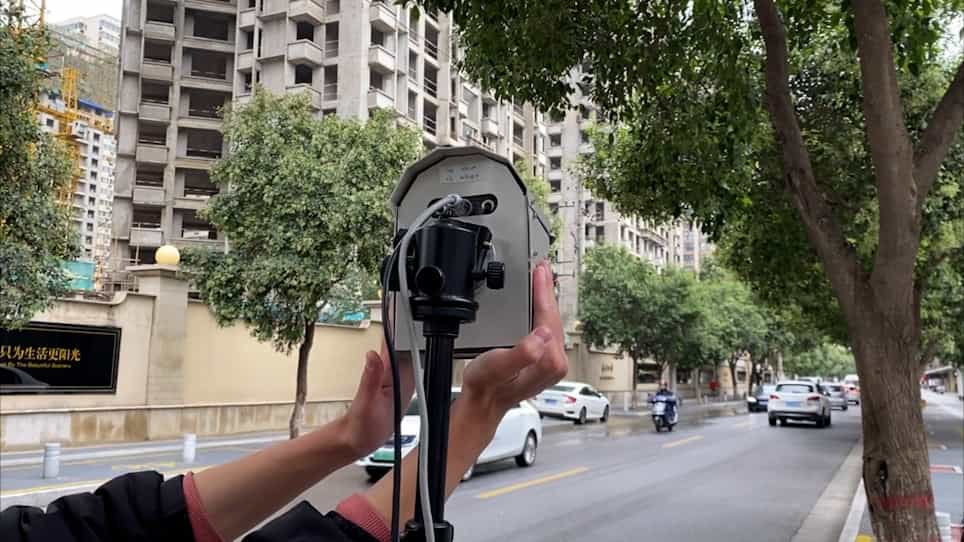
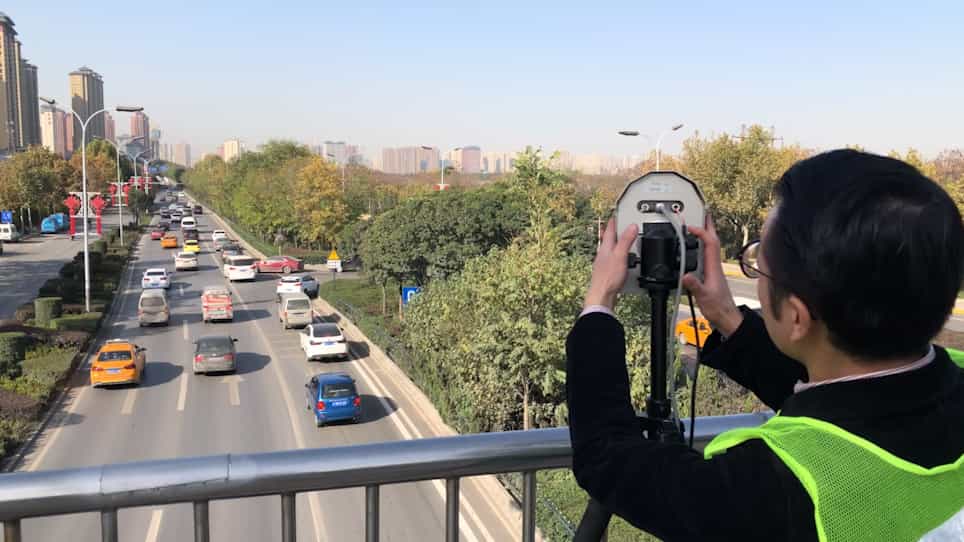
Intelligent connected vehicles (ICVs) have played an important role in improving the intelligence degree of transportation systems, and improving the trajectory prediction capability of ICVs is beneficial for traffic efficiency and safety. In this paper, a real-time trajectory prediction method based on vehicle-to-everything (V2X) communication is proposed for ICVs to improve the accuracy of their trajectory prediction. Firstly, this paper applies a Gaussian mixture probability hypothesis density (GM-PHD) model to construct the multidimension dataset of ICV states. Secondly, this paper adopts vehicular microscopic data with more dimensions, which is output by GM-PHD as the input of LSTM to ensure the consistency of the prediction results. Then, the signal light factor and Q-Learning algorithm were applied to improve the LSTM model, adding features in the spatial dimension to complement the temporal features used in the LSTM. When compared with the previous models, more consideration was given to the dynamic spatial environment. Finally, an intersection at Fushi Road in Shijingshan District, Beijing, was selected as the field test scenario. The final experimental results show that the GM-PHD model achieved an average error of 0.1181 m, which is a 44.05% reduction compared to the LiDAR-based model. Meanwhile, the error of the proposed model can reach 0.501 m. When compared to the social LSTM model, the prediction error was reduced by 29.43% under the average displacement error (ADE) metric. The proposed method can provide data support and an effective theoretical basis for decision systems to improve traffic safety.
Related Concept Videos
 01:10
Instantaneous Velocity - II
 01:12
Average and Instantaneous Velocity Vectors
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:15
Kinematic Equations: Problem Solving