Related Experiment Video
Updated: Aug 4, 2025


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Soft Robot Proprioception Using Unified Soft Body Encoding and Recurrent Neural Network
Liangliang Wang1, James Lam1, Xiaojiao Chen1
1Department of Mechanical Engineering, The University of Hong Kong, Hong Kong, China.

Abstract:
Compared with rigid robots, soft robots are inherently compliant and have advantages in the tasks requiring flexibility and safety. But sensing the high dimensional body deformation of soft robots is a challenge. Encasing soft strain sensors into the internal body of soft robots is the most popular solution to address this challenge. But most of them usually suffer from problems like nonlinearity, hysteresis, and fabrication complexity. To endow the soft robots with body movement awareness, this work presents a bioinspired architecture by taking cues from human proprioception system. Differing from the popular usage of smart material-based sensors embedded in soft actuators, we created a synthetic analog to the human muscle system, using paralleled soft pneumatic chambers to serve as receptors for sensing body deformation. We proposed to build the system with redundant receptors and explored deep learning tools for generating the kinematic model. Based on the proposed methodology, we demonstrated the design of three degrees of freedom continuum joint and how its kinematic model was learned from the unified pressure information of the actuators and receptors. In addition, we investigated the response of the soft system to receptor failures and presented both hardware and software level solutions for achieving graceful degradation. This approach offers an alternative to enable soft robots with proprioception capability, which will be useful for closed-loop control and interaction with environment.

Related Concept Videos
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:37
Neural Regulation
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
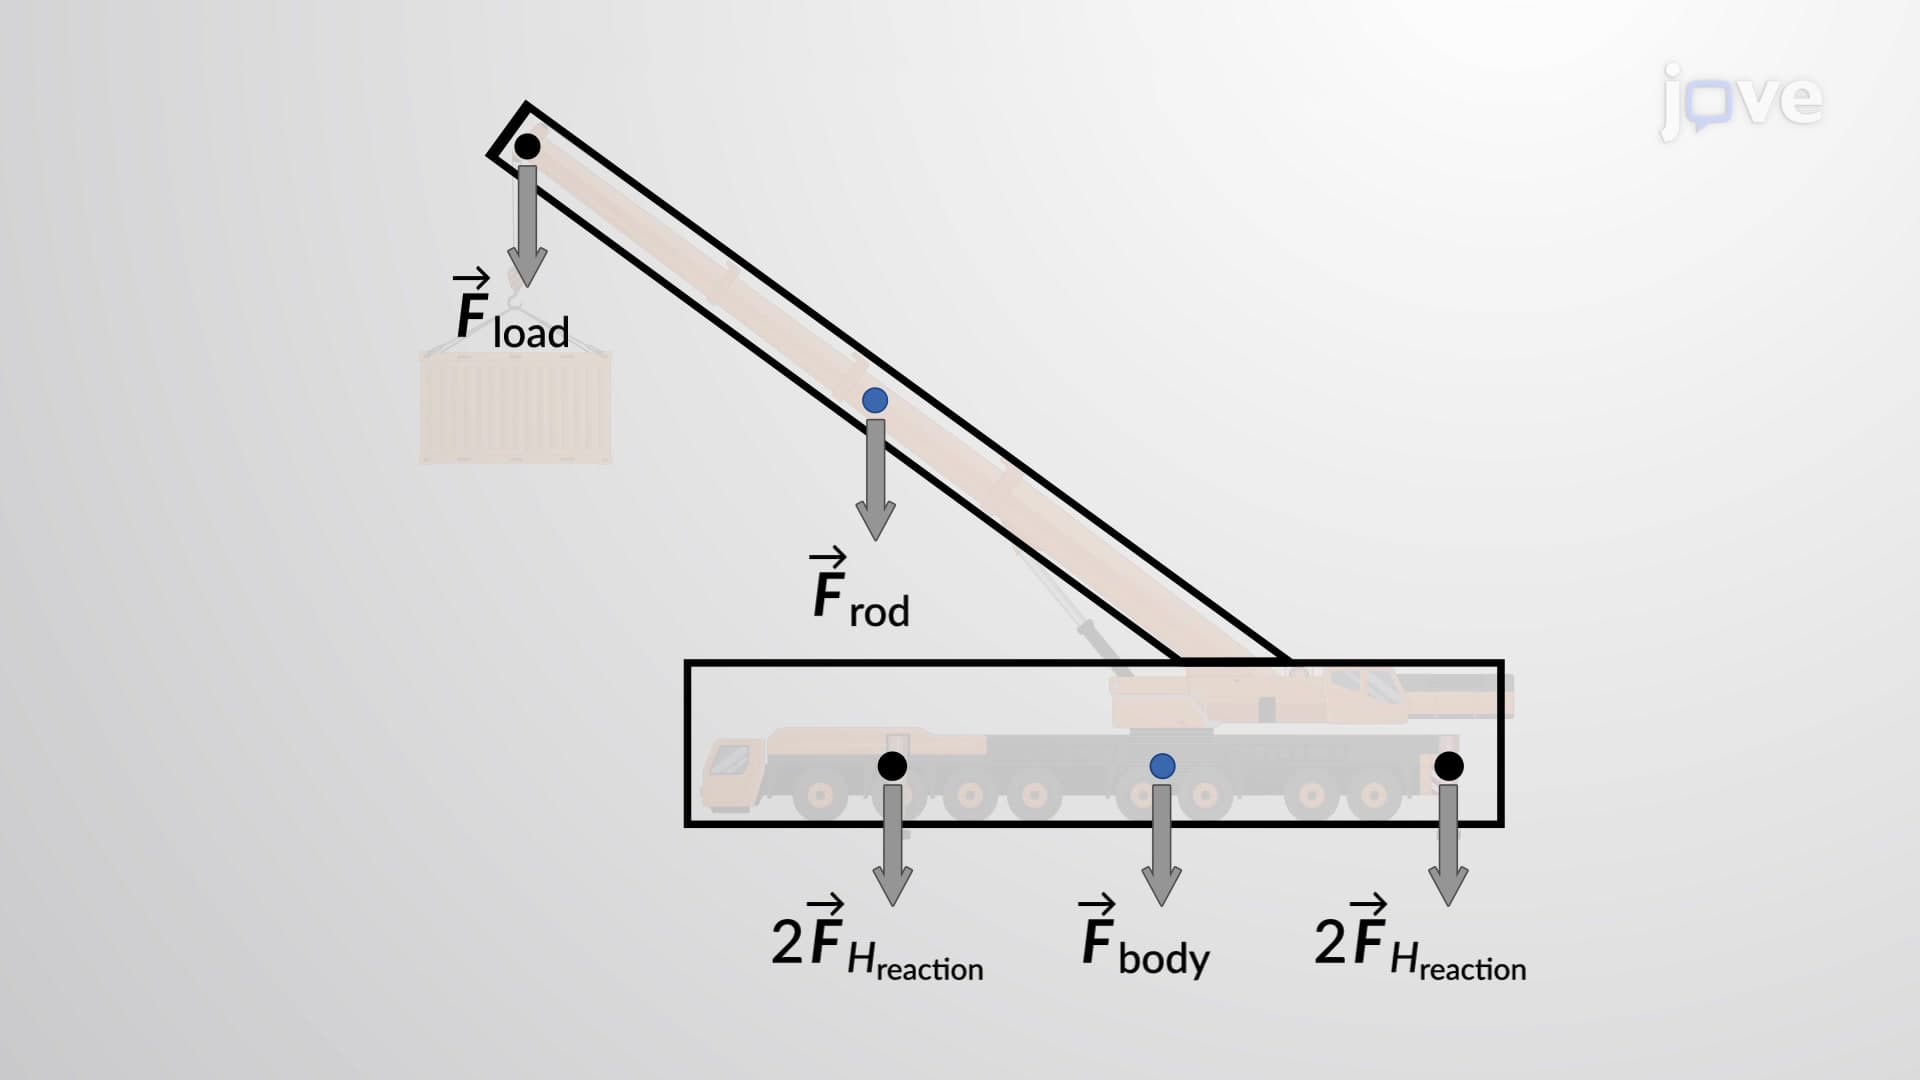
Rigid Body Equilibrium Problems - I
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...