Related Experiment Video
Updated: Aug 3, 2025
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Open-source software library for real-time inertial measurement unit data-based inverse kinematics using OpenSim
Jere Lavikainen1, Paavo Vartiainen1, Lauri Stenroth1
1Department of Technical Physics, University of Eastern Finland, Kuopio, Finland.

Background:
Inertial measurements (IMUs) facilitate the measurement of human motion outside the motion laboratory. A commonly used open-source software for musculoskeletal simulation and analysis of human motion, OpenSim, includes a tool to enable kinematics analysis of IMU data. However, it only enables offline analysis, i.e., analysis after the data has been collected. Extending OpenSim's functionality to allow real-time kinematics analysis would allow real-time feedback for the subject during the measurement session and has uses in e.g., rehabilitation, robotics, and ergonomics.
Methods:
We developed an open-source software library for real-time inverse kinematics (IK) analysis of IMU data using OpenSim. The software library reads data from IMUs and uses multithreading for concurrent calculation of IK. Its operation delays and throughputs were measured with a varying number of IMUs and parallel computing IK threads using two different musculoskeletal models, one a lower-body and torso model and the other a full-body model. We published the code under an open-source license on GitHub.
Results:
A standard desktop computer calculated full-body inverse kinematics from treadmill walking at 1.5 m/s with data from 12 IMUs in real-time with a mean delay below 55 ms and reached a throughput of more than 90 samples per second. A laptop computer had similar delays and reached a throughput above 60 samples per second with treadmill walking. Minimal walking kinematics, motion of lower extremities and torso, were calculated from treadmill walking data in real-time with a throughput of 130 samples per second on the laptop and 180 samples per second on the desktop computer, with approximately half the delay of full-body kinematics.
Conclusions:
The software library enabled real-time inverse kinematical analysis with different numbers of IMUs and customizable musculoskeletal models. The performance results show that subject-specific full-body motion analysis is feasible in real-time, while a laptop computer and IMUs allowed the use of the method outside the motion laboratory.
More Related Videos

Related Concept Videos
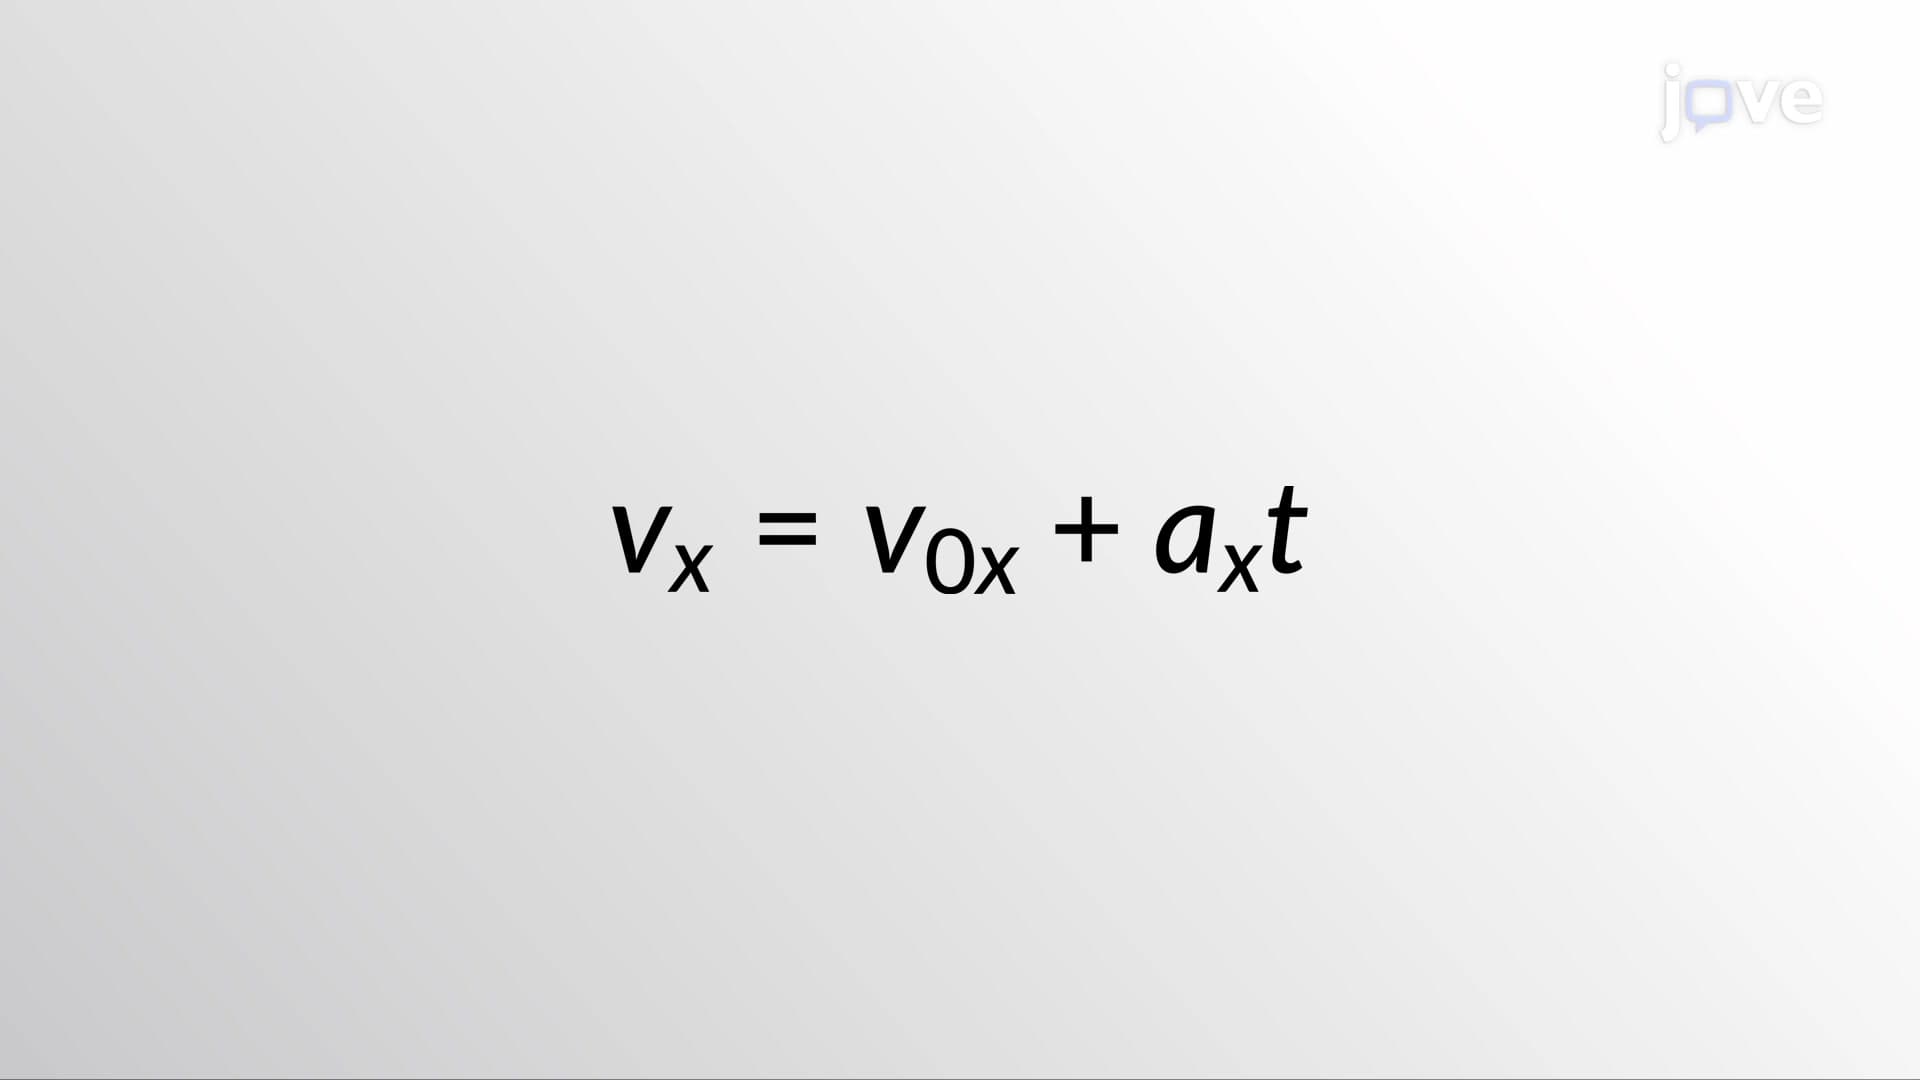 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:03
Inertial Frames of Reference