Related Experiment Video
Updated: Aug 3, 2025
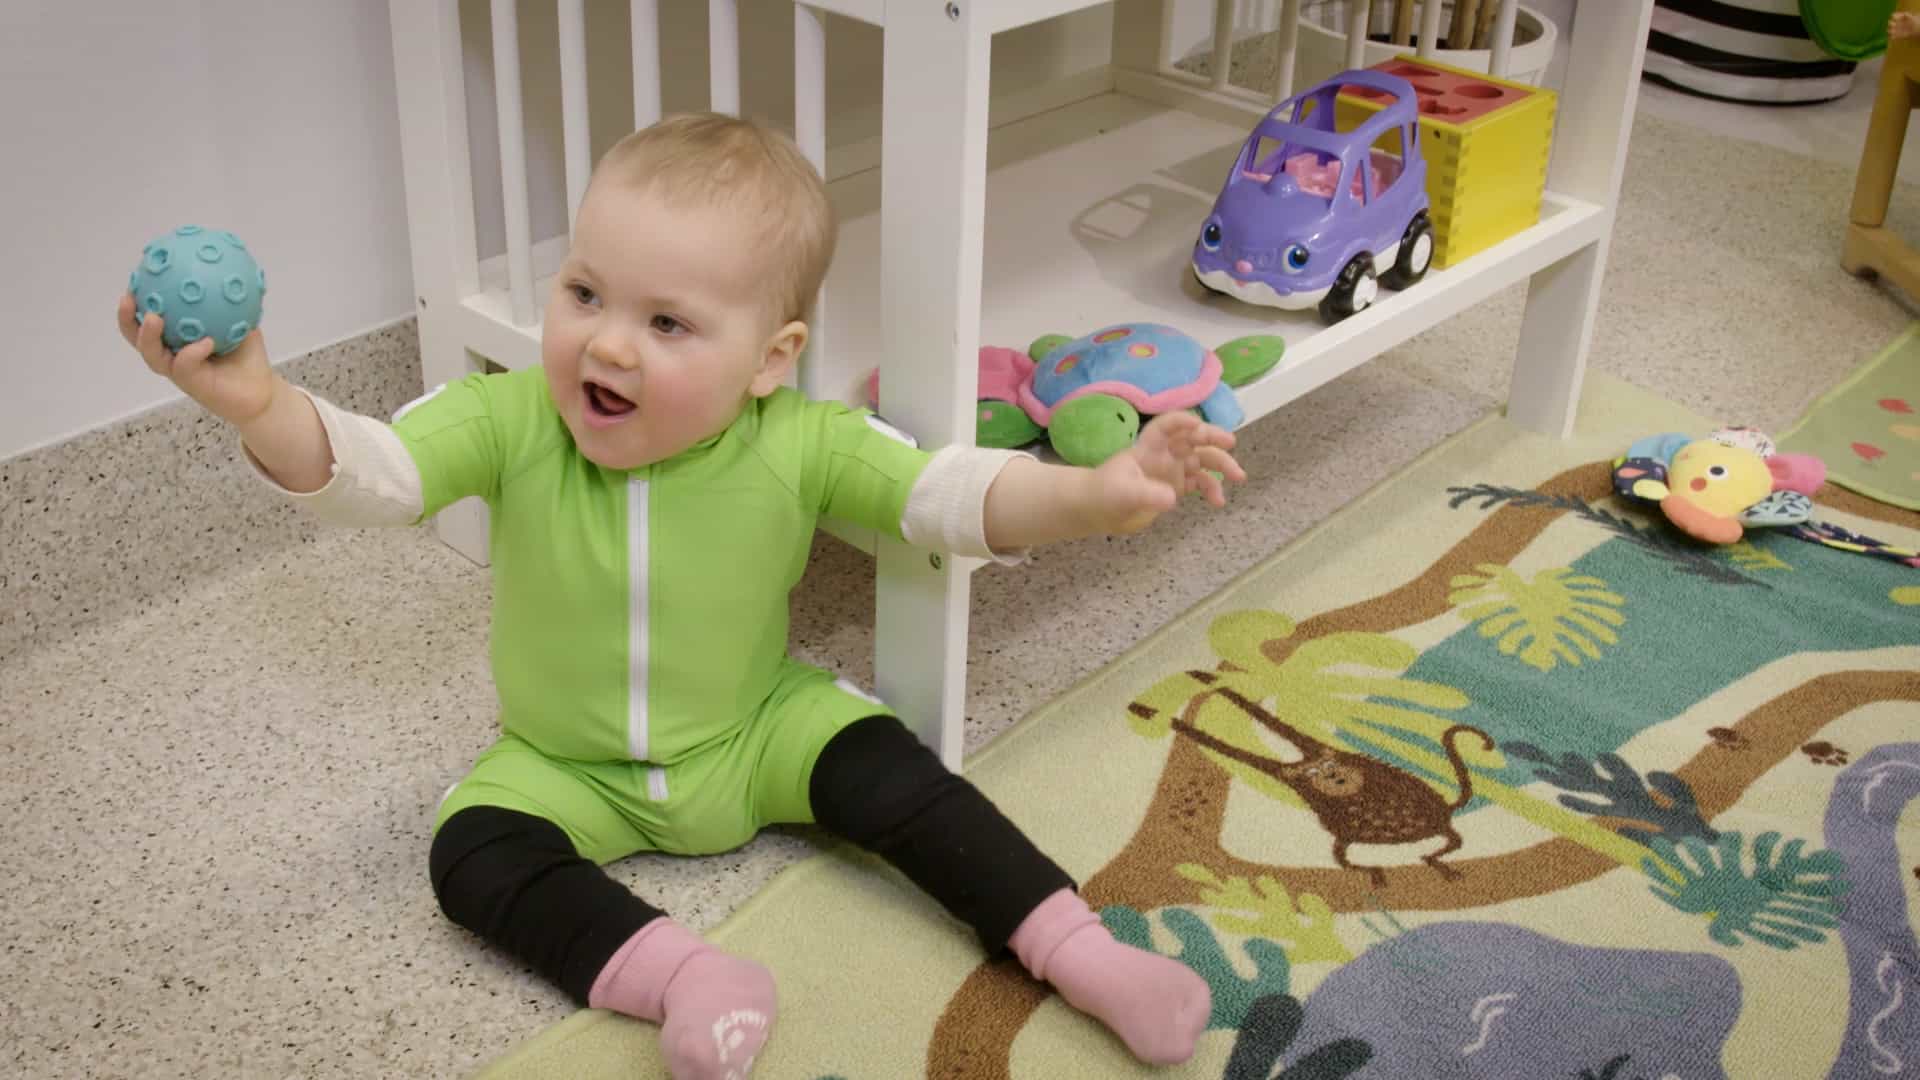

Quantified Assessment of Infant's Gross Motor Abilities Using a Multisensor Wearable
Published on: May 17, 2024
Design of pediatric robot to simulate infant biomechanics for neuro-developmental assessment in a sensorized gym
Jal Panchal1, O Francis Sowande2, Laura Prosser3
1Jal Panchal is with the School of Engineering and Applied Sciences, Department of General Robotics, Automation, Sensing, & Perception (GRASP), University of Pennsylvania, Philadelphia, PA, USA.

Insights
Researchers developed a robot simulator to study infant movement and center of pressure (COP). While limb movements alone didn't replicate infant COP, the simulator successfully predicted COP using kinematic data and a sensorized mat.
Area of Science:
- Robotics
- Pediatric Neuromotor Assessment
- Biomechanics
Background:
- Infants at risk for developmental delays may show early signs through their postures and movements.
- The center of pressure (COP) is a key metric for assessing neuromotor delay in infants.
- Understanding infant kinematics is crucial for early detection of conditions like cerebral palsy.
Purpose of the Study:
- To investigate how infant kinematic movements influence the center of pressure (COP).
- To develop and validate a robotic pediatric simulator for studying infant neuromotor development.
- To assess the feasibility of predicting infant COP using robotic simulation and motion capture.
Main Methods:
- Development of a 4 Degrees of Freedom (DOF) robot pediatric simulator.
- Experiment 1: Comparison of simulated limb movements' effect on COP with a human infant's COP.
- Experiment 2: Prediction of COP using simulator kinematic pose (from video) and a sensorized mat.
Main Results:
- Infant limb movements alone were insufficient to accurately mimic the COP patterns observed in a human infant.
- The robotic simulator, combined with video analysis and a sensorized mat, demonstrated the ability to predict COP position.
- The study highlights the potential of robotic simulators in neuromotor assessment.
Conclusions:
- Robotic simulation shows promise for understanding infant neuromotor function and predicting COP.
- Further development, potentially including trunk DOFs, is needed for more comprehensive infant simulation.
- This technology could aid in the early identification of developmental delays and neuromotor conditions.
Abstract:
Infants at risk for developmental delays often exhibit postures and movements that may provide a window into potential impairment for cerebral palsy and other neuromotor conditions. We developed a simple 4 DOF robot pediatric simulator to help provide insight into how infant kinematic movements may affect the center of pressure (COP), a common measure thought to be sensitive to neuromotor delay when assessed from supine infants at play. We conducted two experiments: 1) we compared changes in COP caused by limb movements to a human infant and 2) we determined if we could predict COP position due to limb movements using simulator kinematic pose retrieved from video and a sensorized mat. Our results indicate that the limb movements alone were not sufficient to mimic the COP in a human infant. In addition, we show that given a robot simulator and a simple camera, we can predict COP measured by a force sensing mat. Future directions suggest a more complex robot is needed such as one that may include trunk DOF.